19 Years · America's Largest Robotics Integrator
Home/ Store/ Humanoid/ Unitree G1 Humanoid Robot

Unitree G1 Humanoid Robot

The Unitree G1 is a compact bipedal humanoid built for research, education and content work. It stands about 1.27 m, weighs roughly 35 kg with its quick-release battery, and ships with 23 degrees of freedom — rising to 4

Configurations from
$17,990 – $83,900
23 configurations · compare them

Purchase · Lease

Unitree G1 Humanoid Robot — Unitree
Manufacturer
Unitree
Capability
Humanoid Robots
Support
US sales, setup & service
Overview

What is the Unitree G1 Humanoid Robot?

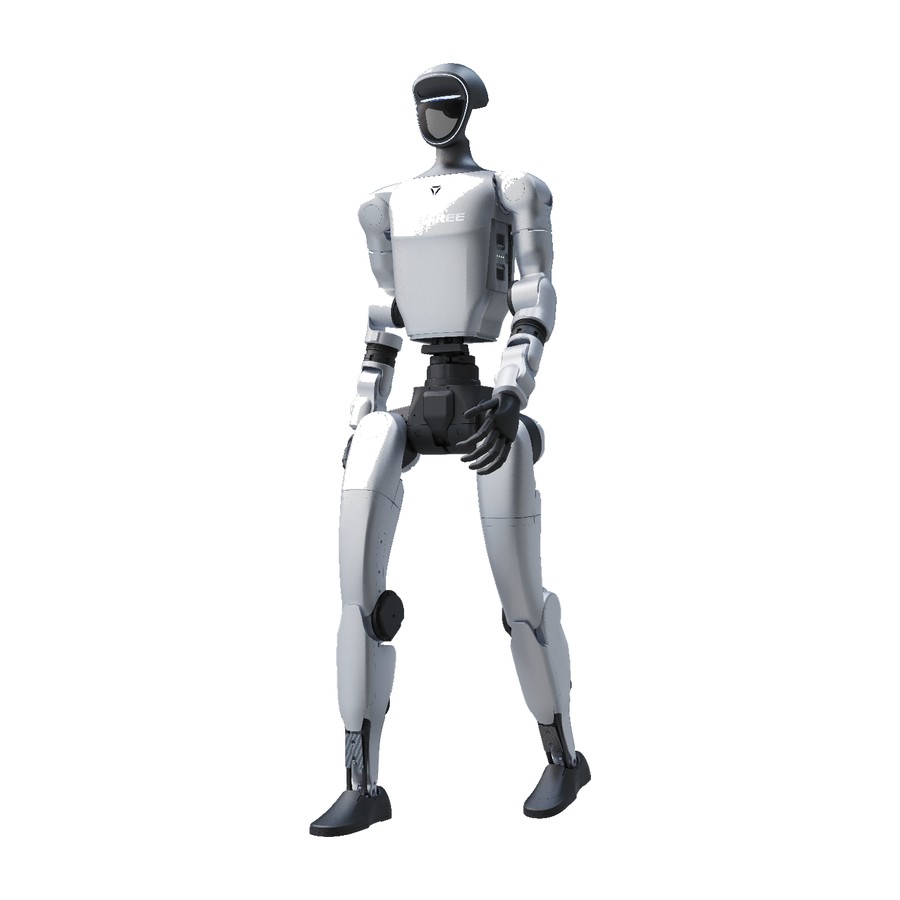
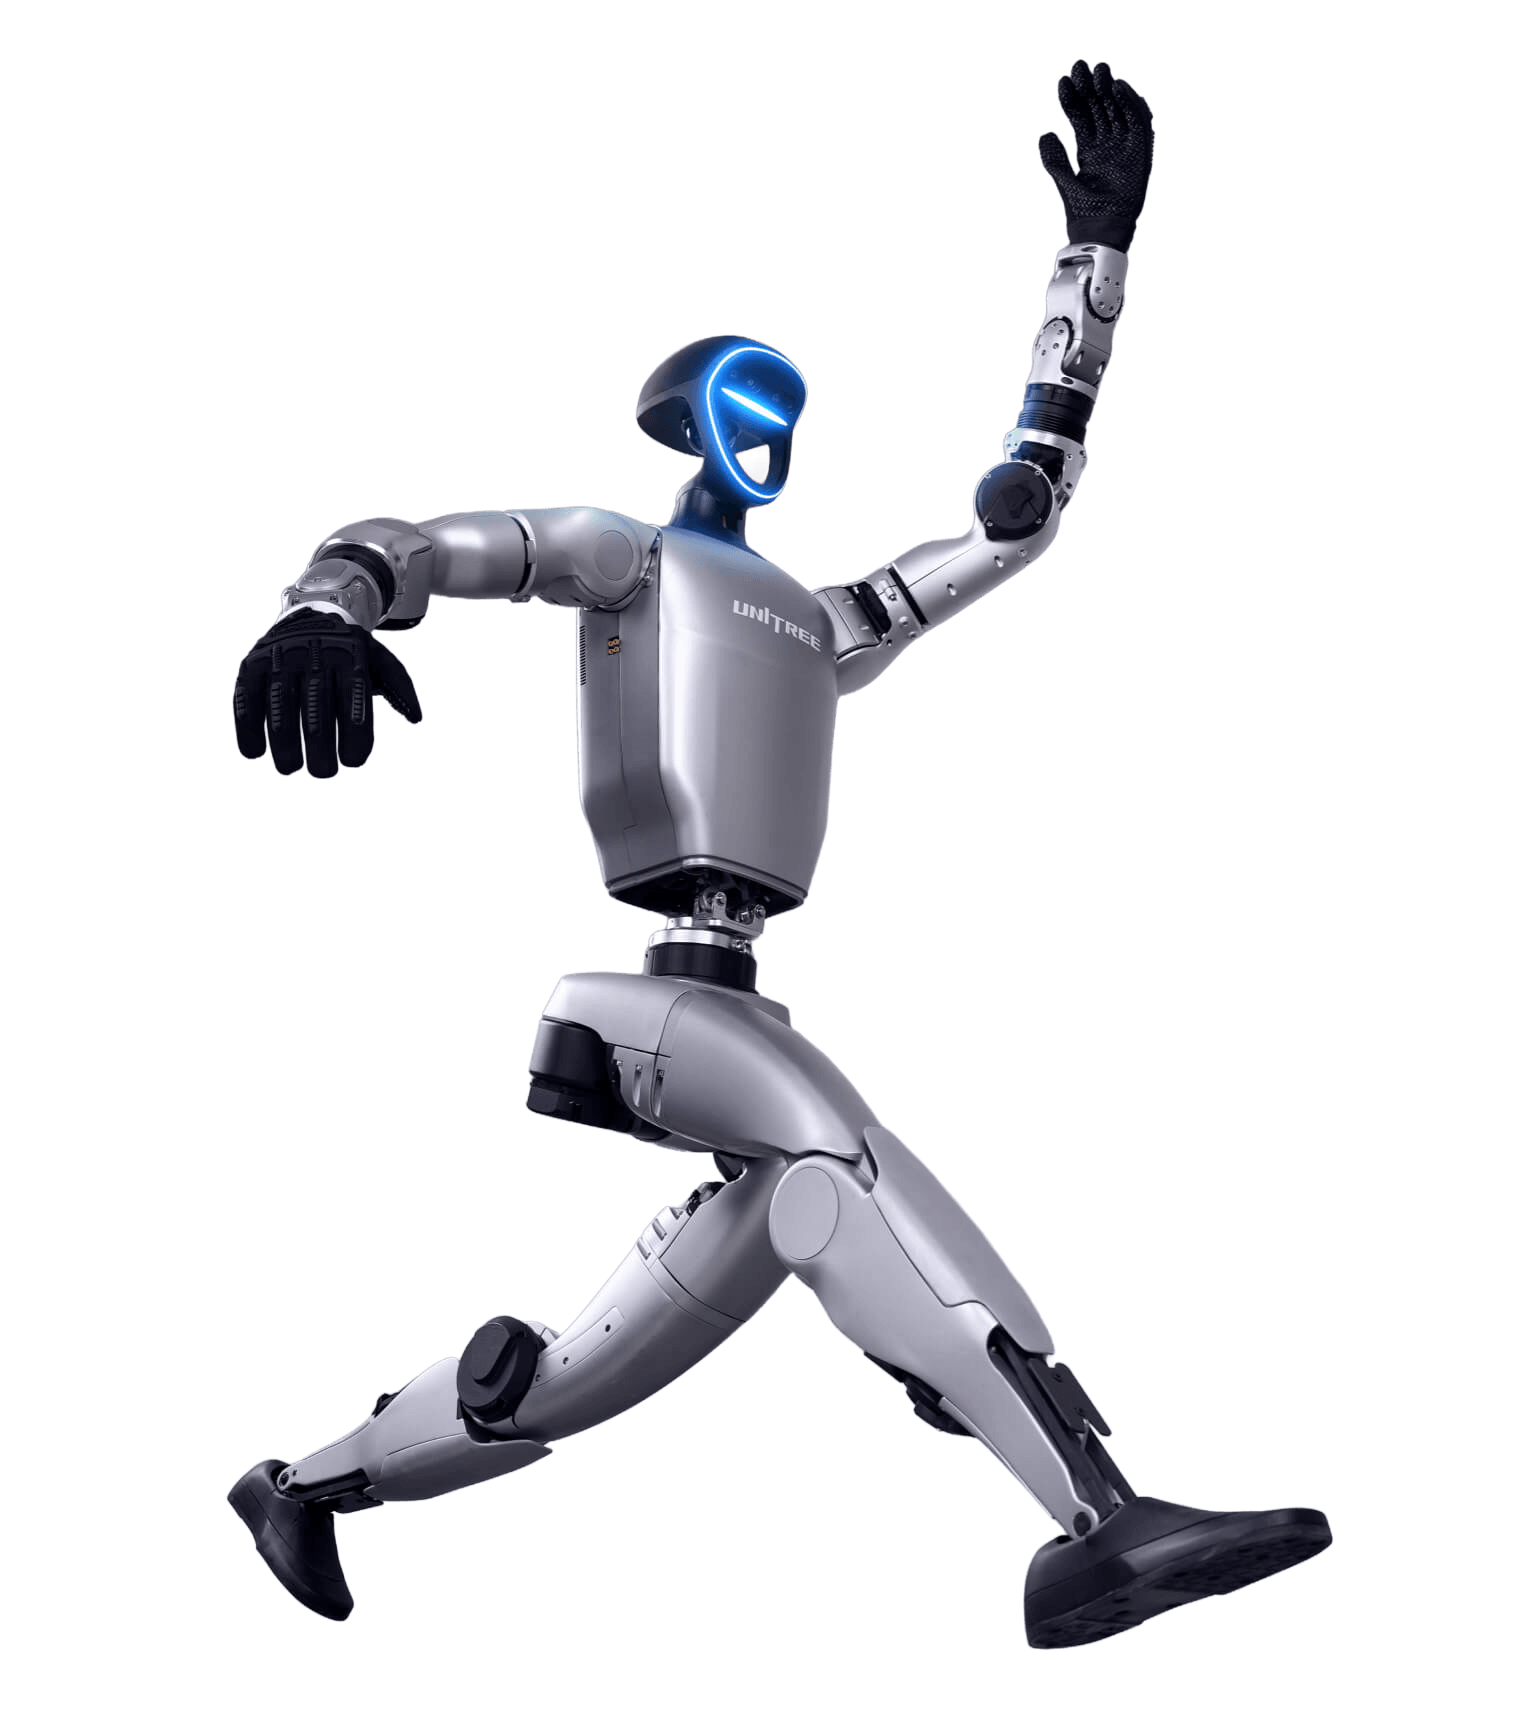
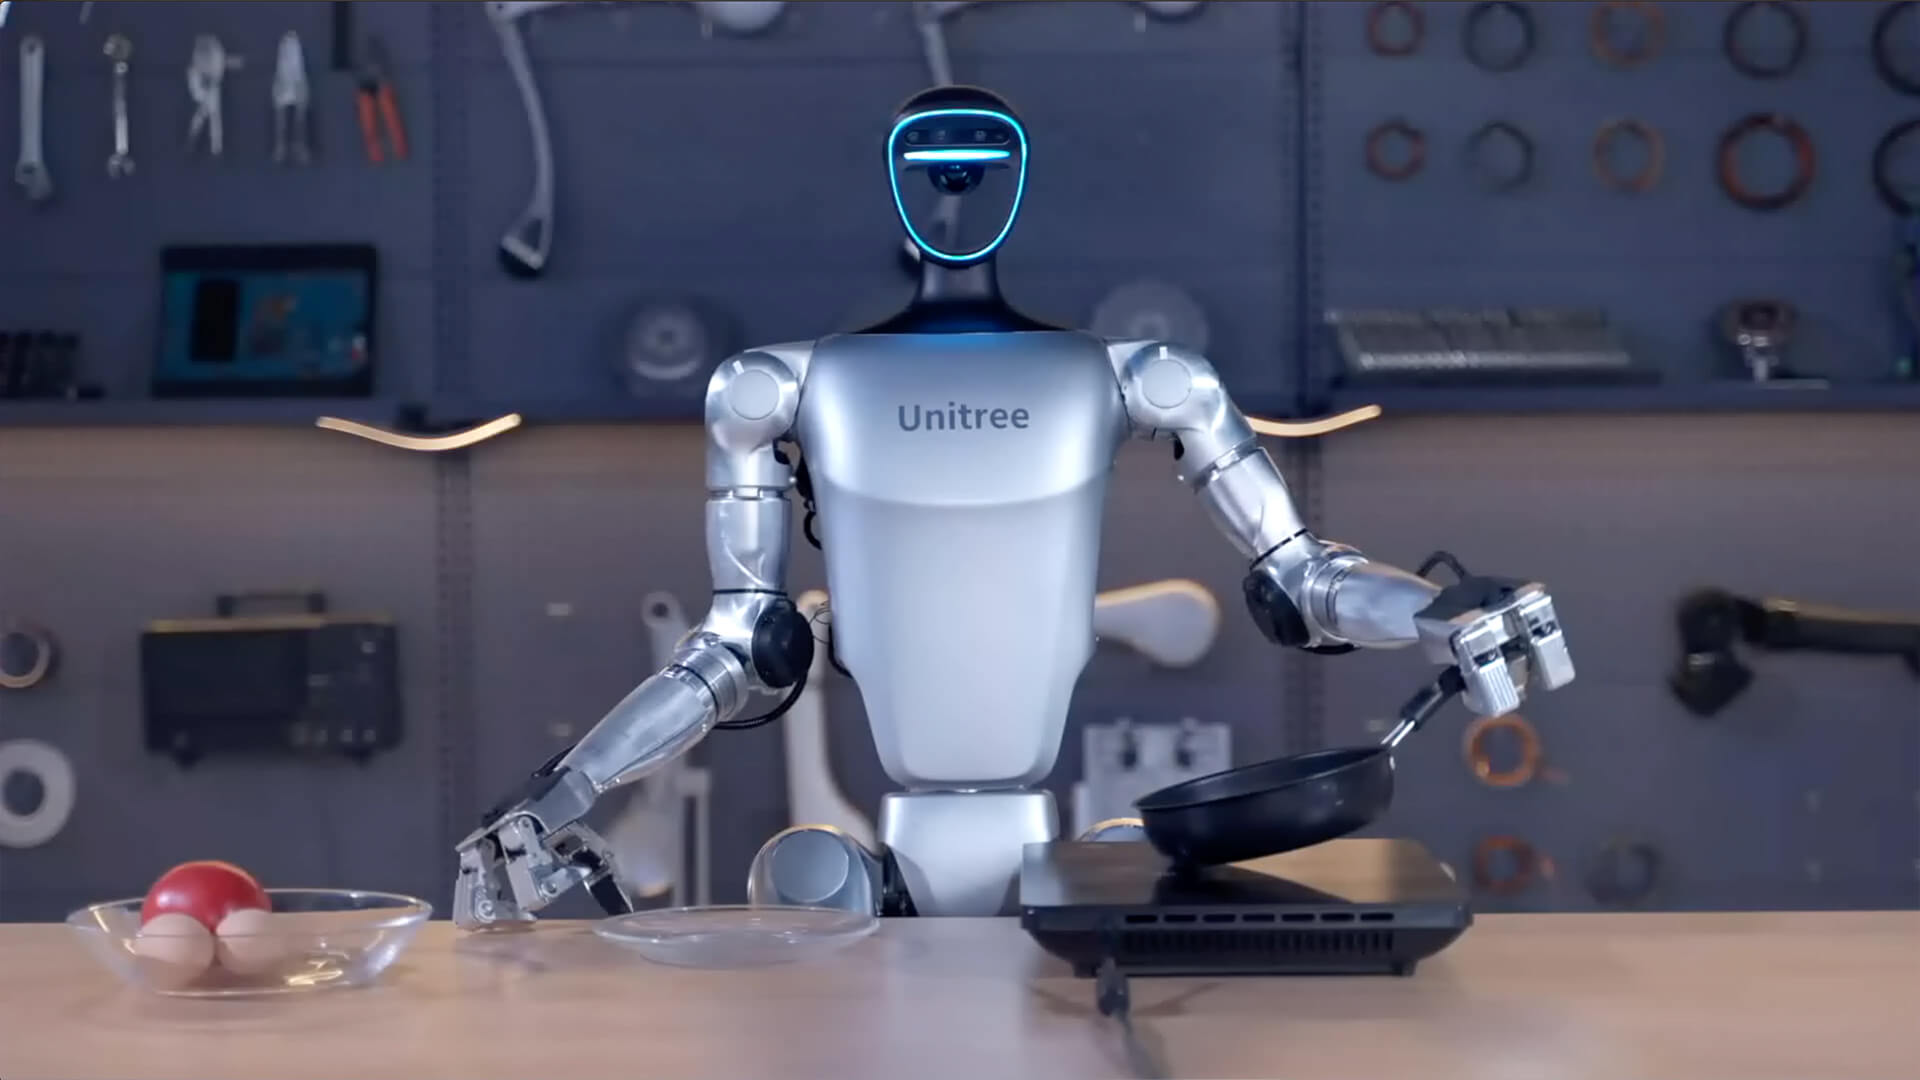
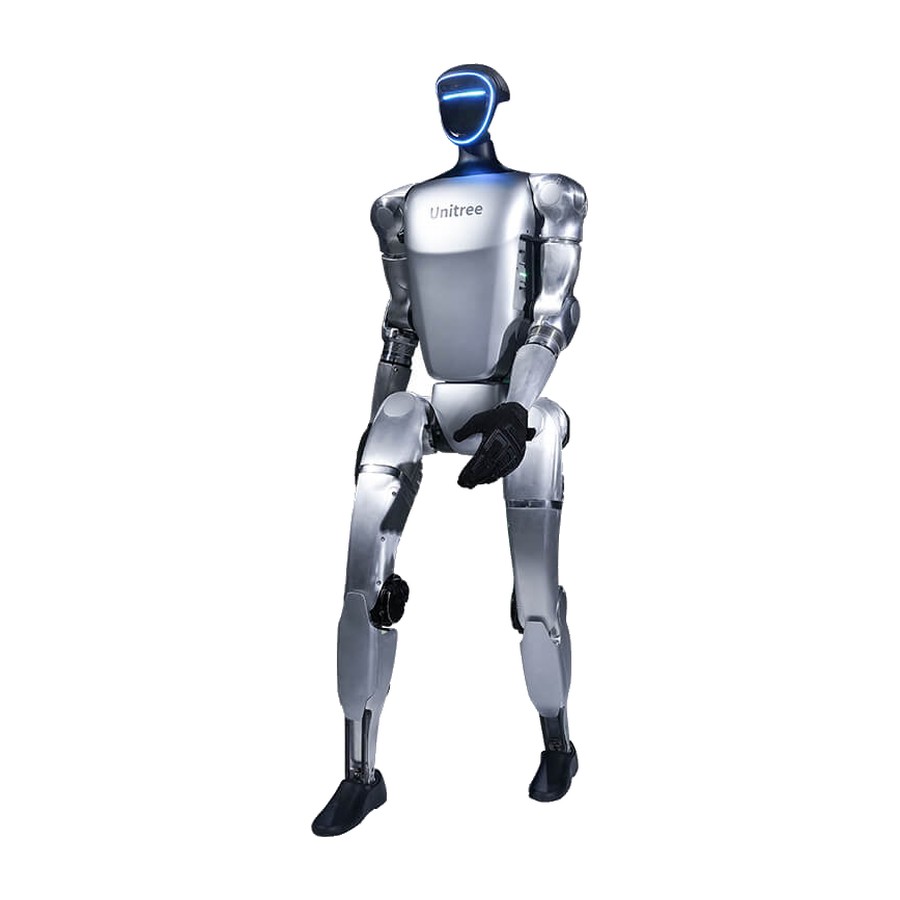
The Unitree G1 is a compact bipedal humanoid built for research, education and content work. It stands about 1.27 m, weighs roughly 35 kg with its quick-release battery, and ships with 23 degrees of freedom — rising to 43 once dexterous hands and the upgraded waist and arms are fitted.

Every G1 in the range is the same core platform. What changes across configurations is compute, degrees of freedom, and which hands are on the end of the arms — which is why the price spans a wide band.

RobotLAB supplies the full Unitree humanoid range in the United States, with 23 G1 configurations currently listed, from $17,990 to $83,900. Every configuration below is quoted, supported and serviced from the US.

Specifications

Key specs

Height, width and thickness (standing)1270x450x200mm
Height, width and thickness (folded)690x450x300mm
Weight with batteryapprox. 35kg
Total freedom (joint motor)23
Freedom of one leg6
Waist Freedom1
Freedom of one arm5
Single-handed freedomDexterous hand and double-freedom wrist optional
Maximum knee torque90N.m
Maximum arm load2kg
Calf + thigh length0.6m
Arm arm spanapprox. 0.45m
Knee joint0~165°
Hip jointP±154°, R-30~+170°, Y±158°”
Full joint hollow internal alignmentYes
Joint encoderdual encoder
Heat dissipation systemlocalized air-cooled heat dissipation
Power supply13 series battery
Base Computing Power8-core high performance CPU
SensorDepth camera + 3D LIDAR
WiFi 6, Bluetooth 5.2Yes
Enduranceabout 2h
See it move

The G1 outdoors, under its own control

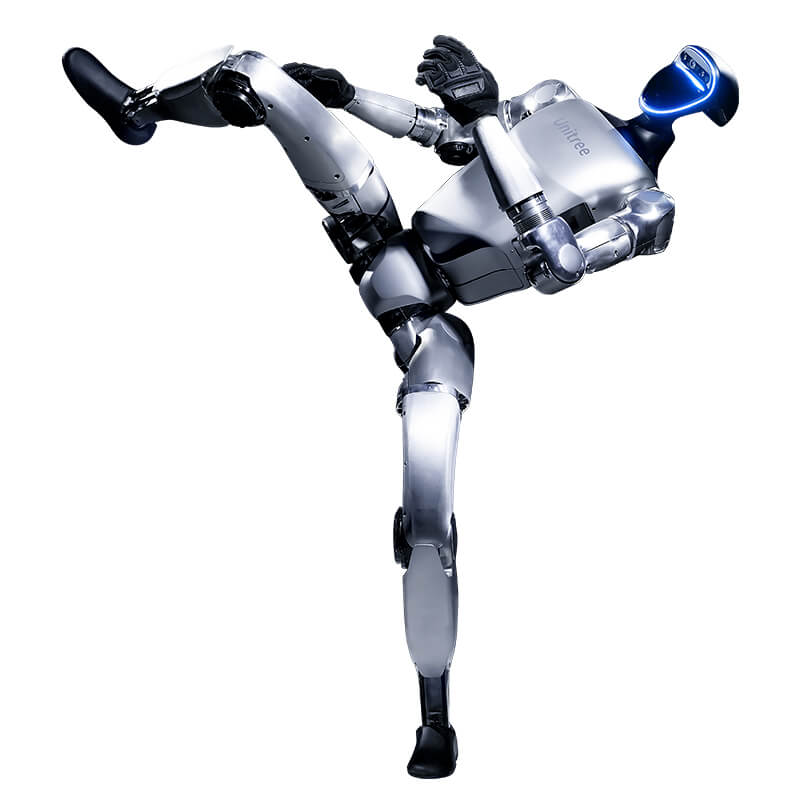
Walking, uneven ground and full-body dynamic movement — the baseline every G1 configuration shares.

Footage courtesy of Unitree Robotics.

How it works

Unitree G1 Humanoid Robot in detail

Choosing a configuration

The table below is the honest version of the spec sheet: it shows only what actually differs between configurations, so you can see what the extra money buys. Shared platform specifications are listed separately — they apply to every unit in the range.

Typical buyers are university robotics labs, AI research groups and media production teams. If you are not sure which build fits your work, ask us: we configure these for US customers every week and will tell you when a cheaper configuration does the job.

See the rest of the range on our humanoid robots page, or browse everything we carry from Unitree.

Most configurations differ only by the hand fitted. If you want to compare end effectors on their own, see Unitree humanoid hands and grippers.

Compare

How the Unitree G1 Humanoid Robot compares

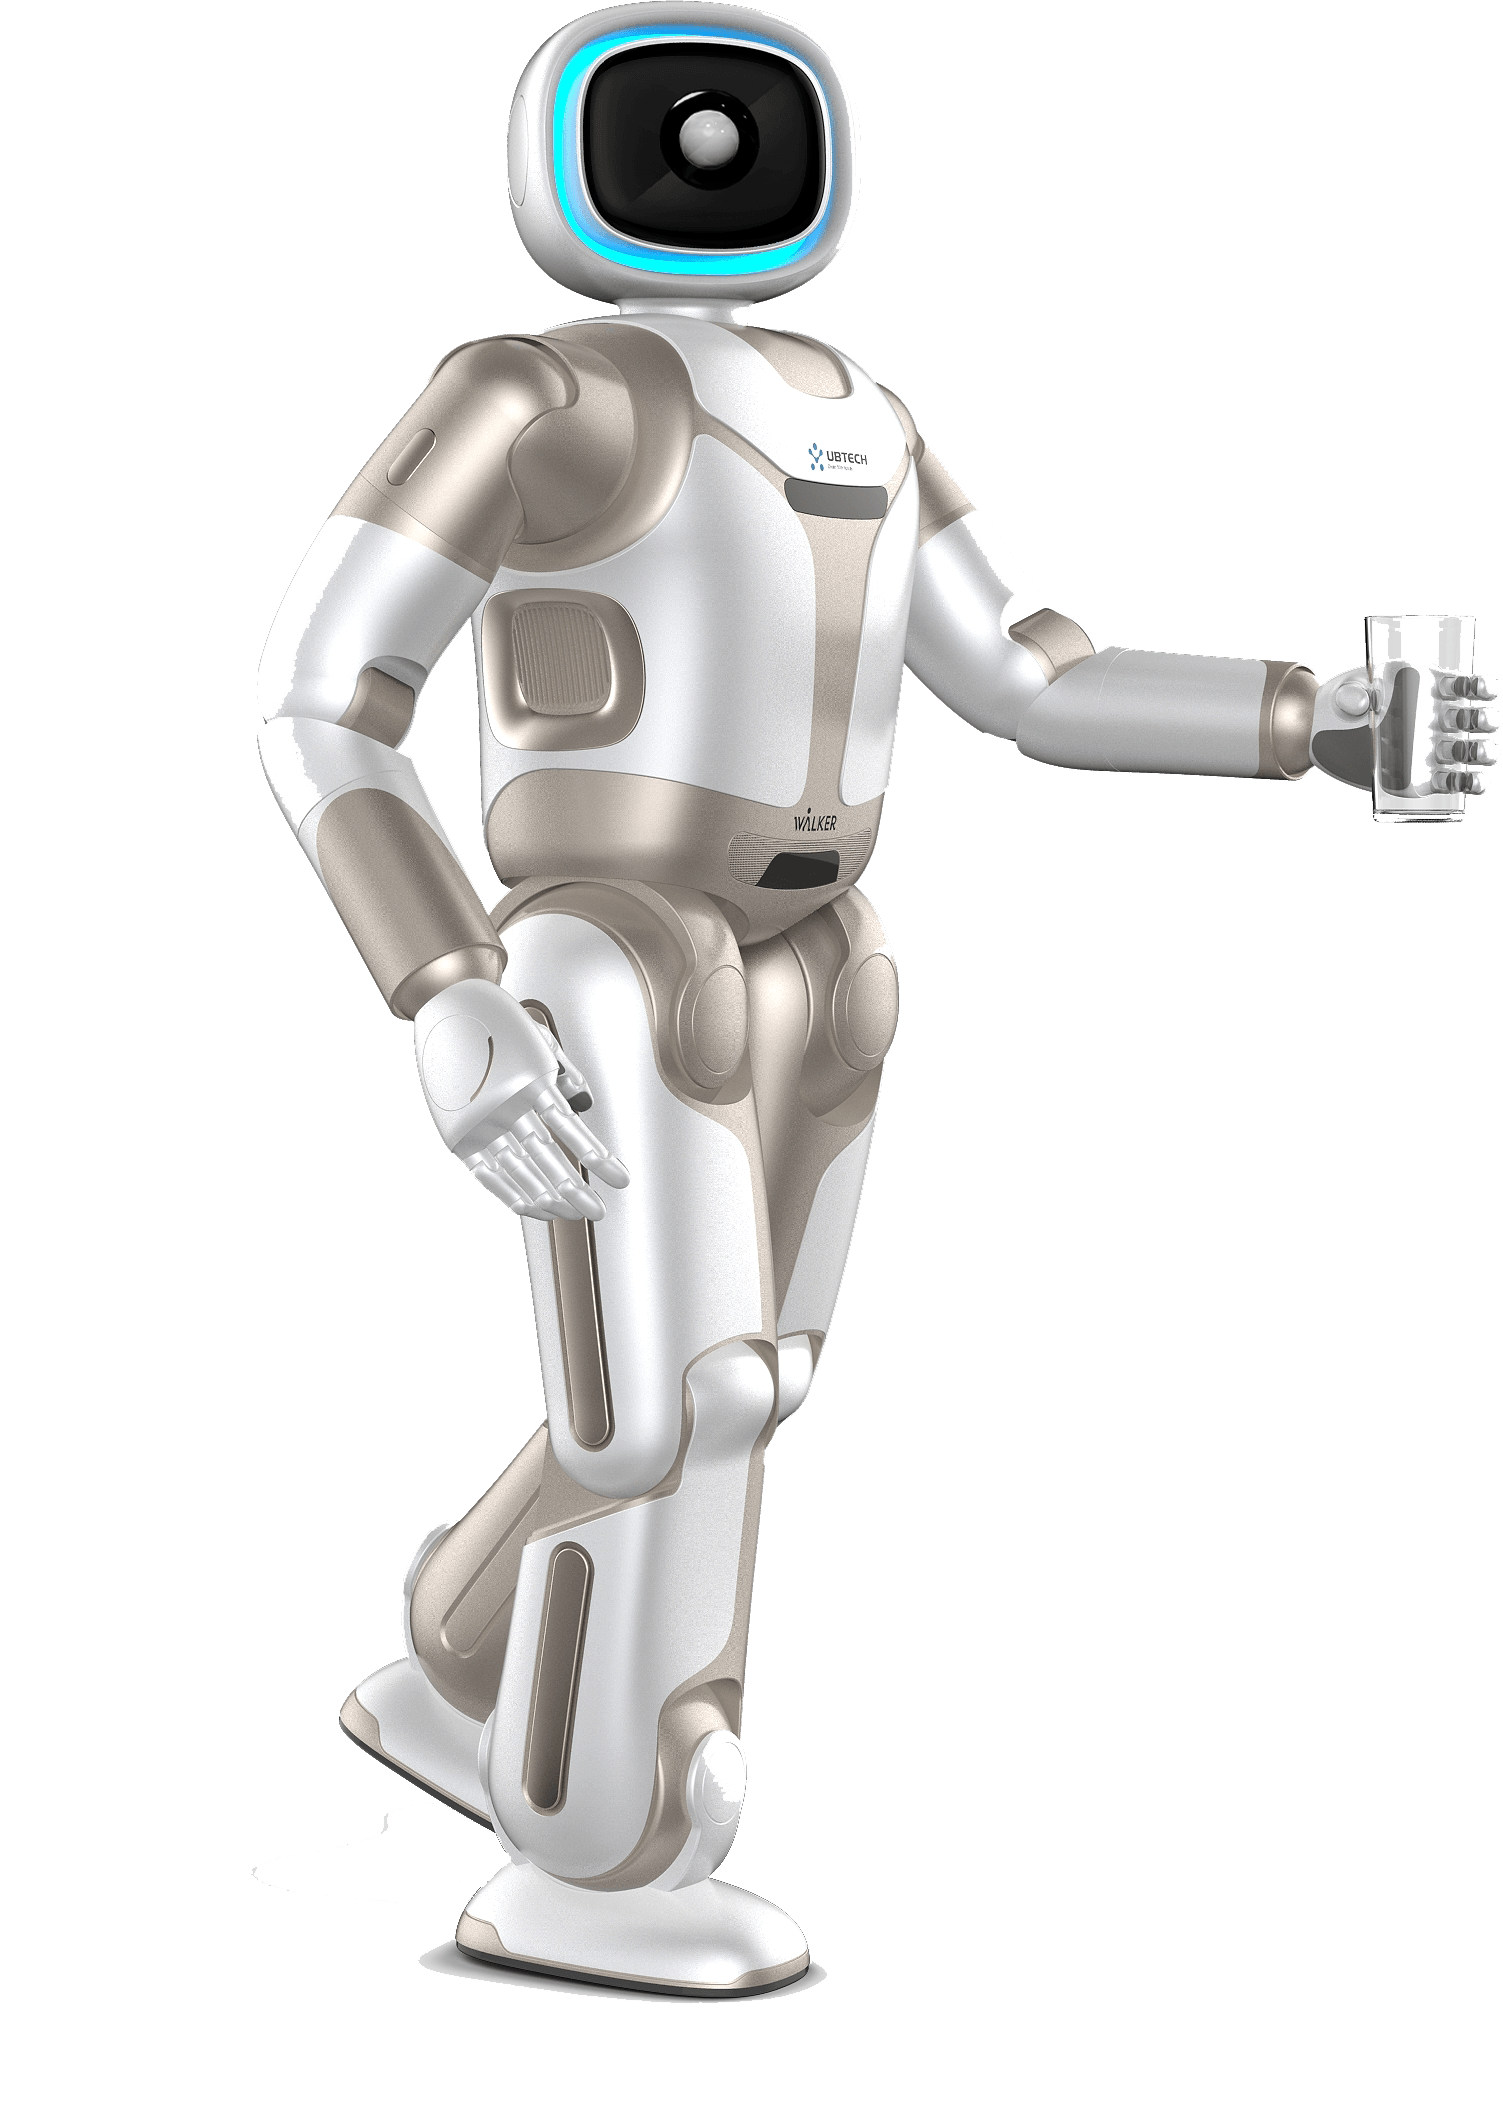
SpecificationUnitree G1Unitree G1Unitree H2UBTech WalkerUBTech Walker
Best forAffordable, portable humanoid R&DFull-size locomotion & manipulation researchTurnkey full-size service humanoid
Purchase price$23,700$68,900$960,000
Height1.32 m~1.80 m1.45 m
Weight~35 kg~70 kg77 kg
Degrees of freedom23 (up to 43 EDU)3136
Single-arm payload~2 kg (3 kg EDU)~8 kg~1.5 kg
Max walking speed2 m/s~1.4 m/sContact for details
Battery runtime~2 h (9 Ah, hot-swap)~2-3 h (972 Wh)~2 h (54.6V/10Ah)
Onboard compute8-core CPU (+opt. Orin)Intel i5+i7 (+opt. Jetson Thor 2070 TOPS)Intel i7/i5
Dexterous handsOptional 7-DoF hands10-finger hands4-DoF per hand
Sensing3D LiDAR + depth cam + mic arrayTorque-sensing joints + camerasDepth cameras + LiDAR
Primary use caseResearch & educationResearch, logistics, industryHome/office service
Humanoid configurator

Feeling overwhelmed by 64 humanoid configurations?

Let our AI recommend the right platform for you. Tell us what the robot is for — or the exact specs you need — and get a shortlist of three Unitree configurations, with every option explained in plain language. No commitment.

  • A guided path for business users, a technical path for engineers
  • Compute, hands, sensing and joints explained as you go
  • Live list prices and a one-click quote request
Open the humanoid configurator → About two minutes. No commitment.
Unitree G1 humanoid robot
Configurations

Which Unitree G1 Humanoid Robot is right for you?

Every configuration below is the same core platform. They differ in compute, degrees of freedom and end effectors — from $17,990 to $83,900.

G1 Basic Humanoid Robot

G1 Basic Humanoid Robot

G1 Basic

Remote-operated G1 with no hands fitted. Not programmable.

End effector
None fitted

Unitree lists hands as an option on its programmable editions, so ask us before planning to add them here.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Not offered. Unitree lists no secondary development on this edition, so it runs built-in behaviors.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
8 months
More on control
Your code runs on
No user computer
Teleoperation
Not available: Unitree's teleoperation software runs on a development computer this edition does not have.
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 8-core CPU. No user computer on this edition.
  • 1.27 m, about 35 kg, about 2 hours of runtime.
  • 5-DoF arms carrying up to 2 kg, 1-DoF waist.
  • Depth camera and 3D LiDAR.
$17,990 Get a quote
G1 PRO Humanoid Robot

G1 PRO Humanoid Robot

G1 PRO

Remote-operated G1 with no hands fitted. Not programmable.

End effector
None fitted

Unitree lists hands as an option on its programmable editions, so ask us before planning to add them here.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Not offered. Unitree lists no secondary development on this edition, so it runs built-in behaviors.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
No user computer
Teleoperation
Not available: Unitree's teleoperation software runs on a development computer this edition does not have.
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 8-core CPU. No user computer on this edition.
  • Upgraded from Basic: 7-DoF arms carrying up to 3 kg, 3-DoF waist, 120 N·m knees.
  • Over 10 built-in motions unlocked, including dance, flips and kung fu.
  • D435i depth camera and 3D LiDAR.
$28,950 Get a quote
G1 E Humanoid Robot

G1 E Humanoid Robot

G1 E

Programmable G1 with no hands fitted.

End effector
None fitted

Ask us before planning to add hands to this edition.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes. Unitree lists secondary development on this edition.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
Your code runs on
100 TOPS docking station with navigation and positioning software
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station with navigation and positioning software.
  • 7-DoF arms carrying up to 3 kg, 3-DoF waist, 120 N·m knees.
  • Aimed at events and content: over 10 motions unlocked, plus UniStore support.
  • D435i depth camera and ultra-wide LiDAR. Protective stand included.
$43,900 Get a quote
G1 Edu Standard Humanoid Robot

G1 Edu Standard Humanoid Robot

G1 Edu Standard

Programmable G1 with no hands fitted.

End effector
None fitted

Choose any compatible hand as an option, or pick an edition that has them fitted.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • 5-DoF arms carrying up to 3 kg, 1-DoF waist, 120 N·m knees.
  • Includes development manuals and technical support.
$43,900 Get a quote
G1 Edu Professional H Humanoid Robot

G1 Edu Professional H Humanoid Robot

G1 Edu Professional H

Programmable G1 with a pair of Dex1-1 Advanced grippers, with wrist cameras.

End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full hand specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Standard: 5-DoF arms carrying up to 3 kg, 1-DoF waist.
$44,800 Get a quote
G1 Edu Professional G Humanoid Robot

G1 Edu Professional G Humanoid Robot

G1 Edu Professional G

Programmable G1 with a pair of five-finger tendon-driven hands.

End effector
Pair of five-finger tendon-driven hands

Looks like a human hand and closes around objects, but moves as a unit. It cannot move each finger on its own.

Full hand specs and what they mean
Type
Five-finger tendon-driven hand
Motion
2 DoF per hand. 2 motors drive 10 joints: the four fingers share one motor, the thumb has the other.
Force
10 to 15 N at the fingertip
Load
1.5 kg
Smallest grip
8 mm
Touch
None
Wrist camera
Not included
Weight
365 g
Size
151 × 70 × 63 mm
Drive
Gear and tendon
Control
Joint position, velocity, torque, stiffness and damping
Interface
RS-485, 1000 Hz, no external wiring between hand and robot
Software
URDF model available
Best for
A human look for shows and presence, and simple light grasps, at low cost.
Keep in mind
No finger-by-finger control, no touch sensing, no camera. Not for manipulation research.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Standard: 5-DoF arms carrying up to 3 kg, 1-DoF waist.
$45,900 Get a quote
G1-Comp Humanoid Robot

G1-Comp Humanoid Robot

Comp

Programmable G1 with no hands fitted.

End effector
None fitted

Ask us before planning to add hands to this edition.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months; extensions case by case for competitions
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin, 100 TOPS
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Competition edition with 25 DoF.
  • Includes development support.
$46,900 Get a quote
G1 Edu Professional E Humanoid Robot

G1 Edu Professional E Humanoid Robot

G1 Edu Professional E

Programmable G1 with a pair of BrainCo Revo 2 five-finger hands.

End effector
Pair of BrainCo Revo 2 five-finger hands

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Standard: 5-DoF arms carrying up to 3 kg, 1-DoF waist.
$51,900 Get a quote
G1 Edu Advanced Humanoid Robot

G1 Edu Advanced Humanoid Robot

G1 Edu Advanced

Programmable G1 with no hands fitted.

End effector
None fitted

Choose any compatible hand as an option, or pick an edition that has them fitted.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • 7-DoF arms carrying up to 3 kg, 3-DoF waist, 120 N·m knees.
  • Includes development manuals and technical support.
$53,900 Get a quote
G1 Edu Ultimate H Humanoid Robot

G1 Edu Ultimate H Humanoid Robot

G1 Edu Ultimate H

Programmable G1 with a pair of Dex1-1 Advanced grippers, with wrist cameras.

End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full hand specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$54,800 Get a quote
G1 Edu Professional A Humanoid Robot

G1 Edu Professional A Humanoid Robot

G1 Edu Professional A

Programmable G1 with a pair of Dex3-1 three-finger hands.

End effector
Pair of Dex3-1 three-finger hands

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full hand specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Standard: 5-DoF arms carrying up to 3 kg, 1-DoF waist.
$54,900 Get a quote
G1 Edu Ultimate G Humanoid Robot

G1 Edu Ultimate G Humanoid Robot

G1 Edu Ultimate G

Programmable G1 with a pair of five-finger tendon-driven hands.

End effector
Pair of five-finger tendon-driven hands

Looks like a human hand and closes around objects, but moves as a unit. It cannot move each finger on its own.

Full hand specs and what they mean
Type
Five-finger tendon-driven hand
Motion
2 DoF per hand. 2 motors drive 10 joints: the four fingers share one motor, the thumb has the other.
Force
10 to 15 N at the fingertip
Load
1.5 kg
Smallest grip
8 mm
Touch
None
Wrist camera
Not included
Weight
365 g
Size
151 × 70 × 63 mm
Drive
Gear and tendon
Control
Joint position, velocity, torque, stiffness and damping
Interface
RS-485, 1000 Hz, no external wiring between hand and robot
Software
URDF model available
Best for
A human look for shows and presence, and simple light grasps, at low cost.
Keep in mind
No finger-by-finger control, no touch sensing, no camera. Not for manipulation research.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$55,900 Get a quote
G1 Edu Professional B Humanoid Robot

G1 Edu Professional B Humanoid Robot

G1 Edu Professional B

Programmable G1 with a pair of Dex3-1 three-finger hands with touch sensing.

End effector
Pair of Dex3-1 three-finger hands with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full hand specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Standard: 5-DoF arms carrying up to 3 kg, 1-DoF waist.
$56,900 Get a quote
G1 Edu Professional F Humanoid Robot

G1 Edu Professional F Humanoid Robot

G1 Edu Professional F

Programmable G1 with a pair of BrainCo Revo 2 hands with touch sensing.

End effector
Pair of BrainCo Revo 2 hands with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Standard: 5-DoF arms carrying up to 3 kg, 1-DoF waist.
$56,900 Get a quote
G1 Edu Ultimate E Humanoid Robot

G1 Edu Ultimate E Humanoid Robot

G1 Edu Ultimate E

Programmable G1 with a pair of BrainCo Revo 2 five-finger hands.

End effector
Pair of BrainCo Revo 2 five-finger hands

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$63,900 Get a quote
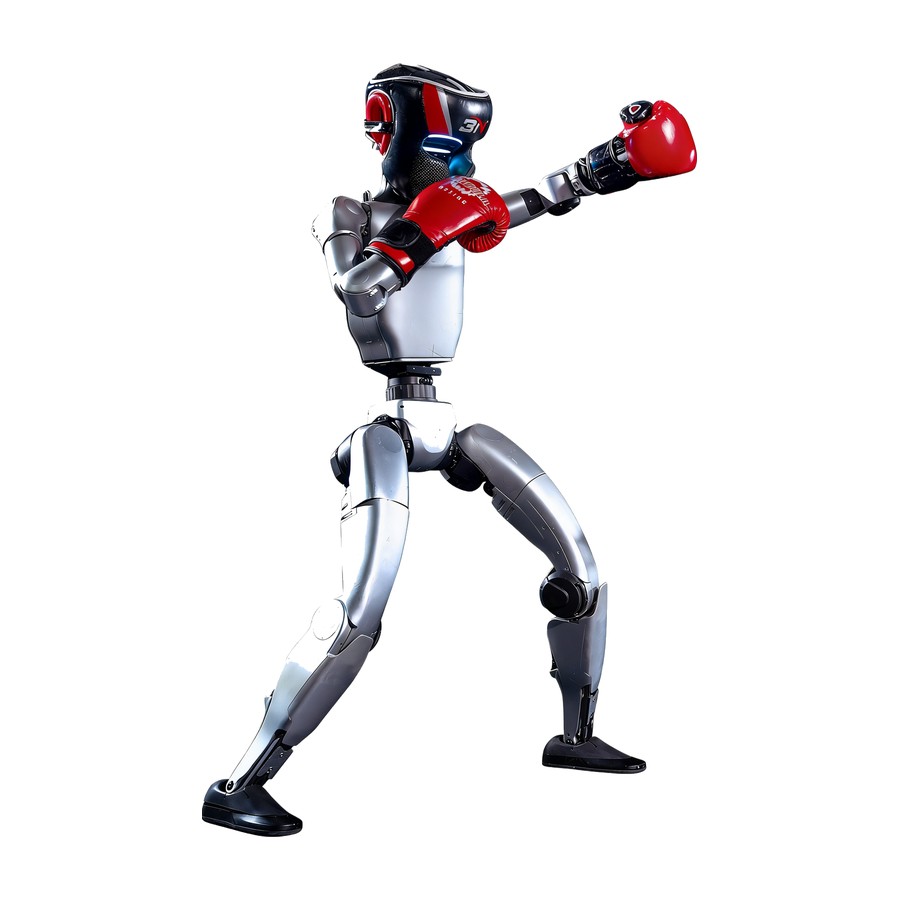
G1 Edu Boxing Humanoid Robot

G1 Edu Boxing Humanoid Robot

G1 Edu Boxing

Programmable G1 with no hands fitted.

End effector
None fitted

Ask us before planning to add hands to this edition.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
No free warranty: repairs are charged on this edition
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced, with combat motion control.
  • Reinforced waist motor, armor and hardware. Boxing gloves included.
$63,900 Get a quote
G1 Edu Ultimate A Humanoid Robot

G1 Edu Ultimate A Humanoid Robot

G1 Edu Ultimate A

Programmable G1 with a pair of Dex3-1 three-finger hands.

End effector
Pair of Dex3-1 three-finger hands

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full hand specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$65,900 Get a quote
G1 Edu Ultimate B Humanoid Robot

G1 Edu Ultimate B Humanoid Robot

G1 Edu Ultimate B

Programmable G1 with a pair of Dex3-1 three-finger hands with touch sensing.

End effector
Pair of Dex3-1 three-finger hands with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full hand specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$67,900 Get a quote
G1 Edu Ultimate C Humanoid Robot

G1 Edu Ultimate C Humanoid Robot

G1 Edu Ultimate C

Programmable G1 with a pair of Inspire DFQ five-finger hands.

End effector
Pair of Inspire DFQ five-finger hands

A fast, light-duty five-finger hand. Quick fingers, but low fingertip force compared with the others here.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
6 N thumb, 4 N fingers
Speed
Fingers flex at 570°/s, thumb at 150°/s
Touch
None
Repeatability
±0.20 mm
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Best for
Fast, human-like motion for demonstrations and light objects.
Keep in mind
Low fingertip force, so not for heavy objects. No touch sensing. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$67,900 Get a quote
G1 Edu Ultimate F Humanoid Robot

G1 Edu Ultimate F Humanoid Robot

G1 Edu Ultimate F

Programmable G1 with a pair of BrainCo Revo 2 hands with touch sensing.

End effector
Pair of BrainCo Revo 2 hands with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$67,900 Get a quote
G1 Edu Ultimate D Humanoid Robot

G1 Edu Ultimate D Humanoid Robot

G1 Edu Ultimate D

Programmable G1 with a pair of Inspire E2 five-finger hands with touch sensing.

End effector
Pair of Inspire E2 five-finger hands with touch sensing

A sturdier five-finger hand with strong fingertips and 17 touch sensors.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
30 N whole hand; 30 N thumb, 28 N fingers at the fingertip
Load
15 kg
Speed
Closes the palm in 0.8 s
Touch
17 tactile sensors, 0 to 30 N
Repeatability
±0.20 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 790 g
Drive
Linear servos
Control
Force-threshold control
Interface
RS-485 or CAN, plus Modbus TCP
Software
Supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Five-finger work that needs both real fingertip force and touch.
Keep in mind
Heavier than the Revo 2 and Linker O6, which uses up more arm payload. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$73,900 Get a quote
G1 Edu Professional I Humanoid Robot

G1 Edu Professional I Humanoid Robot

G1 Edu Professional I

Programmable G1 with a pair of Wuji Hand 2 five-finger hands.

End effector
Pair of Wuji Hand 2 five-finger hands

Twenty motors with no gearbox slowing them down, so fingers are quick and can be pushed back by hand, close to how a person moves.

Full hand specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
20 DoF per hand. 20 active motors, one for each joint it can move.
Force
12 N or more at the fingertip
Smallest grip
0 mm
Speed
4 or more open and close cycles per second
Touch
None on this version
Precision
Joint backlash under 1°
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 800 g
Size
About 180 × 80 × 40 mm
Drive
Direct-drive rotary joints
Control
MIT hybrid force and position
Interface
Ethernet, 1000 Hz on all 20 axes
Software
Python and C SDK, ROS 2, MuJoCo and Isaac
Best for
Dexterous research and learning skilled finger motion on a G1 or H2.
Keep in mind
Overkill for simple grasping. Wuji labels its published figures as Beta, so confirm any figure you depend on with us.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Standard: 5-DoF arms carrying up to 3 kg, 1-DoF waist.
$73,900 Get a quote
G1 Edu Ultimate I Humanoid Robot

G1 Edu Ultimate I Humanoid Robot

G1 Edu Ultimate I

Programmable G1 with a pair of Wuji Hand 2 five-finger hands.

End effector
Pair of Wuji Hand 2 five-finger hands

Twenty motors with no gearbox slowing them down, so fingers are quick and can be pushed back by hand, close to how a person moves.

Full hand specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
20 DoF per hand. 20 active motors, one for each joint it can move.
Force
12 N or more at the fingertip
Smallest grip
0 mm
Speed
4 or more open and close cycles per second
Touch
None on this version
Precision
Joint backlash under 1°
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 800 g
Size
About 180 × 80 × 40 mm
Drive
Direct-drive rotary joints
Control
MIT hybrid force and position
Interface
Ethernet, 1000 Hz on all 20 axes
Software
Python and C SDK, ROS 2, MuJoCo and Isaac
Best for
Dexterous research and learning skilled finger motion on a G1 or H2.
Keep in mind
Overkill for simple grasping. Wuji labels its published figures as Beta, so confirm any figure you depend on with us.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, stand, sit, squat, wave, handshake. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
18 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Jetson Orin NX, 100 TOPS (PC2). PC1 stays reserved for Unitree. Jetson AGX Orin or Thor rear docks are optional.
Simulation
MuJoCo; Isaac Lab for 29-DoF versions
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3
Voice
Built-in microphones and speakers, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin, 100 TOPS, for your code.
  • Built on Edu Advanced: 7-DoF arms carrying up to 3 kg, 3-DoF waist.
$83,900 Get a quote
Humanoid hands configurator

Not sure which hand your robot needs?

Answer a few questions and we narrow 19 hands and grippers down to the three that fit your job, and show which Unitree robots each one works with. Every term, from degrees of freedom to repeatability, is explained in plain language as you go. No commitment.

  • A plain-language path for first-time buyers, a specs path for engineers
  • Tap any term like DoF or 0.1° repeatability for a simple explanation
  • Live list prices, what fits which robot, and a one-click quote request
Open the hands configurator → About two minutes. No commitment.
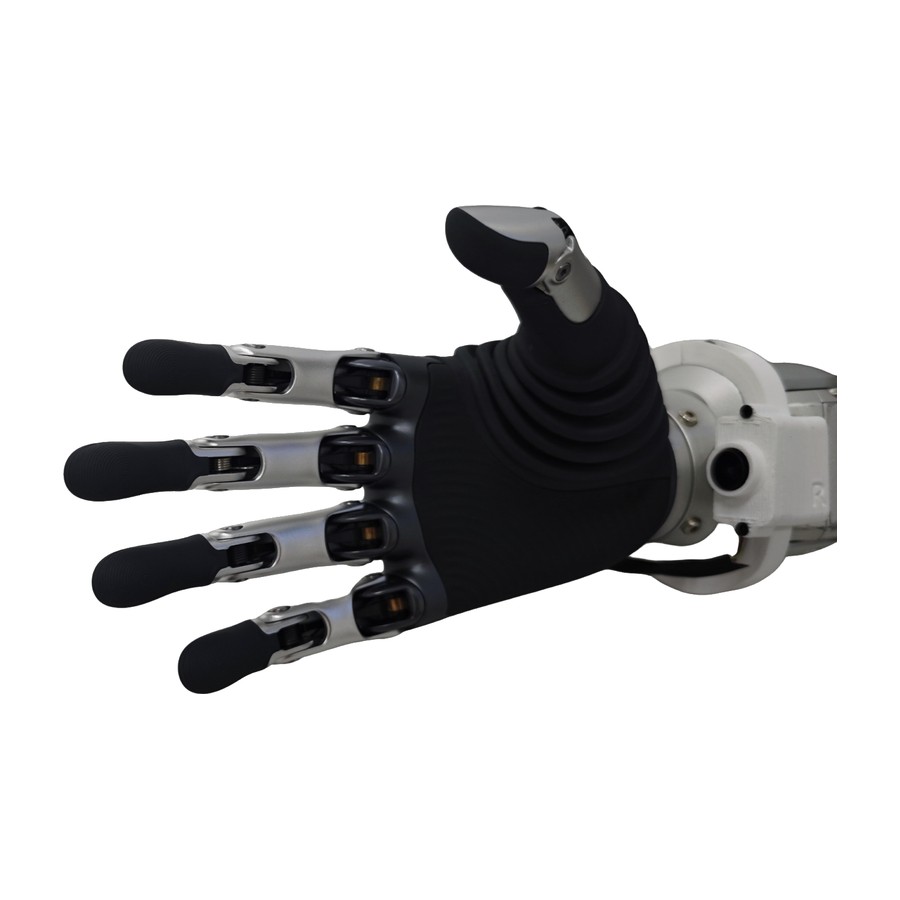
BrainCo Revo 2 dexterous hand, available for the Unitree G1
ConfigurationEnd effectorDoFComputeProgrammingWarrantyPrice
G1 Basic Humanoid Robot None 23 8-core CPU Not offered 8 months $17,990
G1 PRO Humanoid Robot None 29 8-core CPU Not offered 12 months $28,950
G1 E Humanoid Robot None 29 100 TOPS Yes 18 months $43,900
G1 Edu Standard Humanoid Robot None 23 Jetson Orin, 100 TOPS Yes, high and low level 18 months $43,900
G1 Edu Professional H Humanoid Robot Dex1-1 Advanced gripper 25 Jetson Orin, 100 TOPS Yes, high and low level 18 months $44,800
G1 Edu Professional G Humanoid Robot Tendon-driven hand 27 Jetson Orin, 100 TOPS Yes, high and low level 18 months $45,900
G1-Comp Humanoid Robot None 25 Jetson Orin, 100 TOPS Yes, high and low level 18 months $46,900
G1 Edu Professional E Humanoid Robot BrainCo Revo 2 35 Jetson Orin, 100 TOPS Yes, high and low level 18 months $51,900
G1 Edu Advanced Humanoid Robot None 29 Jetson Orin, 100 TOPS Yes, high and low level 18 months $53,900
G1 Edu Ultimate H Humanoid Robot Dex1-1 Advanced gripper 31 Jetson Orin, 100 TOPS Yes, high and low level 18 months $54,800
G1 Edu Professional A Humanoid Robot Dex3-1 3-finger 37 Jetson Orin, 100 TOPS Yes, high and low level 18 months $54,900
G1 Edu Ultimate G Humanoid Robot Tendon-driven hand 33 Jetson Orin, 100 TOPS Yes, high and low level 18 months $55,900
G1 Edu Professional B Humanoid Robot Dex3-1 3-finger, tactile 37 Jetson Orin, 100 TOPS Yes, high and low level 18 months $56,900
G1 Edu Professional F Humanoid Robot BrainCo Revo 2, tactile 35 Jetson Orin, 100 TOPS Yes, high and low level 18 months $56,900
G1 Edu Ultimate E Humanoid Robot BrainCo Revo 2 41 Jetson Orin, 100 TOPS Yes, high and low level 18 months $63,900
G1 Edu Boxing Humanoid Robot None 29 Jetson Orin, 100 TOPS Yes, high and low level None free $63,900
G1 Edu Ultimate A Humanoid Robot Dex3-1 3-finger 43 Jetson Orin, 100 TOPS Yes, high and low level 18 months $65,900
G1 Edu Ultimate B Humanoid Robot Dex3-1 3-finger, tactile 43 Jetson Orin, 100 TOPS Yes, high and low level 18 months $67,900
G1 Edu Ultimate C Humanoid Robot Inspire DFQ 41 Jetson Orin, 100 TOPS Yes, high and low level 18 months $67,900
G1 Edu Ultimate F Humanoid Robot BrainCo Revo 2, tactile 41 Jetson Orin, 100 TOPS Yes, high and low level 18 months $67,900
G1 Edu Ultimate D Humanoid Robot Inspire E2, tactile 41 Jetson Orin, 100 TOPS Yes, high and low level 18 months $73,900
G1 Edu Professional I Humanoid Robot Wuji Hand 2 63 Jetson Orin, 100 TOPS Yes, high and low level 18 months $73,900
G1 Edu Ultimate I Humanoid Robot Wuji Hand 2 69 Jetson Orin, 100 TOPS Yes, high and low level 18 months $83,900

Prices are US MSRP and exclude tax, duty and freight. Configurations, lead times and specifications are subject to change by the manufacturer.

Why the hands matter

What the dexterous hands actually do

Most of the price difference between the configurations above is the end effector. This is what the force-controlled hands buy you.

Footage courtesy of Unitree Robotics.

Gallery

See the Unitree G1 Humanoid Robot

The specialist builds

G1 Boxing: two robots sparring

The Boxing and Comp configurations are tuned for contact and crowd work rather than lab research.

Footage courtesy of Unitree Robotics.

What's included

In the box

  • Unitree G1 Robot
  • Quick-Release Smart Battery
  • Charger
  • Handheld Remote Controller
  • User Manual
  • 1-year Warranty and RobotLAB support
Talk to a specialist

Get pricing & a free demo of the Unitree G1 Humanoid Robot.

Same-day response. We handle delivery, on-site setup, staff training, and ongoing service nationwide.

Questions & answers

About the Unitree G1 Humanoid Robot.

  1. What is the Unitree G1 and who is it for?

    The Unitree G1 is a compact bipedal humanoid robot designed for research, development, and education. It is aimed at university labs, embodied-AI and manipulation researchers, and STEM programs that want a real humanoid platform — full leg, arm, and waist articulation with LiDAR and depth sensing — without the six-figure cost of a full-size humanoid.

  2. What are the key specifications?

    The G1 stands about 1.32 m tall and weighs roughly 35 kg with battery. It has 23 degrees of freedom standard (6 per leg, 5 per arm, 1 waist), expandable to as many as 43 DOF on EDU configurations with optional waist, wrist, and the three-fingered Dex3-1 dexterous hand. It carries a depth camera and 3D LiDAR, an 8-core CPU with optional high-performance compute, a quick-release 9000 mAh battery good for about 2 hours, and an arm payload around 2-3 kg.

  3. How much does the Unitree G1 cost and how do I buy one?

    RobotLAB lists 23 G1 configurations, from $17,990 to $83,900, depending on compute, degrees of freedom and which dexterous hands are fitted. Unitree's bare base unit starts lower (around $13.5K-$16K) but does not include secondary-development access or manipulation hardware. RobotLAB sells, leases, deploys, trains, and services the G1 nationwide — call 1-87-ROBOTLAB to configure a unit, get a quote, or arrange financing.

  4. How does the G1 compare to the Unitree H1 and H2?

    The H1 and H2 are full-size humanoids (around 1.8 m, 47-70 kg) built for higher-speed locomotion and heavier payloads — the H1 holds a 3.3 m/s walking record and the H2 adds a 31-DOF body with 7-DOF arms. The G1 is smaller, lighter, and more affordable, making it better suited to bench-scale R&D, classrooms, and teams that need a humanoid they can transport and iterate on quickly. Choose the H-series for full-size dynamics; choose the G1 for accessible, foldable humanoid research.

  5. How does the G1 compare to the Pudu D9?

    The Pudu D9 is a full-size humanoid (1.7 m, 65 kg) aimed at commercial object manipulation and customer engagement, with 42 DOF, dual 7-DOF arms, an 11-DOF DH11 hand, and up to 20 kg payload. The G1 is a smaller, lower-cost research and education platform rather than a commercial service robot. Pick the D9 for heavy commercial manipulation; pick the G1 for affordable humanoid R&D and teaching.

  6. Can I develop my own software on the G1?

    Yes — the EDU/developer configurations (which this build reflects) support secondary development, so your team can run custom code on the robot. Unitree provides imitation- and reinforcement-learning workflows plus the UnifoLM unified robot model. Note that the bare standard version does not support secondary development, so confirm the EDU configuration when ordering through RobotLAB.

  7. How do I see the G1 in action or arrange a demo?

    RobotLAB can arrange a demonstration and walk you through configurations, deployment, and training. Call 1-87-ROBOTLAB to schedule a demo or discuss a pilot for your lab or classroom.

Have another question? Same-day response.Request a quote →Book a demo
Related robots

More humanoid robots robots

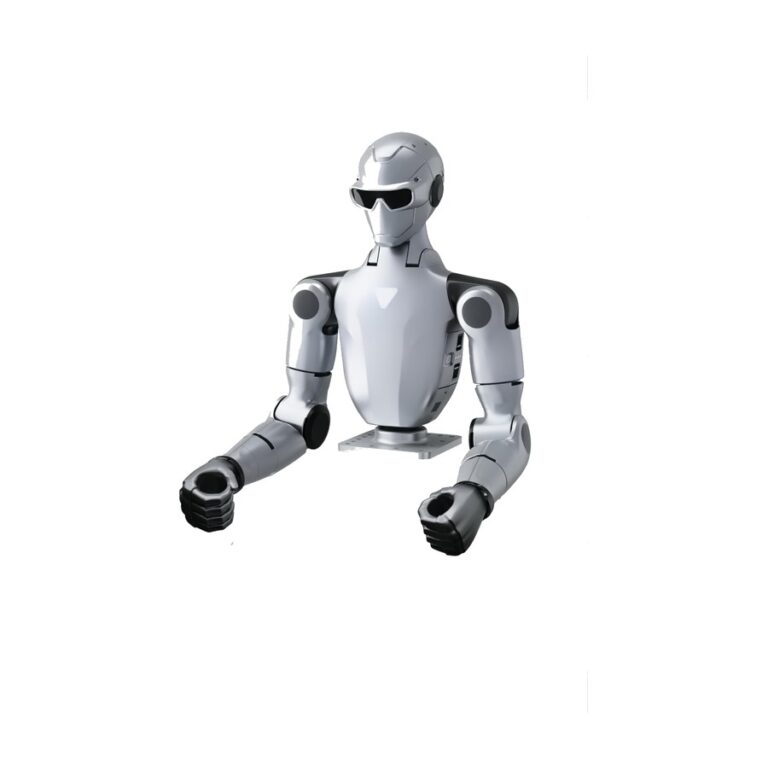
Unitree R1-A5 Dual-Arm Humanoid Robot
Unitree Humanoid

Unitree R1-A5 Dual-Arm Humanoid Robot

The Unitree R1-A5 is a fixed-base dual-arm humanoid: 13 degrees of freedom (5 per arm, 1 waist, 2 head), roughly 11 kg, with a 420 mm arm reach and about 2 kg payload per arm. The R1-A5-D variant adds a wheeled chassis a

From $7,200 purchase
NAO V6 Humanoid Robot
RobotLAB Robot

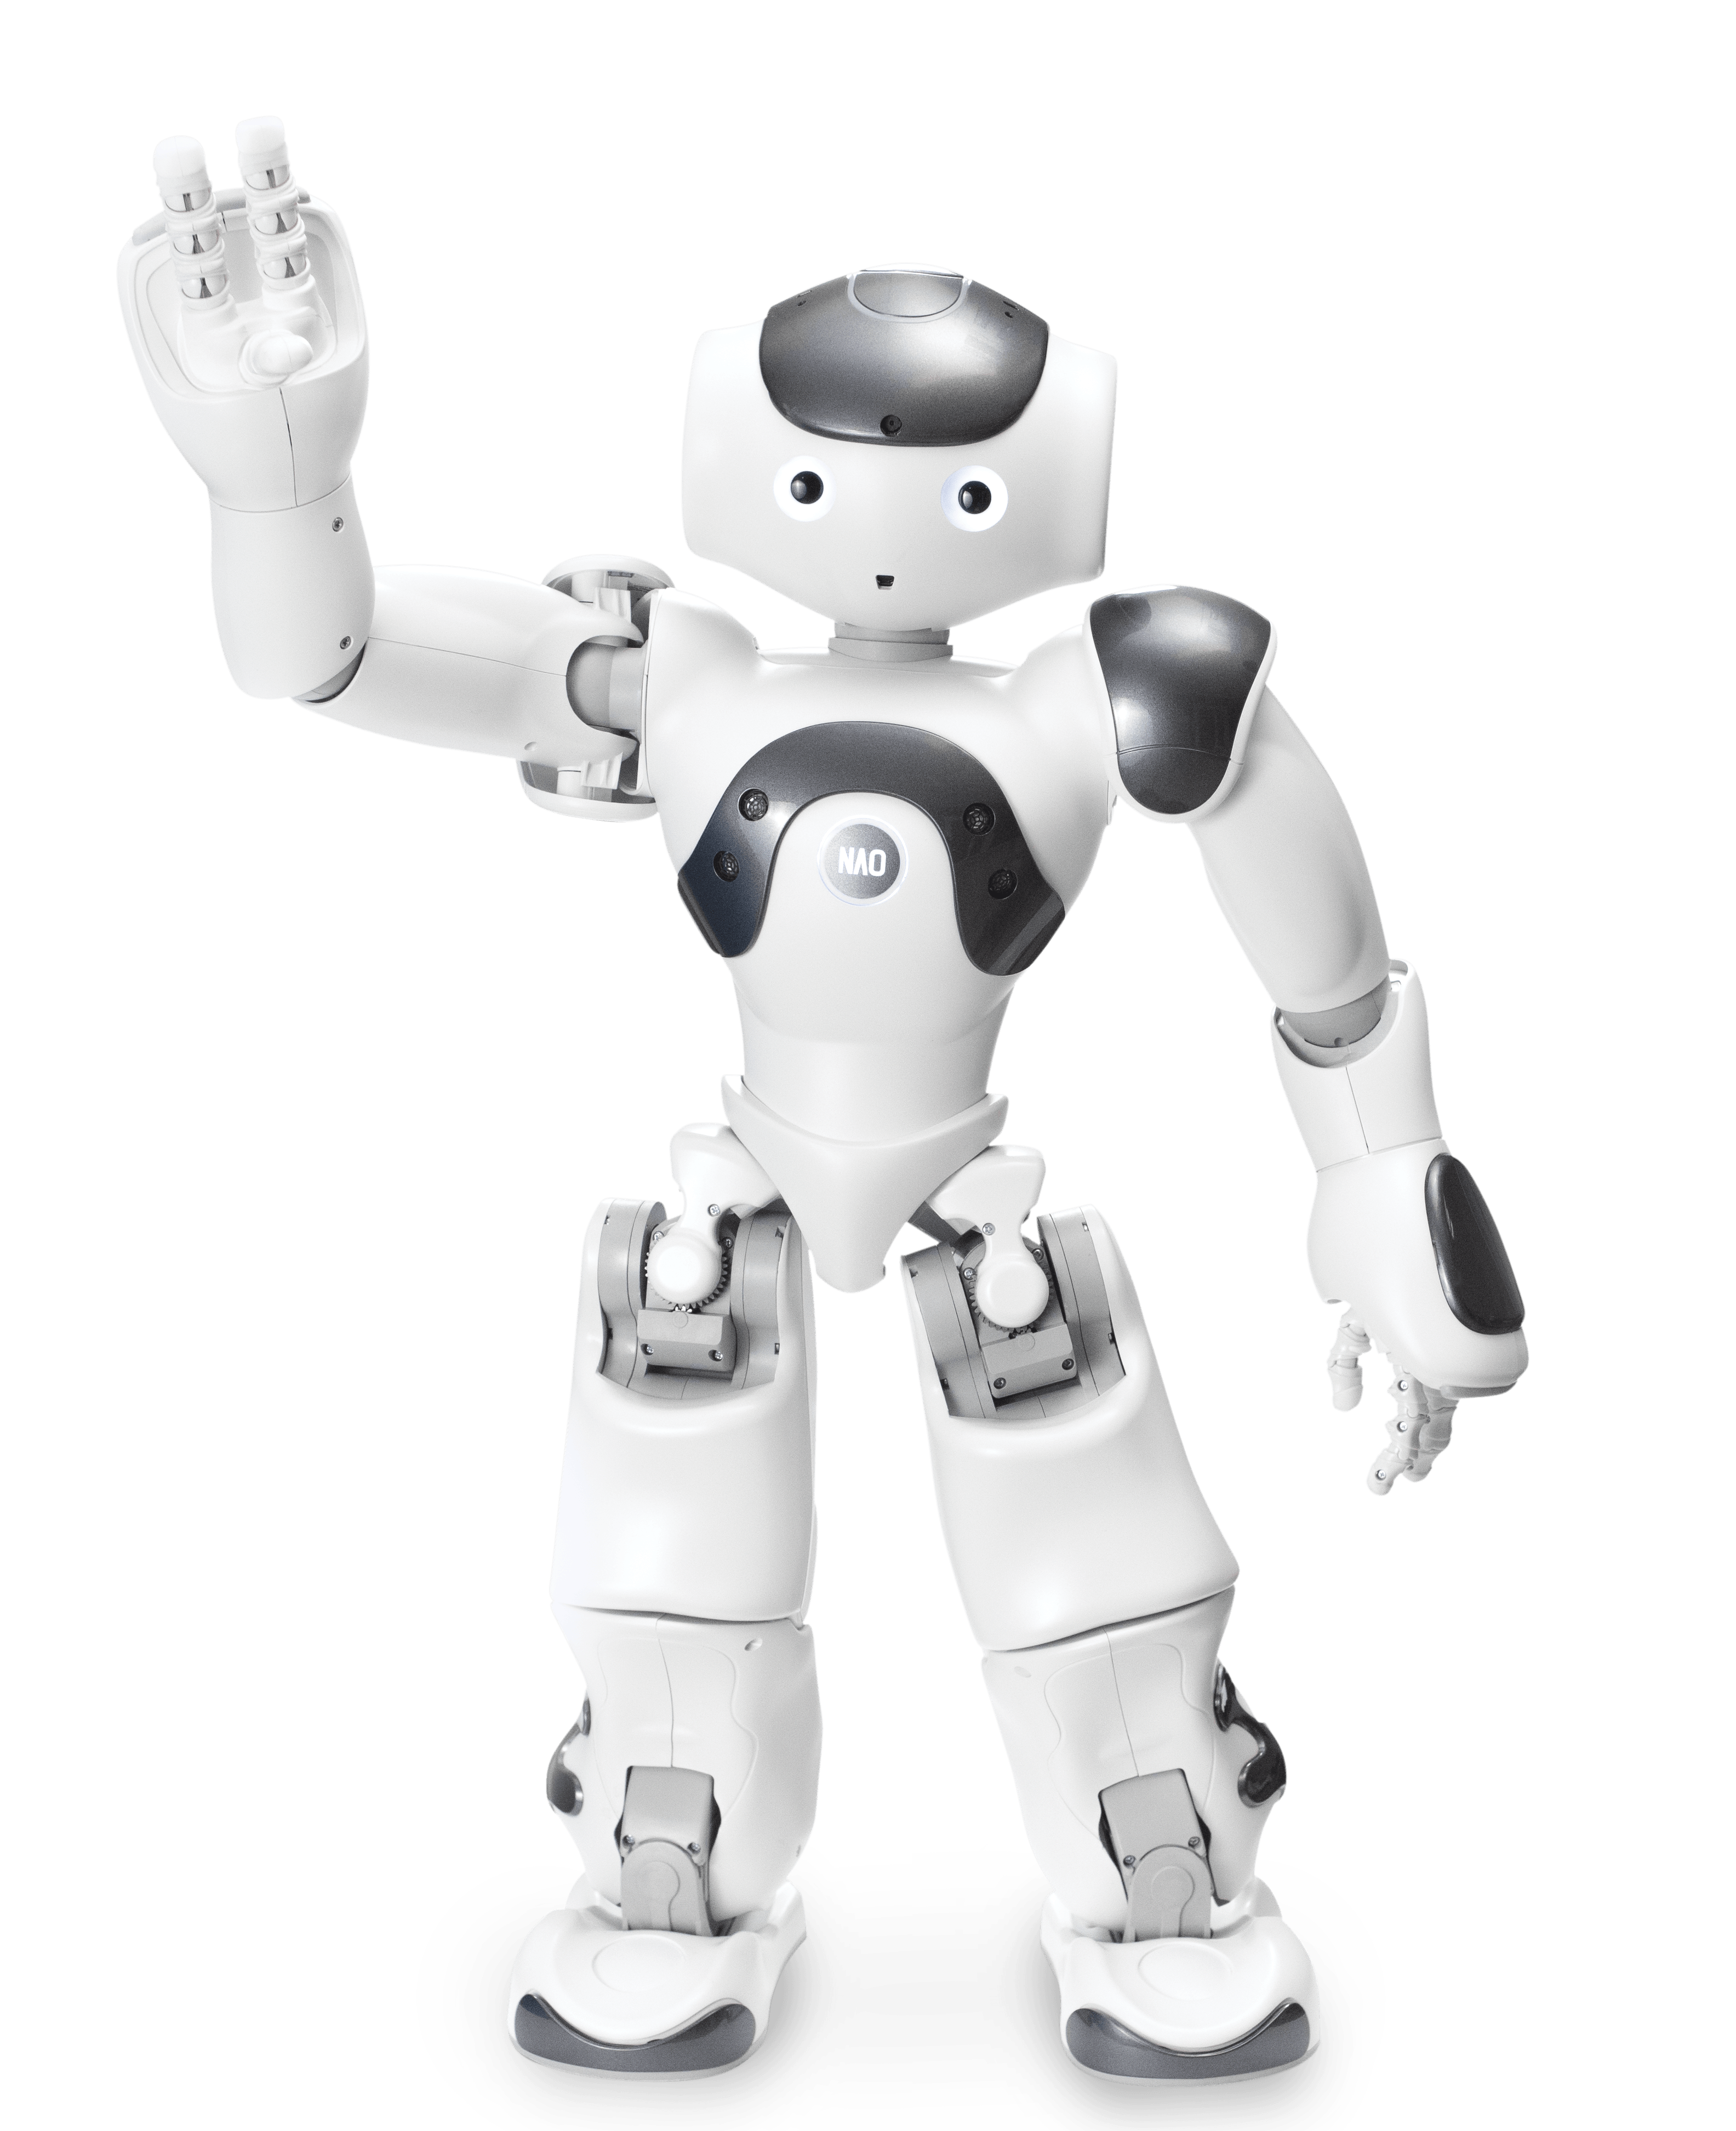
NAO V6 Humanoid Robot

The NAO V6 is the world's most widely deployed teaching humanoid — a 25-joint, fully programmable robot for K-12, special education, higher-ed, and research labs. Sold, deployed, and serviced nationwide by RobotLAB.

From $16,990 purchase
Unitree G1-D Humanoid Robot
Unitree Humanoid

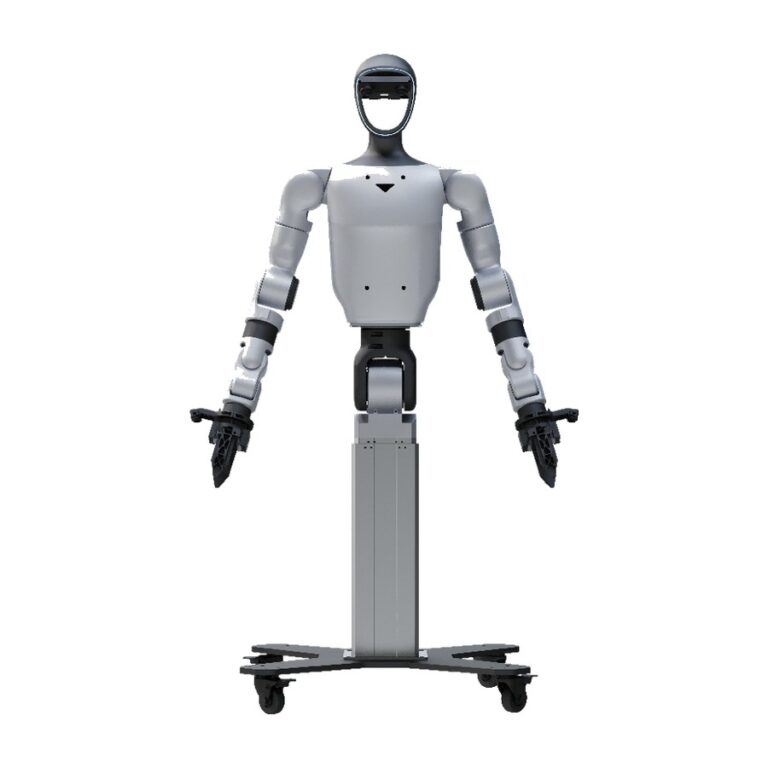
Unitree G1-D Humanoid Robot

The Unitree G1-D pairs the G1 upper body with a wheeled chassis and an end-to-end data-collection stack, aimed at teams gathering manipulation demonstrations at scale rather than working on locomotion.

From $38,800 purchase
Request a walkthrough