19 Years · America's Largest Robotics Integrator
Home/ Store/ Component/ Unitree Humanoid Hands & Grippers

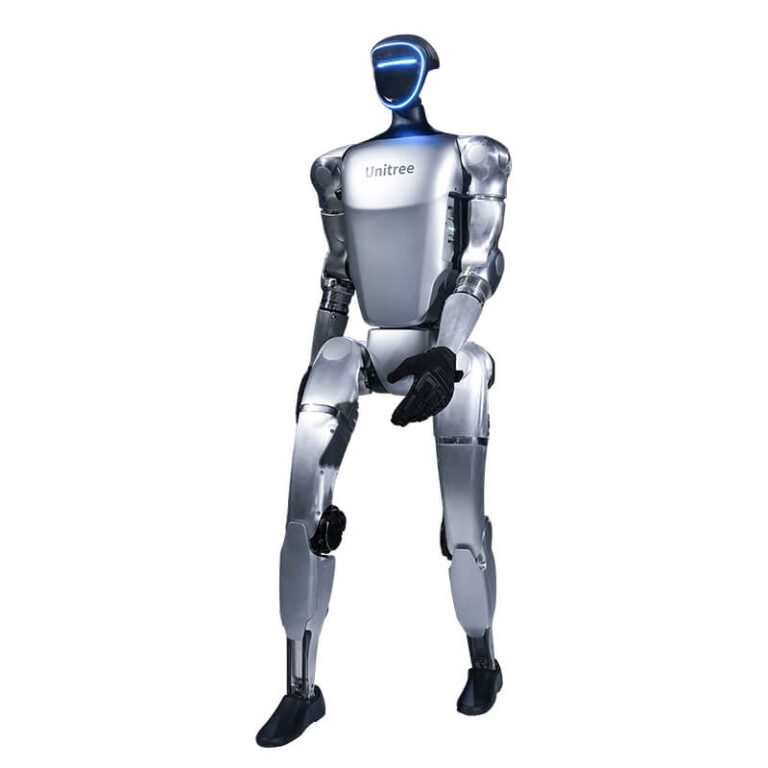
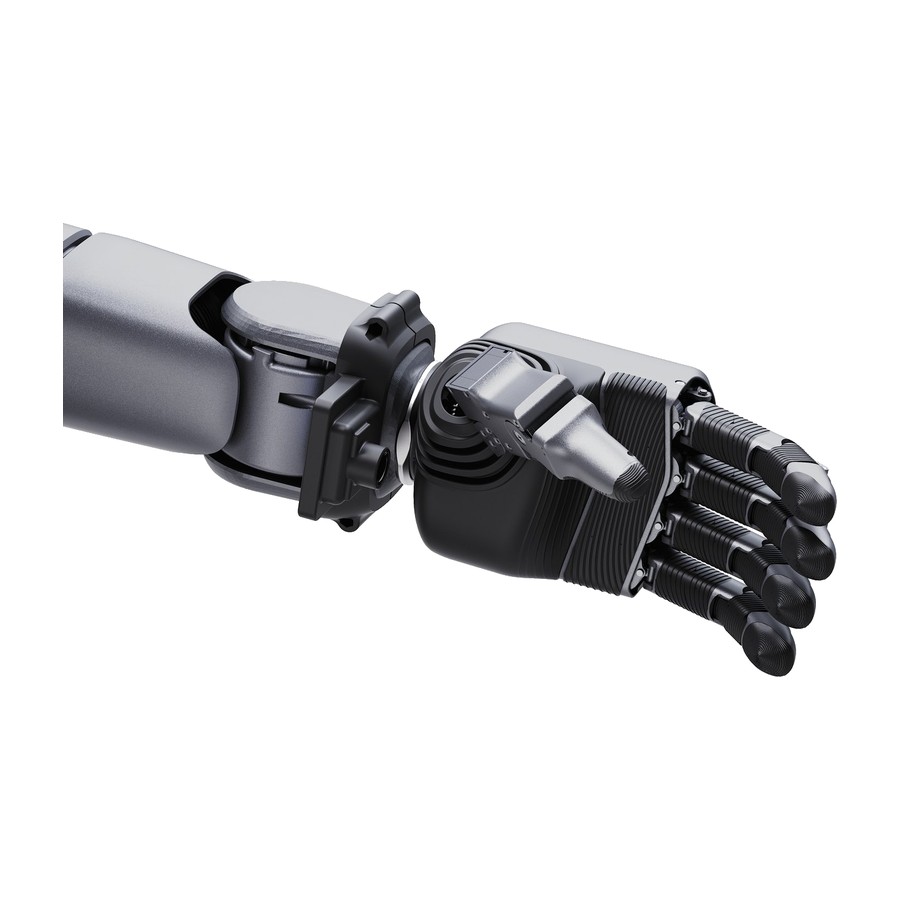
Unitree Humanoid Hands & Grippers

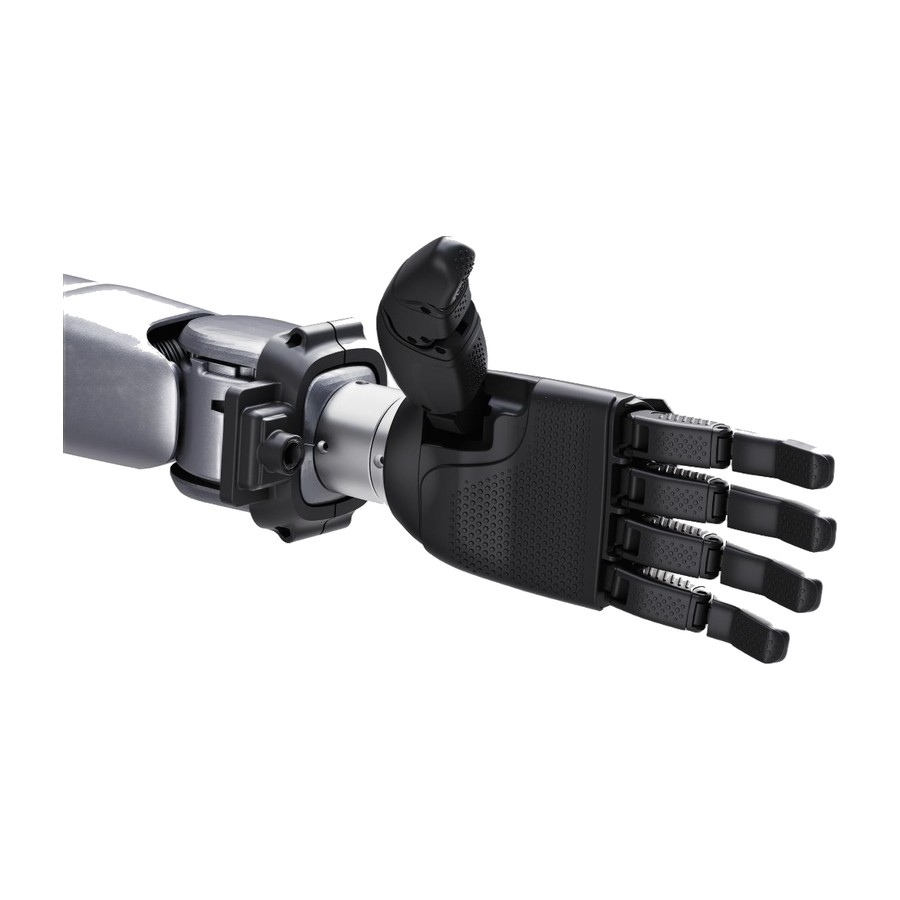
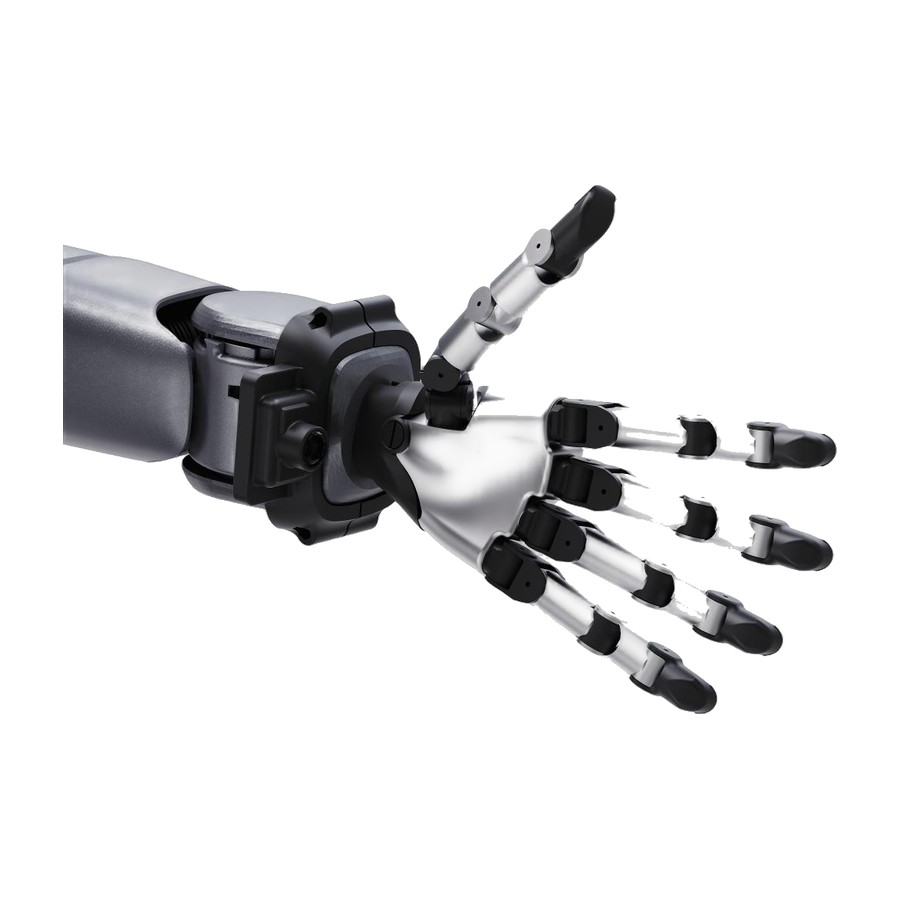
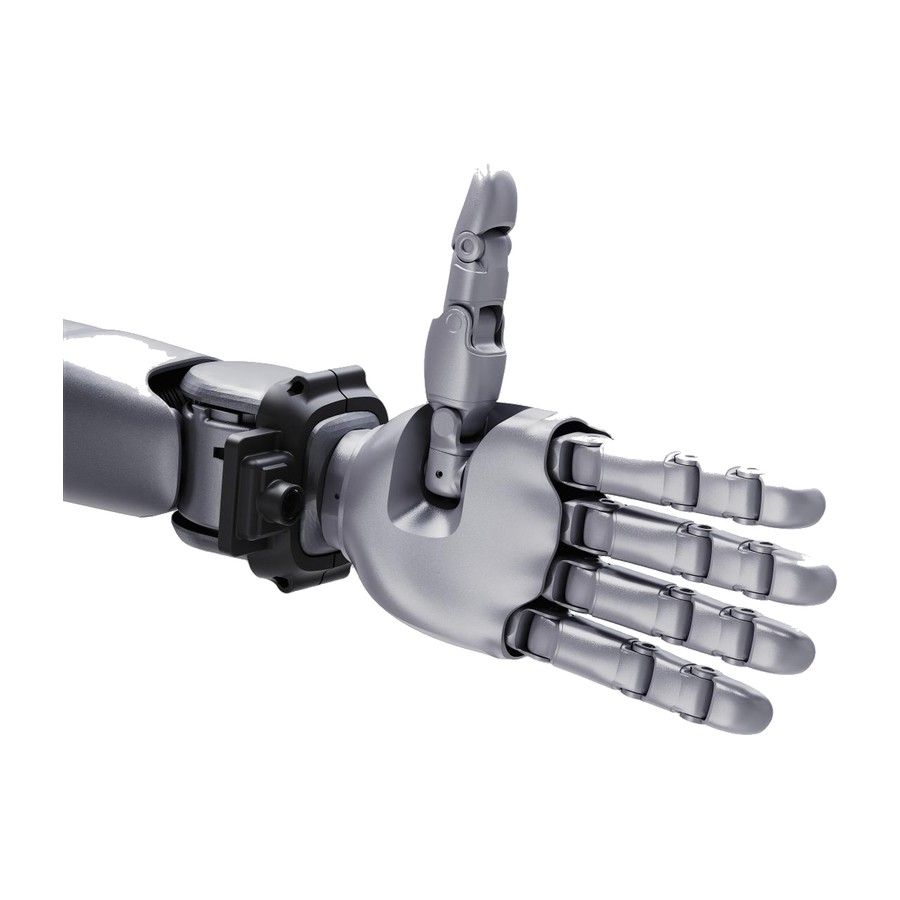
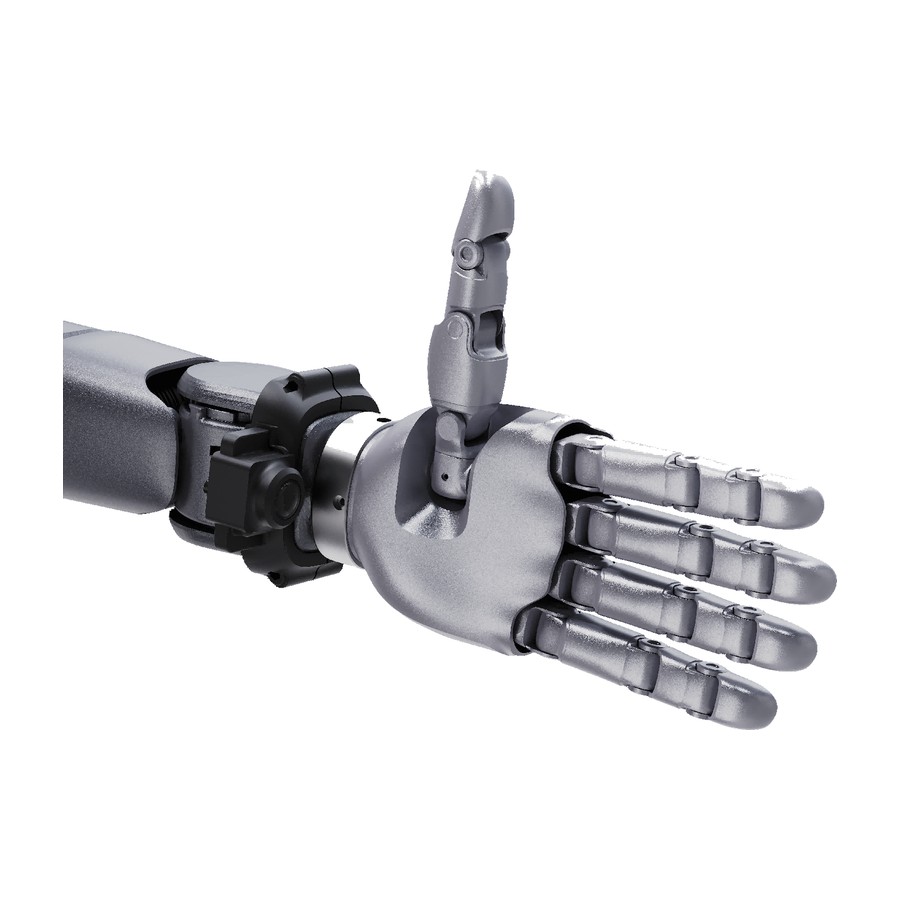
Every Unitree humanoid ships with a choice of end effector, and the hand is usually the single biggest factor in what a robot costs and what it can do. This page lists every hand and gripper in the 2026 range, what fits

Configurations from
$380 – $78,200
43 configurations · compare them

Purchase · Lease

Unitree Humanoid Hands & Grippers — Unitree
Manufacturer
Unitree
Capability
Humanoid Robots
Support
US sales, setup & service
Overview

What is the Unitree Humanoid Hands & Grippers?

Every Unitree humanoid ships with a choice of end effector, and the hand is usually the single biggest factor in what a robot costs and what it can do. This page lists every hand and gripper in the 2026 range, what fits which robot, and what each one costs.

Hands are quoted per unit. A humanoid normally takes two, and left and right must be specified when ordering.

RobotLAB supplies the full Unitree humanoid range in the United States, with 43 hand configurations currently listed, from $380 to $78,200. Every configuration below is quoted, supported and serviced from the US.

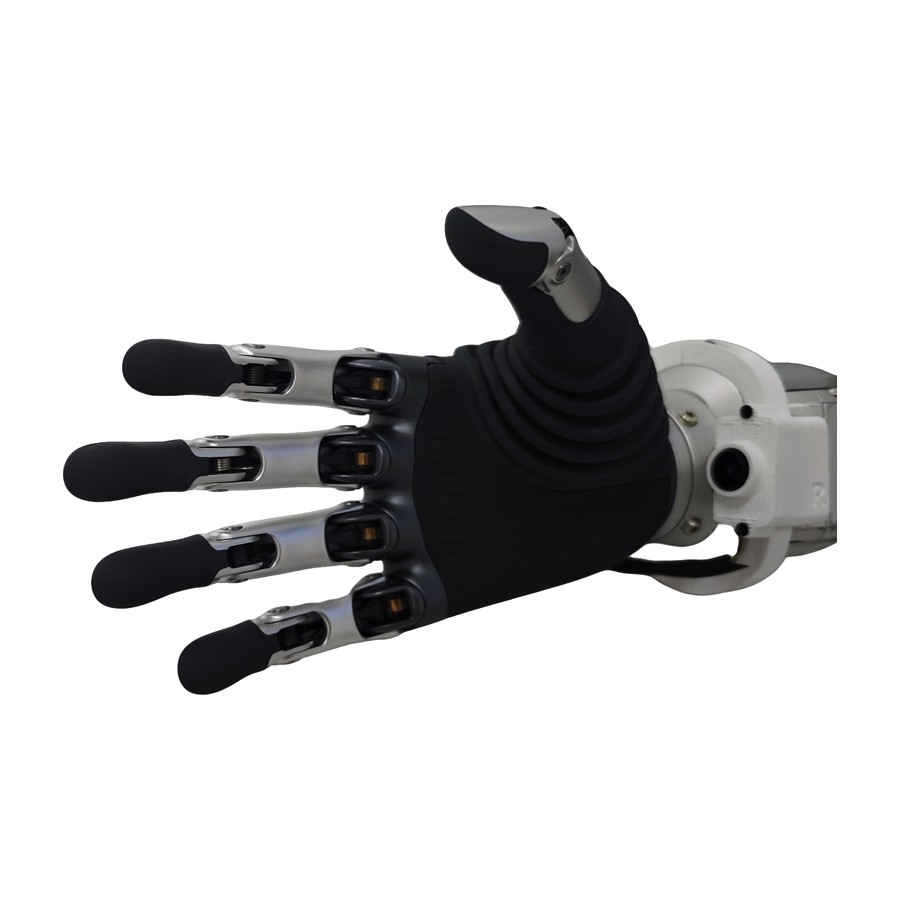
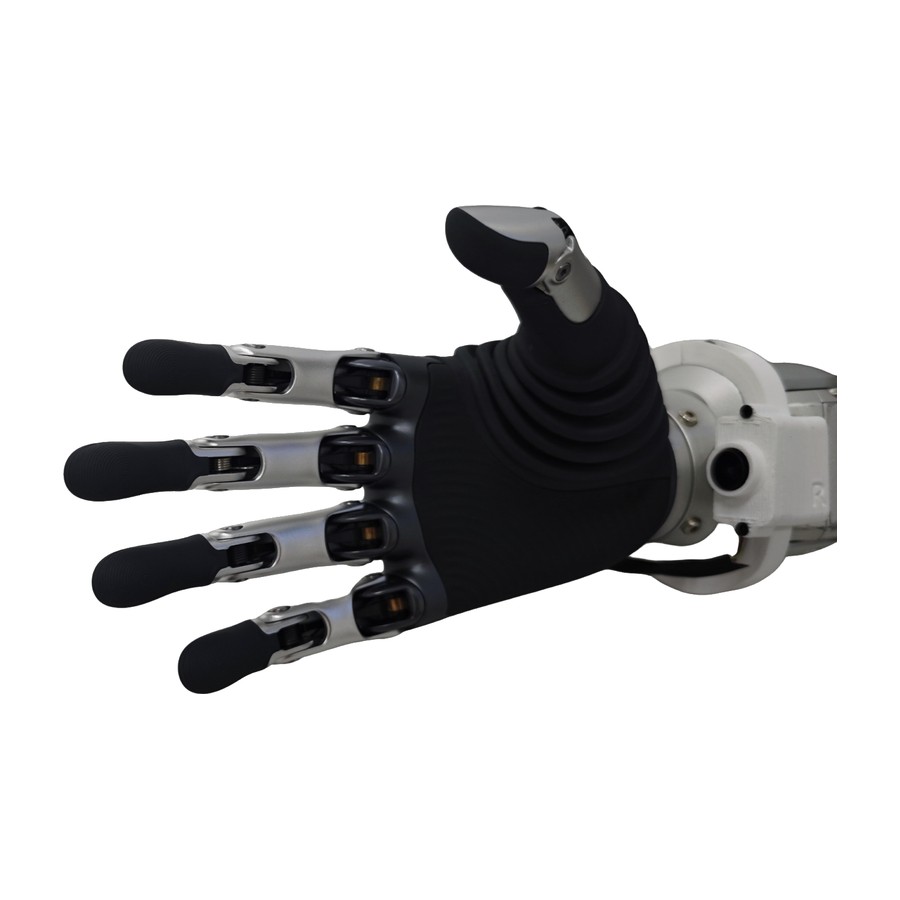
Three-finger, force controlled

Dex3-1 handling real objects

Teleoperated manipulation with the Dex3-1 — arranging blocks and handling items on a table.

Footage courtesy of Unitree Robotics.

How it works

Unitree Humanoid Hands & Grippers in detail

Choosing a configuration

The table below is the honest version of the spec sheet: it shows only what actually differs between configurations, so you can see what the extra money buys. Shared platform specifications are listed separately — they apply to every unit in the range.

Typical buyers are anyone specifying a Unitree humanoid. If you are not sure which build fits your work, ask us: we configure these for US customers every week and will tell you when a cheaper configuration does the job.

See the rest of the range on our humanoid robots page, or browse everything we carry from Unitree.

Humanoid hands configurator

Not sure which hand your robot needs?

Answer a few questions and we narrow 19 hands and grippers down to the three that fit your job, and show which Unitree robots each one works with. Every term, from degrees of freedom to repeatability, is explained in plain language as you go. No commitment.

  • A plain-language path for first-time buyers, a specs path for engineers
  • Tap any term like DoF or 0.1° repeatability for a simple explanation
  • Live list prices, what fits which robot, and a one-click quote request
Open the hands configurator → About two minutes. No commitment.
Unitree Dex5-1 five-finger dexterous hand
Configurations

Which Unitree Humanoid Hands & Grippers is right for you?

Each hand or gripper is built for a specific robot, so check what it fits. Prices are per hand, from $380 to $78,200. A humanoid normally takes two.

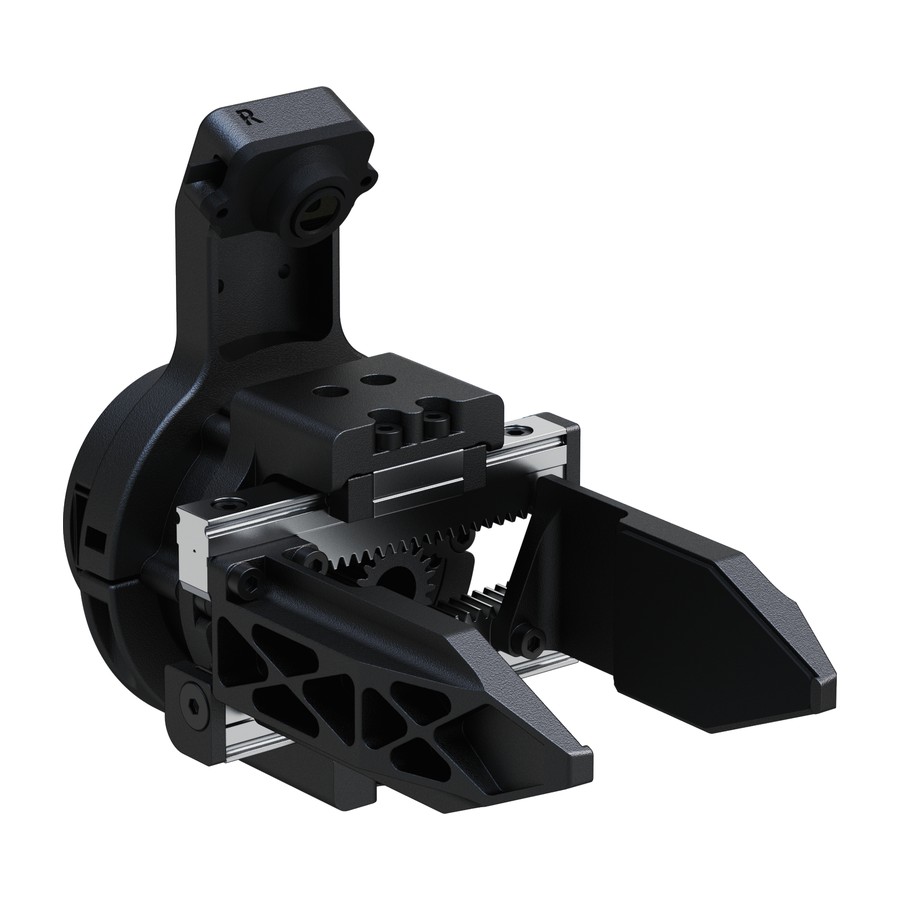
G1 Dex1-1 Gripper Standard

G1 Dex1-1 Gripper Standard

Dex1-1 Gripper Standard

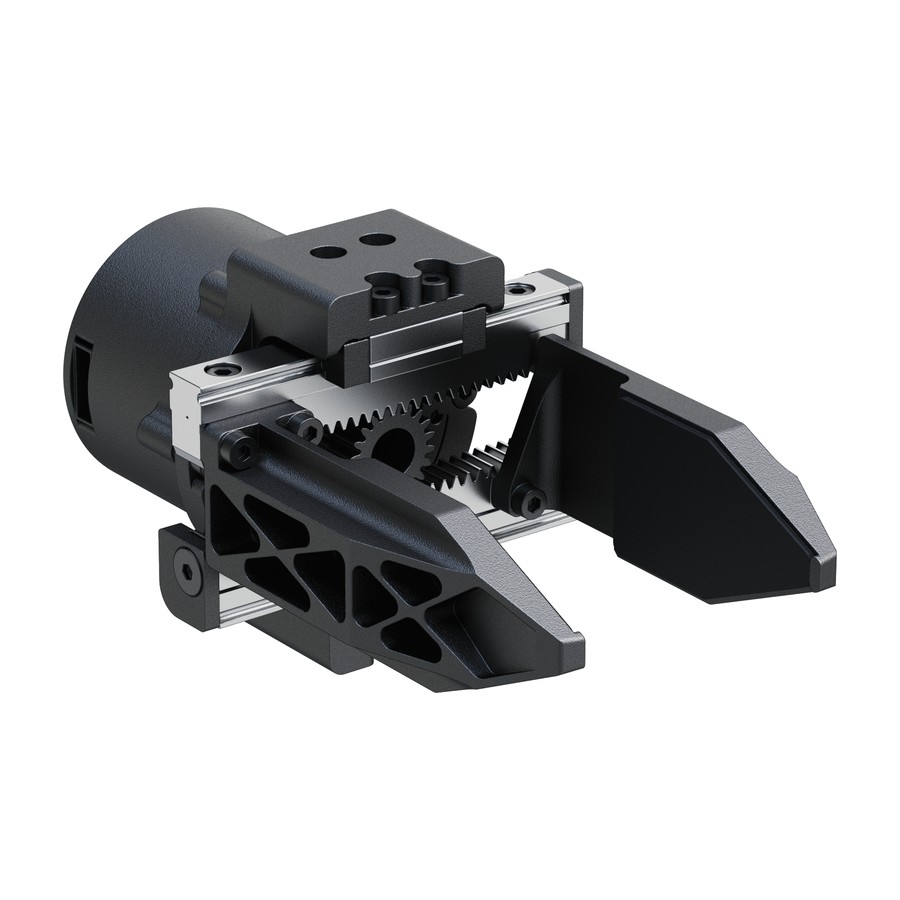
For the Unitree G1. Picking, placing and carrying rigid objects, at the lowest cost.

What it is
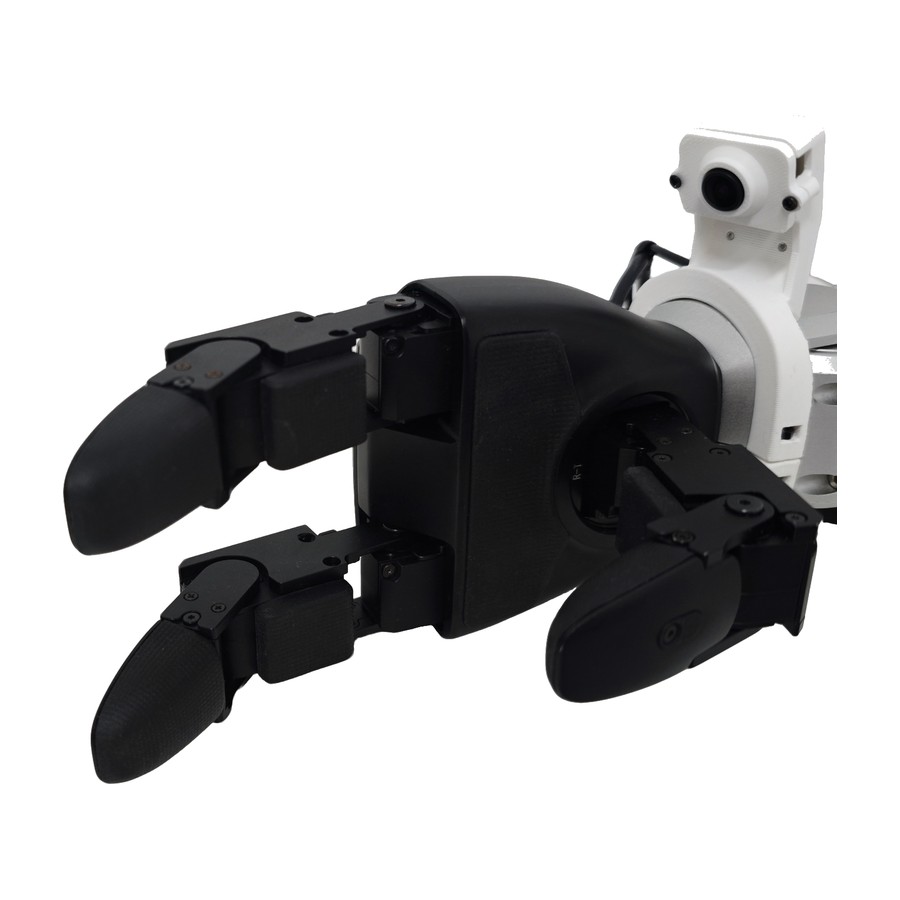
Two-finger gripper

A strong two-finger pinch, like a parallel-jaw tool. It only opens and closes, which also makes it the simplest and most reliable option.

Full specs and what they mean
Type
Two-finger gripper
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
Not included. A D405 camera bracket is included, the camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Picking, placing and carrying rigid objects, at the lowest cost.
Keep in mind
Cannot use tools made for human fingers, and has no camera of its own in this version.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • Sold separately or with the robot. You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
G1-D Dex1-1 Gripper Standard

G1-D Dex1-1 Gripper Standard

Dex1-1 Gripper Standard Version

For the Unitree G1-D. Picking, placing and carrying rigid objects, at the lowest cost.

What it is
Two-finger gripper

A strong two-finger pinch, like a parallel-jaw tool. It only opens and closes, which also makes it the simplest and most reliable option.

Full specs and what they mean
Type
Two-finger gripper
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
Not included. A D405 camera bracket is included, the camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Picking, placing and carrying rigid objects, at the lowest cost.
Keep in mind
Cannot use tools made for human fingers, and has no camera of its own in this version.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • Sold separately or with the robot. You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
R1 Dex1-1 Gripper Standard

R1 Dex1-1 Gripper Standard

R1 Dedicated Dex1-1 Gripper Standard Version

For the Unitree R1. Picking, placing and carrying rigid objects, at the lowest cost.

What it is
Two-finger gripper

A strong two-finger pinch, like a parallel-jaw tool. It only opens and closes, which also makes it the simplest and most reliable option.

Full specs and what they mean
Type
Two-finger gripper
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
Not included. A D405 camera bracket is included, the camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Picking, placing and carrying rigid objects, at the lowest cost.
Keep in mind
Cannot use tools made for human fingers, and has no camera of its own in this version.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
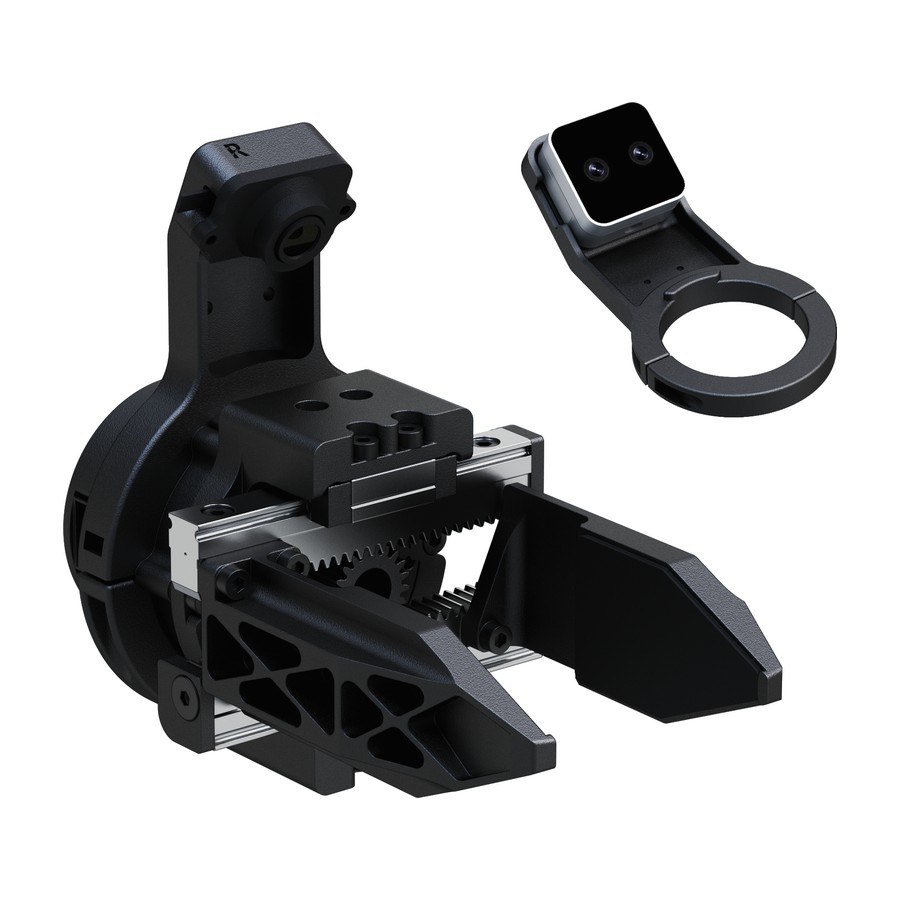
G1 Dex1-1 Gripper Advanced

G1 Dex1-1 Gripper Advanced

Dex1-1 Gripper Advanced

For the Unitree G1. Vision-guided pick and place and low-cost data collection.

What it is
Two-finger gripper with wrist camera

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • Sold separately or with the robot. You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
G1-D Dex1-1 Gripper Advanced

G1-D Dex1-1 Gripper Advanced

Dex1-1 Gripper Advanced Edition

For the Unitree G1-D. Vision-guided pick and place and low-cost data collection.

What it is
Two-finger gripper with wrist camera

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • Sold separately or with the robot. You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
H2- Dex1-1 Gripper Advanced

H2- Dex1-1 Gripper Advanced

Dex1-1 Gripper Advanced Edition

For the Unitree H2. Vision-guided pick and place and low-cost data collection.

What it is
Two-finger gripper with wrist camera

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • Sold separately or with the robot. You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
R1- Dex1-1 Gripper Advanced

R1- Dex1-1 Gripper Advanced

Dex1-1 Gripper Advanced Version

For the Unitree R1. Vision-guided pick and place and low-cost data collection.

What it is
Two-finger gripper with wrist camera

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
G1-D Dex1-1 Gripper Ultimate

G1-D Dex1-1 Gripper Ultimate

Dex1-1 Gripper Ultimate Edition

For the Unitree G1-D. Precise vision-guided grasping and data collection on the G1-D.

What it is
Two-finger gripper with RGB and depth cameras

The gripper with both a colour camera and a depth camera at the wrist, so the robot can judge distance up close.

Full specs and what they mean
Type
Two-finger gripper with RGB and depth cameras
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera plus Intel RealSense D405 depth camera, with mounts.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Precise vision-guided grasping and data collection on the G1-D.
Keep in mind
G1-D only. Cannot use tools made for human fingers.
Compare every hand, with terms explained →
  • Price is for one gripper. A humanoid normally takes two.
  • Sold separately or with the robot. You fit it yourself, with instructions provided.
  • Includes RS-485 to USB board, cables and accessories.
$1,080 Get a quote
G1 DEX 2/5

G1 DEX 2/5

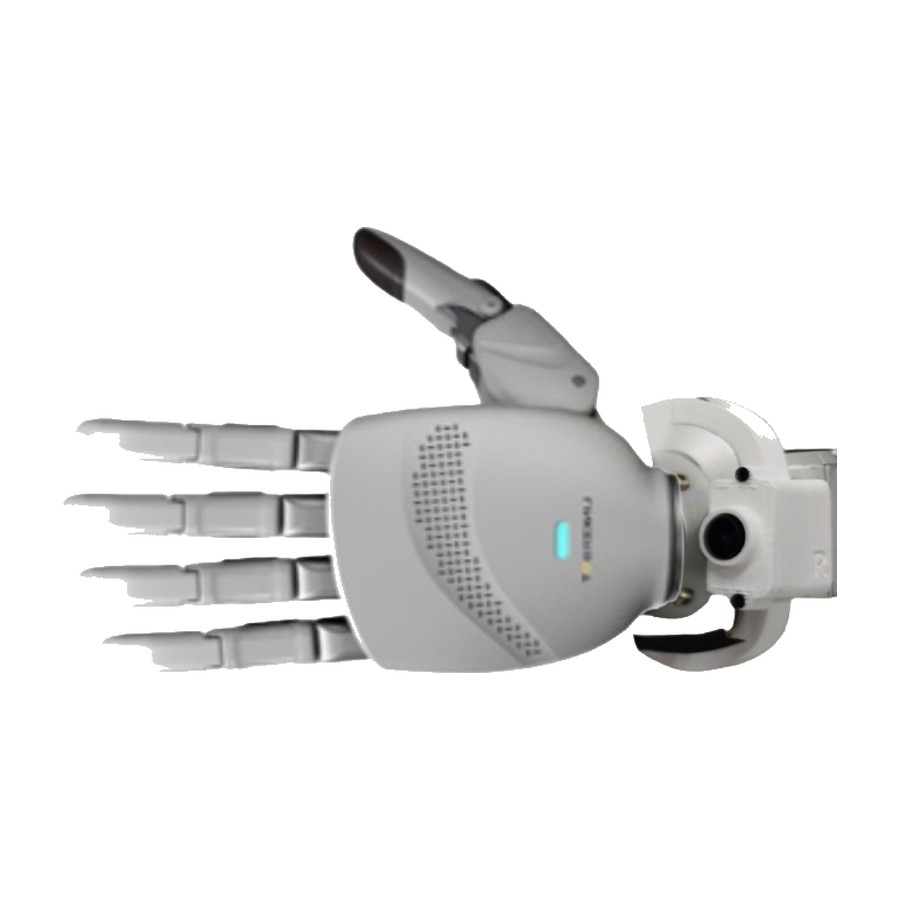
DEX 2/5

For the Unitree G1. A human look for shows and presence, and simple light grasps, at low cost.

What it is
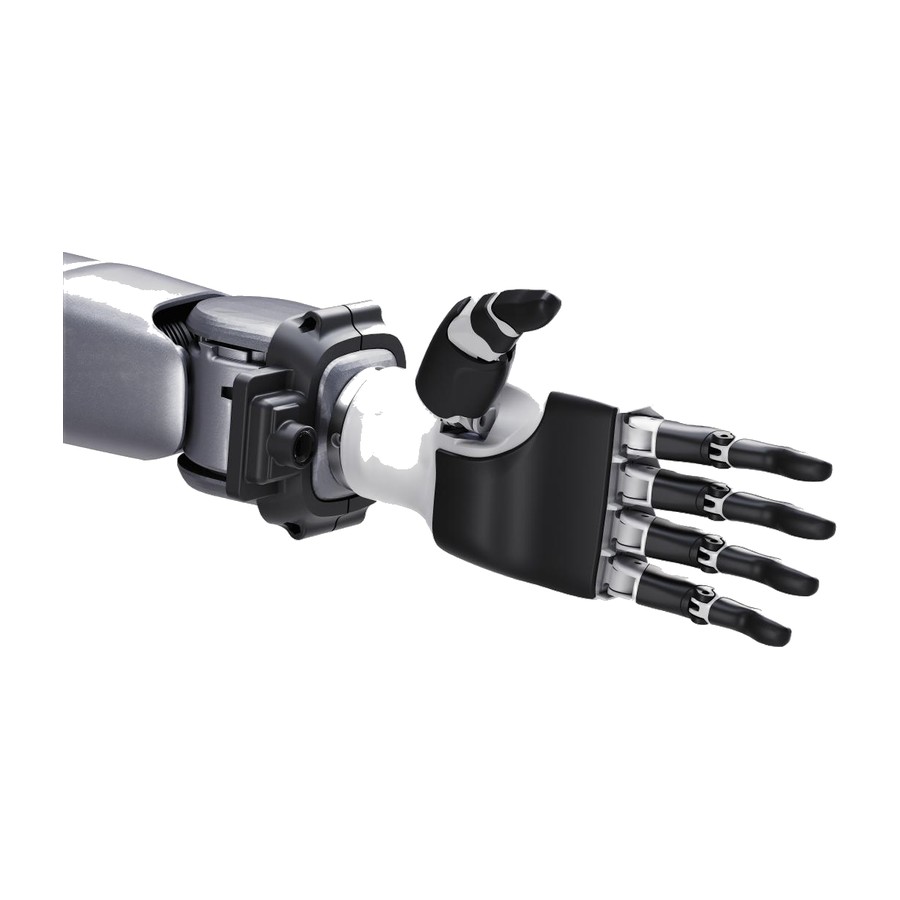
Five-finger tendon-driven hand

Looks like a human hand and closes around objects, but moves as a unit. It cannot move each finger on its own.

Full specs and what they mean
Type
Five-finger tendon-driven hand
Motion
2 DoF per hand. 2 motors drive 10 joints: the four fingers share one motor, the thumb has the other.
Force
10 to 15 N at the fingertip
Load
1.5 kg
Smallest grip
8 mm
Touch
None
Wrist camera
Not included
Weight
365 g
Size
151 × 70 × 63 mm
Drive
Gear and tendon
Control
Joint position, velocity, torque, stiffness and damping
Interface
RS-485, 1000 Hz, no external wiring between hand and robot
Software
URDF model available
Best for
A human look for shows and presence, and simple light grasps, at low cost.
Keep in mind
No finger-by-finger control, no touch sensing, no camera. Not for manipulation research.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$1,490 Get a quote
R1 Tendon Cable Dexterous Hand

R1 Tendon Cable Dexterous Hand

Tendon Cable Dexterous Hand

For the Unitree R1. A human look for shows and presence, and simple light grasps, at low cost.

What it is
Five-finger tendon-driven hand

Looks like a human hand and closes around objects, but moves as a unit. It cannot move each finger on its own.

Full specs and what they mean
Type
Five-finger tendon-driven hand
Motion
2 DoF per hand. 2 motors drive 10 joints: the four fingers share one motor, the thumb has the other.
Force
10 to 15 N at the fingertip
Load
1.5 kg
Smallest grip
8 mm
Touch
None
Wrist camera
Not included
Weight
365 g
Size
151 × 70 × 63 mm
Drive
Gear and tendon
Control
Joint position, velocity, torque, stiffness and damping
Interface
RS-485, 1000 Hz, no external wiring between hand and robot
Software
URDF model available
Best for
A human look for shows and presence, and simple light grasps, at low cost.
Keep in mind
No finger-by-finger control, no touch sensing, no camera. Not for manipulation research.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$1,490 Get a quote
R1 LinkerBot Linker Hand O6 (Non-Tactile) (with RGB Camera)

R1 LinkerBot Linker Hand O6 (Non-Tactile) (with RGB Camera)

LinkerBot Linker Hand O6 (Non-Tactile Version) (with RGB Camera)

For the Unitree R1. Natural five-finger grasps on an R1 on a limited budget.

What it is
Five-finger hand

An affordable five-finger hand. Each finger closes on its own, and the thumb has two motors so it can move across the palm.

Full specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints: 6 active and 5 passive that follow.
Force
70 N whole hand; 20 N thumb, 25 N fingers at the fingertip
Touch
None
Repeatability
Under ±0.20 mm
Wrist camera
RGB wrist camera, 160° field of view, with mount
Weight
About 370 g
Drive
Rigid linkage with worm gear
Control
Force-position hybrid
Interface
CAN or RS-485
Software
ROS, ROS 2 and Python SDKs from LinkerBot
Best for
Natural five-finger grasps on an R1 on a limited budget.
Keep in mind
R1 family only. No touch sensing on this version.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$1,590 Get a quote
R1 LinkerBot Linker Hand O6 (Tactile) (includes RGB camera)

R1 LinkerBot Linker Hand O6 (Tactile) (includes RGB camera)

LinkerBot Linker Hand O6 (Tactile Version) (includes RGB camera)

For the Unitree R1. An affordable way to get a five-finger hand with touch.

What it is
Five-finger hand with touch sensing

The Linker O6 with touch sensing added, so software can tell when and how firmly it is touching something.

Full specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints: 6 active and 5 passive that follow.
Force
70 N whole hand; 20 N thumb, 25 N fingers at the fingertip
Touch
Touch sensing included
Repeatability
Under ±0.20 mm
Wrist camera
RGB wrist camera, 160° field of view, with mount
Weight
About 370 g
Drive
Rigid linkage with worm gear
Control
Force-position hybrid
Interface
CAN or RS-485
Software
ROS, ROS 2 and Python SDKs from LinkerBot
Best for
An affordable way to get a five-finger hand with touch.
Keep in mind
R1 family only.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$1,790 Get a quote
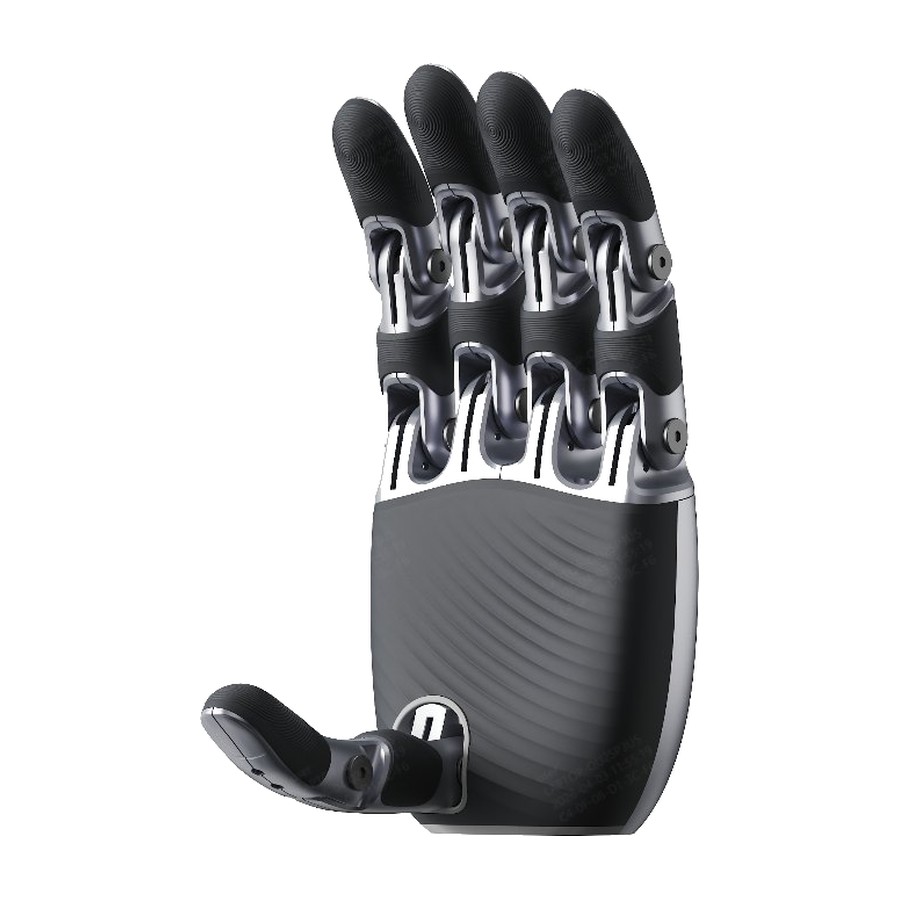
G1 BrainCo Bionic Dexterous Hand Revo 2 Basic (With RGB)

G1 BrainCo Bionic Dexterous Hand Revo 2 Basic (With RGB)

BrainCo Bionic Dexterous Hand Revo 2 Basic (With RGB)

For the Unitree G1. Everyday objects like cups and handles on any Unitree humanoid.

What it is
Five-finger hand

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$6,680 Get a quote
G1-D BrainCo Bionic Dexterous Hand Revo 2 Basic (Includes RGB Camera)

G1-D BrainCo Bionic Dexterous Hand Revo 2 Basic (Includes RGB Camera)

G1-D Dedicated BrainCo Bionic Dexterous Hand Revo 2 Basic Edition (Includes RGB Camera)

For the Unitree G1-D. Everyday objects like cups and handles on any Unitree humanoid.

What it is
Five-finger hand

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$6,680 Get a quote
H2 BrainCo Bionic Dexterous Hand Revo 2 Basic (With RGB)

H2 BrainCo Bionic Dexterous Hand Revo 2 Basic (With RGB)

H2 Dedicated BrainCo Bionic Dexterous Hand Revo 2 Basic Version (With RGB)

For the Unitree H2. Everyday objects like cups and handles on any Unitree humanoid.

What it is
Five-finger hand

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$6,680 Get a quote
R1 BrainCo Bionic Dexterous Hand Revo 2 Basic (Includes RGB Camera)

R1 BrainCo Bionic Dexterous Hand Revo 2 Basic (Includes RGB Camera)

R1 Dedicated BrainCo Bionic Dexterous Hand Revo 2 Basic Version (Includes RGB Camera)

For the Unitree R1. Everyday objects like cups and handles on any Unitree humanoid.

What it is
Five-finger hand

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$6,680 Get a quote
G1 Dex3-1 Force-controlled Three-finger Dexterous Hand (With RGB)

G1 Dex3-1 Force-controlled Three-finger Dexterous Hand (With RGB)

Dex3-1 Force-controlled Three-finger Dexterous Hand (With RGB)

For the Unitree G1. Manipulation research and teleoperation on the G1, G1-D, H2 and R1.

What it is
Three-finger force-controlled hand

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$7,680 Get a quote
G1-D Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Includes RGB Camera)

G1-D Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Includes RGB Camera)

Dex3-1 Force-Controlled Three-Finger Dexterous Hand for G1-D (Includes RGB Camera)

For the Unitree G1-D. Manipulation research and teleoperation on the G1, G1-D, H2 and R1.

What it is
Three-finger force-controlled hand

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$7,680 Get a quote
H2- Dex3-1 Force-Controlled Three-Finger Dexterous Hand

H2- Dex3-1 Force-Controlled Three-Finger Dexterous Hand

Dex3-1 Force-Controlled Three-Finger Dexterous Hand for H2

For the Unitree H2. Manipulation research and teleoperation on the G1, G1-D, H2 and R1.

What it is
Three-finger force-controlled hand

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • Order together with an H2. Unitree does not sell this one separately, except as a repair part.
$7,680 Get a quote
R1 Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Includes RGB Camera)

R1 Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Includes RGB Camera)

R1 Dedicated Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Includes RGB Camera)

For the Unitree R1. Manipulation research and teleoperation on the G1, G1-D, H2 and R1.

What it is
Three-finger force-controlled hand

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$7,680 Get a quote
G1 Dex3-1 Force-controlled Three-finger Dexterous Hand (Tactile ) (With RGB)

G1 Dex3-1 Force-controlled Three-finger Dexterous Hand (Tactile ) (With RGB)

Dex3-1 Force-controlled Three-finger Dexterous Hand (Tactile ) (With RGB)

For the Unitree G1. Learning from touch, and handling delicate objects, in manipulation research.

What it is
Three-finger force-controlled hand with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
G1 BrainCo Bionic Dexterous Hand Revo 2 Tactile (With RGB)

G1 BrainCo Bionic Dexterous Hand Revo 2 Tactile (With RGB)

BrainCo Bionic Dexterous Hand Revo 2 Tactile (With RGB)

For the Unitree G1. Handling fragile objects, and recording touch data to train AI.

What it is
Five-finger hand with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
G1 Inspire DFQ Series Dexterous Hand (With RGB)

G1 Inspire DFQ Series Dexterous Hand (With RGB)

Inspire DFQ Series Dexterous Hand (With RGB)

For the Unitree G1. Fast, human-like motion for demonstrations and light objects.

What it is
Five-finger hand

A fast, light-duty five-finger hand. Quick fingers, but low fingertip force compared with the others here.

Full specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
6 N thumb, 4 N fingers
Speed
Fingers flex at 570°/s, thumb at 150°/s
Touch
None
Repeatability
±0.20 mm
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Best for
Fast, human-like motion for demonstrations and light objects.
Keep in mind
Low fingertip force, so not for heavy objects. No touch sensing. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
G1-D Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile)

G1-D Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile)

G1-D Dedicated Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile Version) (Includes RGB Camera)

For the Unitree G1-D. Learning from touch, and handling delicate objects, in manipulation research.

What it is
Three-finger force-controlled hand with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
G1-D BrainCo Bionic Dexterous Hand Revo 2 Tactile (Includes RGB Camera)

G1-D BrainCo Bionic Dexterous Hand Revo 2 Tactile (Includes RGB Camera)

G1-D Dedicated BrainCo Bionic Dexterous Hand Revo 2 Tactile Edition (Includes RGB Camera)

For the Unitree G1-D. Handling fragile objects, and recording touch data to train AI.

What it is
Five-finger hand with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
H2- Dex3-1 Force-Controlled Three-Finger Dexterous Hand (tactile)

H2- Dex3-1 Force-Controlled Three-Finger Dexterous Hand (tactile)

Dex3-1 Force-Controlled Three-Finger Dexterous Hand (tactile version)

For the Unitree H2. Learning from touch, and handling delicate objects, in manipulation research.

What it is
Three-finger force-controlled hand with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • Order together with an H2. Unitree does not sell this one separately, except as a repair part.
$8,680 Get a quote
H2 BrainCo Bionic Dexterous Hand Revo 2 Tactile (With RGB)

H2 BrainCo Bionic Dexterous Hand Revo 2 Tactile (With RGB)

H2 Dedicated BrainCo Bionic Dexterous Hand Revo 2 Tactile Version (With RGB)

For the Unitree H2. Handling fragile objects, and recording touch data to train AI.

What it is
Five-finger hand with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
H2 Inspire DFQ Series Dexterous Hand (With RGB)

H2 Inspire DFQ Series Dexterous Hand (With RGB)

H2 Dedicated Inspire DFQ Series Dexterous Hand (With RGB)

For the Unitree H2. Fast, human-like motion for demonstrations and light objects.

What it is
Five-finger hand

A fast, light-duty five-finger hand. Quick fingers, but low fingertip force compared with the others here.

Full specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
6 N thumb, 4 N fingers
Speed
Fingers flex at 570°/s, thumb at 150°/s
Touch
None
Repeatability
±0.20 mm
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Best for
Fast, human-like motion for demonstrations and light objects.
Keep in mind
Low fingertip force, so not for heavy objects. No touch sensing. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • Order together with an H2. Unitree does not sell this one separately, except as a repair part.
$8,680 Get a quote
R1 Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile)

R1 Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile)

R1 Dedicated Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile Version) (Includes RGB Camera)

For the Unitree R1. Learning from touch, and handling delicate objects, in manipulation research.

What it is
Three-finger force-controlled hand with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
R1 BrainCo Bionic Dexterous Hand Revo 2 Tactile (Includes RGB Camera)

R1 BrainCo Bionic Dexterous Hand Revo 2 Tactile (Includes RGB Camera)

R1 Dedicated BrainCo Bionic Dexterous Hand Revo 2 Tactile Version (Includes RGB Camera)

For the Unitree R1. Handling fragile objects, and recording touch data to train AI.

What it is
Five-finger hand with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$8,680 Get a quote
H2 Inspire E2 Series Dexterous Hand (With RGB)

H2 Inspire E2 Series Dexterous Hand (With RGB)

H2 Dedicated Inspire E2 Series Dexterous Hand (With RGB)

For the Unitree H2. Five-finger work that needs both real fingertip force and touch.

What it is
Five-finger hand with touch sensing

A sturdier five-finger hand with strong fingertips and 17 touch sensors.

Full specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
30 N whole hand; 30 N thumb, 28 N fingers at the fingertip
Load
15 kg
Speed
Closes the palm in 0.8 s
Touch
17 tactile sensors, 0 to 30 N
Repeatability
±0.20 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 790 g
Drive
Linear servos
Control
Force-threshold control
Interface
RS-485 or CAN, plus Modbus TCP
Software
Supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Five-finger work that needs both real fingertip force and touch.
Keep in mind
Heavier than the Revo 2 and Linker O6, which uses up more arm payload. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • Order together with an H2. Unitree does not sell this one separately, except as a repair part.
$10,530 Get a quote
G1 Inspire E2 Series Dexterous Hand (With RGB)

G1 Inspire E2 Series Dexterous Hand (With RGB)

Inspire E2 Series Dexterous Hand (With RGB)

For the Unitree G1. Five-finger work that needs both real fingertip force and touch.

What it is
Five-finger hand with touch sensing

A sturdier five-finger hand with strong fingertips and 17 touch sensors.

Full specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
30 N whole hand; 30 N thumb, 28 N fingers at the fingertip
Load
15 kg
Speed
Closes the palm in 0.8 s
Touch
17 tactile sensors, 0 to 30 N
Repeatability
±0.20 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 790 g
Drive
Linear servos
Control
Force-threshold control
Interface
RS-485 or CAN, plus Modbus TCP
Software
Supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Five-finger work that needs both real fingertip force and touch.
Keep in mind
Heavier than the Revo 2 and Linker O6, which uses up more arm payload. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$10,680 Get a quote
H2 Dex5-1 Five-finger Dexterous Hand (With RGB)

H2 Dex5-1 Five-finger Dexterous Hand (With RGB)

H2 Dedicated Dex5-1 Five-finger Dexterous Hand (With RGB)

For the Unitree H2. Dexterity and in-hand manipulation research on the H2.

What it is
Research-grade five-finger hand

A full five-finger research hand where each finger can move and spread on its own. It grips objects as small as 10 mm.

Full specs and what they mean
Type
Research-grade five-finger hand
Motion
16 DoF per hand. 16 active motors: thumb 4, each finger 3. Four more knuckle joints are coupled to them, so Unitree counts 20 DoF in total.
Force
10 N at the fingertip
Load
3.5 kg palm down, 4.5 kg palm sideways, on a 5 cm sphere
Smallest grip
10 mm
Touch
No touch sensors. The joints sense their own torque.
Repeatability
±1 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
1.1 kg
Size
217 × 128 × 72 mm
Drive
12 micro force-control joints plus 4 geared joints
Control
Joint position, velocity, torque, stiffness and damping
Interface
USB 2.0, 1000 Hz feedback
Software
URDF model available
Best for
Dexterity and in-hand manipulation research on the H2.
Keep in mind
H2 only. No touch sensors on this version.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$16,450 Get a quote
H2 Dex5-1P Five-finger Dexterous Hand (With RGB)

H2 Dex5-1P Five-finger Dexterous Hand (With RGB)

H2 Dedicated Dex5-1P Five-finger Dexterous Hand (With RGB)

For the Unitree H2. Dexterity research that also needs detailed touch data.

What it is
Research-grade five-finger hand with touch sensing

The Dex5-1 with 94 pressure sensors across the palm, finger pads, fingertips and finger bases.

Full specs and what they mean
Type
Research-grade five-finger hand with touch sensing
Motion
16 DoF per hand. 16 active motors: thumb 4, each finger 3. Four more knuckle joints are coupled to them, so Unitree counts 20 DoF in total.
Force
10 N at the fingertip
Load
3.5 kg palm down, 4.5 kg palm sideways, on a 5 cm sphere
Smallest grip
10 mm
Touch
94 pressure sensors in 12 arrays, sensing 10 g to 2.5 kg
Repeatability
±1 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
1.1 kg
Size
217 × 128 × 72 mm
Drive
12 micro force-control joints plus 4 geared joints
Control
Joint position, velocity, torque, stiffness and damping
Interface
USB 2.0, 1000 Hz feedback
Software
URDF model available
Best for
Dexterity research that also needs detailed touch data.
Keep in mind
H2 only.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$18,950 Get a quote
G1 Wuji Hand2 (No Tactile) (With RGB)

G1 Wuji Hand2 (No Tactile) (With RGB)

Wuji Hand2 (No Tactile) (With RGB)

For the Unitree G1. Dexterous research and learning skilled finger motion on a G1 or H2.

What it is
Research-grade direct-drive five-finger hand

Twenty motors with no gearbox slowing them down, so fingers are quick and can be pushed back by hand, close to how a person moves.

Full specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
20 DoF per hand. 20 active motors, one for each joint it can move.
Force
12 N or more at the fingertip
Smallest grip
0 mm
Speed
4 or more open and close cycles per second
Touch
None on this version
Precision
Joint backlash under 1°
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 800 g
Size
About 180 × 80 × 40 mm
Drive
Direct-drive rotary joints
Control
MIT hybrid force and position
Interface
Ethernet, 1000 Hz on all 20 axes
Software
Python and C SDK, ROS 2, MuJoCo and Isaac
Best for
Dexterous research and learning skilled finger motion on a G1 or H2.
Keep in mind
Overkill for simple grasping. Wuji labels its published figures as Beta, so confirm any figure you depend on with us.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$19,500 Get a quote
H2 Wuji Dextrous hands 2 (No Tactile) (With RGB)

H2 Wuji Dextrous hands 2 (No Tactile) (With RGB)

Wuji Dextrous hands 2 (No Tactile) (With RGB)

For the Unitree H2. Dexterous research and learning skilled finger motion on a G1 or H2.

What it is
Research-grade direct-drive five-finger hand

Twenty motors with no gearbox slowing them down, so fingers are quick and can be pushed back by hand, close to how a person moves.

Full specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
20 DoF per hand. 20 active motors, one for each joint it can move.
Force
12 N or more at the fingertip
Smallest grip
0 mm
Speed
4 or more open and close cycles per second
Touch
None on this version
Precision
Joint backlash under 1°
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 800 g
Size
About 180 × 80 × 40 mm
Drive
Direct-drive rotary joints
Control
MIT hybrid force and position
Interface
Ethernet, 1000 Hz on all 20 axes
Software
Python and C SDK, ROS 2, MuJoCo and Isaac
Best for
Dexterous research and learning skilled finger motion on a G1 or H2.
Keep in mind
Overkill for simple grasping. Wuji labels its published figures as Beta, so confirm any figure you depend on with us.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$19,700 Get a quote
H2 EDU-BrainCo Revo 3 U21 (NO Tactile) (With RGB)

H2 EDU-BrainCo Revo 3 U21 (NO Tactile) (With RGB)

H2 EDU-BrainCo Revo 3 U21 (NO Tactile) (With RGB)

For the Unitree H2. High-dexterity work on the adult-size H2 that also needs real strength.

What it is
Research-grade direct-drive five-finger hand

A large, strong, fully articulated hand. Twenty-one motors with no gearbox slowing them, and all fingers can touch the palm.

Full specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
High-dexterity work on the adult-size H2 that also needs real strength.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$22,300 Get a quote
H2 EDU PLUS BrainCo Revo 3 U21 (No Tactile) (with Sensing SHF3L)

H2 EDU PLUS BrainCo Revo 3 U21 (No Tactile) (with Sensing SHF3L)

H2 EDU PLUS BrainCo Revo 3 U21 (No Tactile) (with Sensing SHF3L)

For the Unitree H2. High-dexterity work on the adult-size H2 that also needs real strength.

What it is
Research-grade direct-drive five-finger hand

A large, strong, fully articulated hand. Twenty-one motors with no gearbox slowing them, and all fingers can touch the palm.

Full specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
None
Repeatability
0.1° at the joint
Wrist camera
Wide 196° Sensing SHF3L wrist camera
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
High-dexterity work on the adult-size H2 that also needs real strength.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • H2 Plus version: you must also choose the H2 NVIDIA Jetson Thor computing board.
$22,300 Get a quote
H2 EDU-BrainCo Revo 3 U21T Tactile (With RGB)

H2 EDU-BrainCo Revo 3 U21T Tactile (With RGB)

H2 EDU-BrainCo Revo 3 U21T Tactile Version (With RGB)

For the Unitree H2. Training AI on rich touch data on the H2.

What it is
Research-grade hand with full-palm touch sensing

The Revo 3 with touch sensing across the whole palm and fingers, sensitive to a hundredth of a newton.

Full specs and what they mean
Type
Research-grade hand with full-palm touch sensing
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
Full-palm array of 451 points, 0.01 N resolution
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Training AI on rich touch data on the H2.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$28,800 Get a quote
H2 EDU PLUS BrainCo Revo 3 U21T (With Tactile) (with Sensing SHF3L)

H2 EDU PLUS BrainCo Revo 3 U21T (With Tactile) (with Sensing SHF3L)

H2 EDU PLUS BrainCo Revo 3 U21T (With Tactile) (with Sensing SHF3L)

For the Unitree H2. Training AI on rich touch data on the H2.

What it is
Research-grade hand with full-palm touch sensing

The Revo 3 with touch sensing across the whole palm and fingers, sensitive to a hundredth of a newton.

Full specs and what they mean
Type
Research-grade hand with full-palm touch sensing
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
Full-palm array of 451 points, 0.01 N resolution
Repeatability
0.1° at the joint
Wrist camera
Wide 196° Sensing SHF3L wrist camera
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Training AI on rich touch data on the H2.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • H2 Plus version: you must also choose the H2 NVIDIA Jetson Thor computing board.
$28,800 Get a quote
H2 EDU-BrainCo Revo 3 U21V (with Vision-Tactile) (with RGB Camera)

H2 EDU-BrainCo Revo 3 U21V (with Vision-Tactile) (with RGB Camera)

H2 EDU-BrainCo Revo 3 U21V (with Vision-Tactile) (with RGB Camera)

For the Unitree H2. Leading-edge research into touch and fine manipulation.

What it is
Research-grade hand with vision-based fingertips

Tiny cameras inside the fingertips watch a soft skin deform, so the hand can sense texture and very slight contact.

Full specs and what they mean
Type
Research-grade hand with vision-based fingertips
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Touch
Full-palm array plus vision-based fingertips, detecting down to 130 µm of deformation
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Leading-edge research into touch and fine manipulation.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
$45,700 Get a quote
H2 EDU PLUS BrainCo Revo 3 U21V (with Visual-Tactile) (with Sensing SHF3L)

H2 EDU PLUS BrainCo Revo 3 U21V (with Visual-Tactile) (with Sensing SHF3L)

H2 EDU PLUS BrainCo Revo 3 U21V (with Visual-Tactile) (with Sensing SHF3L)

For the Unitree H2. Leading-edge research into touch and fine manipulation.

What it is
Research-grade hand with vision-based fingertips

Tiny cameras inside the fingertips watch a soft skin deform, so the hand can sense texture and very slight contact.

Full specs and what they mean
Type
Research-grade hand with vision-based fingertips
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Touch
Full-palm array plus vision-based fingertips, detecting down to 130 µm of deformation
Repeatability
0.1° at the joint
Wrist camera
Wide 196° Sensing SHF3L wrist camera
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Leading-edge research into touch and fine manipulation.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • H2 Plus version: you must also choose the H2 NVIDIA Jetson Thor computing board.
$45,700 Get a quote
H2 EDU PLUS SharpaWave Dextrous Hands (with Sensing SHF3L)

H2 EDU PLUS SharpaWave Dextrous Hands (with Sensing SHF3L)

H2 EDU PLUS SharpaWave Dextrous Hands (with Sensing SHF3L)

For the Unitree H2. The most demanding dexterity and tactile research on the H2.

What it is
Research-grade hand with vision-based fingertips

The strongest hand in the range, with the most motors and camera-based touch in every fingertip.

Full specs and what they mean
Type
Research-grade hand with vision-based fingertips
Motion
22 DoF per hand. 22 active motors per hand.
Force
150 N whole hand, 20 N at the fingertip
Load
At least 30 kg
Speed
Above 4 Hz
Touch
Vision-based fingertips at 240 × 240 resolution, 0 to 30 N
Repeatability
±1 mm at the fingertip
Wrist camera
Wide 196° Sensing SHF3L wrist camera
Weight
1.3 kg
Size
208 × 90 × 50 mm
Interface
Gigabit Ethernet
Software
C++ and Python SDK, ROS 2, MuJoCo and Isaac Sim
Best for
The most demanding dexterity and tactile research on the H2.
Keep in mind
H2 Plus only, and needs the Jetson Thor board. By far the most expensive hand here.
Compare every hand, with terms explained →
  • Price is for one hand. A humanoid normally takes two: specify left or right when ordering.
  • H2 Plus version: you must also choose the H2 NVIDIA Jetson Thor computing board.
$78,200 Get a quote
ConfigurationFitsFingersDoF per handTouchRepeatabilityPrice
G1 Dex1-1 Gripper Standard G1 2 1 None Not published $380
G1-D Dex1-1 Gripper Standard G1-D 2 1 None Not published $380
R1 Dex1-1 Gripper Standard R1 2 1 None Not published $380
G1 Dex1-1 Gripper Advanced G1 2 1 None Not published $580
G1-D Dex1-1 Gripper Advanced G1-D 2 1 None Not published $580
H2- Dex1-1 Gripper Advanced H2 2 1 None Not published $580
R1- Dex1-1 Gripper Advanced R1 2 1 None Not published $580
G1-D Dex1-1 Gripper Ultimate G1-D 2 1 None Not published $1,080
G1 DEX 2/5 G1 5 2 None Not published $1,490
R1 Tendon Cable Dexterous Hand R1 5 2 None Not published $1,490
R1 LinkerBot Linker Hand O6 (Non-Tactile) (with RGB Camera) R1 5 6 None Under ±0.20 mm $1,590
R1 LinkerBot Linker Hand O6 (Tactile) (includes RGB camera) R1 5 6 Yes Under ±0.20 mm $1,790
G1 BrainCo Bionic Dexterous Hand Revo 2 Basic (With RGB) G1 5 6 None 0.1° at the joint $6,680
G1-D BrainCo Bionic Dexterous Hand Revo 2 Basic (Includes RGB Camera) G1-D 5 6 None 0.1° at the joint $6,680
H2 BrainCo Bionic Dexterous Hand Revo 2 Basic (With RGB) H2 5 6 None 0.1° at the joint $6,680
R1 BrainCo Bionic Dexterous Hand Revo 2 Basic (Includes RGB Camera) R1 5 6 None 0.1° at the joint $6,680
G1 Dex3-1 Force-controlled Three-finger Dexterous Hand (With RGB) G1 3 7 None ±2 mm at the fingertip $7,680
G1-D Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Includes RGB Camera) G1-D 3 7 None ±2 mm at the fingertip $7,680
H2- Dex3-1 Force-Controlled Three-Finger Dexterous Hand H2 3 7 None ±2 mm at the fingertip $7,680
R1 Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Includes RGB Camera) R1 3 7 None ±2 mm at the fingertip $7,680
G1 Dex3-1 Force-controlled Three-finger Dexterous Hand (Tactile ) (With RGB) G1 3 7 Yes ±2 mm at the fingertip $8,680
G1 BrainCo Bionic Dexterous Hand Revo 2 Tactile (With RGB) G1 5 6 Yes 0.1° at the joint $8,680
G1 Inspire DFQ Series Dexterous Hand (With RGB) G1 5 6 None ±0.20 mm $8,680
G1-D Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile) G1-D 3 7 Yes ±2 mm at the fingertip $8,680
G1-D BrainCo Bionic Dexterous Hand Revo 2 Tactile (Includes RGB Camera) G1-D 5 6 Yes 0.1° at the joint $8,680
H2- Dex3-1 Force-Controlled Three-Finger Dexterous Hand (tactile) H2 3 7 Yes ±2 mm at the fingertip $8,680
H2 BrainCo Bionic Dexterous Hand Revo 2 Tactile (With RGB) H2 5 6 Yes 0.1° at the joint $8,680
H2 Inspire DFQ Series Dexterous Hand (With RGB) H2 5 6 None ±0.20 mm $8,680
R1 Dex3-1 Force-Controlled Three-Finger Dexterous Hand (Tactile) R1 3 7 Yes ±2 mm at the fingertip $8,680
R1 BrainCo Bionic Dexterous Hand Revo 2 Tactile (Includes RGB Camera) R1 5 6 Yes 0.1° at the joint $8,680
H2 Inspire E2 Series Dexterous Hand (With RGB) H2 5 6 Yes ±0.20 mm at the fingertip $10,530
G1 Inspire E2 Series Dexterous Hand (With RGB) G1 5 6 Yes ±0.20 mm at the fingertip $10,680
H2 Dex5-1 Five-finger Dexterous Hand (With RGB) H2 5 16 None ±1 mm at the fingertip $16,450
H2 Dex5-1P Five-finger Dexterous Hand (With RGB) H2 5 16 Yes ±1 mm at the fingertip $18,950
G1 Wuji Hand2 (No Tactile) (With RGB) G1 5 20 None Not published $19,500
H2 Wuji Dextrous hands 2 (No Tactile) (With RGB) H2 5 20 None Not published $19,700
H2 EDU-BrainCo Revo 3 U21 (NO Tactile) (With RGB) H2 5 21 None 0.1° at the joint $22,300
H2 EDU PLUS BrainCo Revo 3 U21 (No Tactile) (with Sensing SHF3L) H2 5 21 None 0.1° at the joint $22,300
H2 EDU-BrainCo Revo 3 U21T Tactile (With RGB) H2 5 21 Full palm 0.1° at the joint $28,800
H2 EDU PLUS BrainCo Revo 3 U21T (With Tactile) (with Sensing SHF3L) H2 5 21 Full palm 0.1° at the joint $28,800
H2 EDU-BrainCo Revo 3 U21V (with Vision-Tactile) (with RGB Camera) H2 5 21 Vision-based 0.1° at the joint $45,700
H2 EDU PLUS BrainCo Revo 3 U21V (with Visual-Tactile) (with Sensing SHF3L) H2 5 21 Vision-based 0.1° at the joint $45,700
H2 EDU PLUS SharpaWave Dextrous Hands (with Sensing SHF3L) H2 5 22 Vision-based ±1 mm at the fingertip $78,200

Prices are US MSRP and exclude tax, duty and freight. Configurations, lead times and specifications are subject to change by the manufacturer.

Five-finger, with touch

Dex5-1: grasping and tactile sensing

Close-up grasping, finger articulation and how the hand responds to contact — the top of the range above.

Footage courtesy of Unitree Robotics.

Talk to a specialist

Get pricing & a free demo of the Unitree Humanoid Hands & Grippers.

Same-day response. We handle delivery, on-site setup, staff training, and ongoing service nationwide.

Motion, close up

How the simpler end effectors move

The Dex1-1 gripper and the Dex2/5 tendon-driven hand, in isolation.

Gripper Motion Animation
Finger Movement Animation

Footage courtesy of Unitree Robotics.

Related robots

More humanoid robots robots

Unitree R1-A5 Dual-Arm Humanoid Robot
Unitree Humanoid

Unitree R1-A5 Dual-Arm Humanoid Robot

The Unitree R1-A5 is a fixed-base dual-arm humanoid: 13 degrees of freedom (5 per arm, 1 waist, 2 head), roughly 11 kg, with a 420 mm arm reach and about 2 kg payload per arm. The R1-A5-D variant adds a wheeled chassis a

From $7,200 purchase
Unitree G1 Humanoid Robot
Unitree Humanoid

Unitree G1 Humanoid Robot

The Unitree G1 is a compact bipedal humanoid built for research, education and content work. It stands about 1.27 m, weighs roughly 35 kg with its quick-release battery, and ships with 23 degrees of freedom — rising to 4

From $17,990 purchase
Request a walkthrough