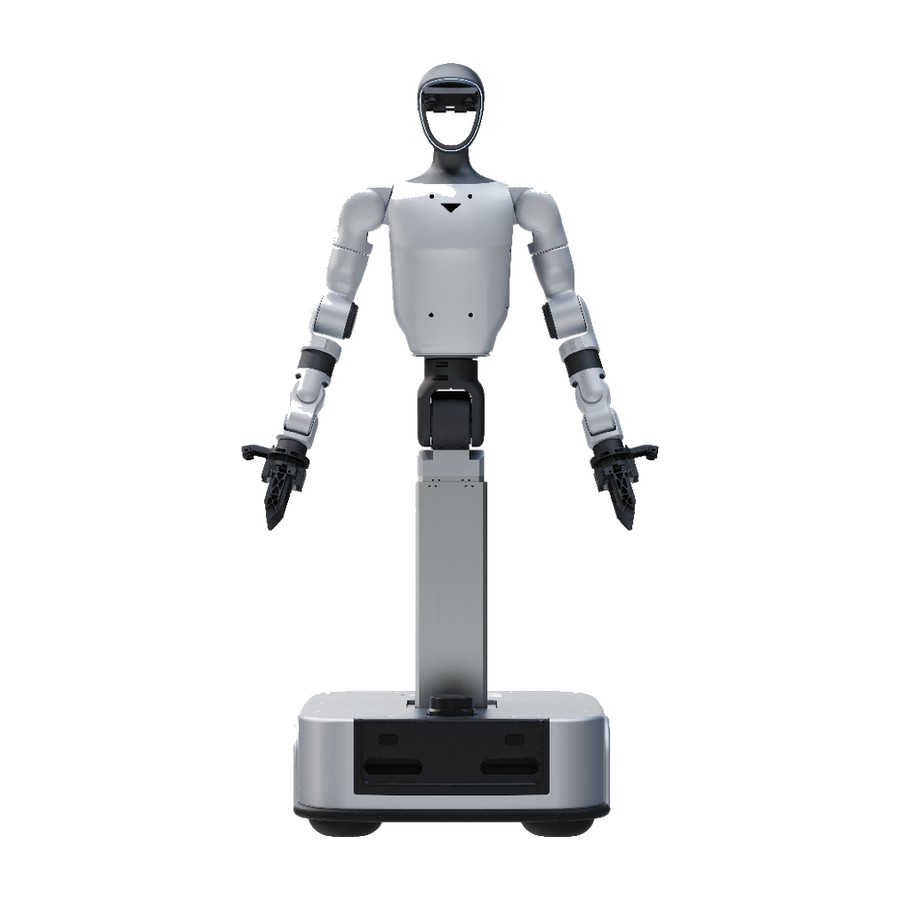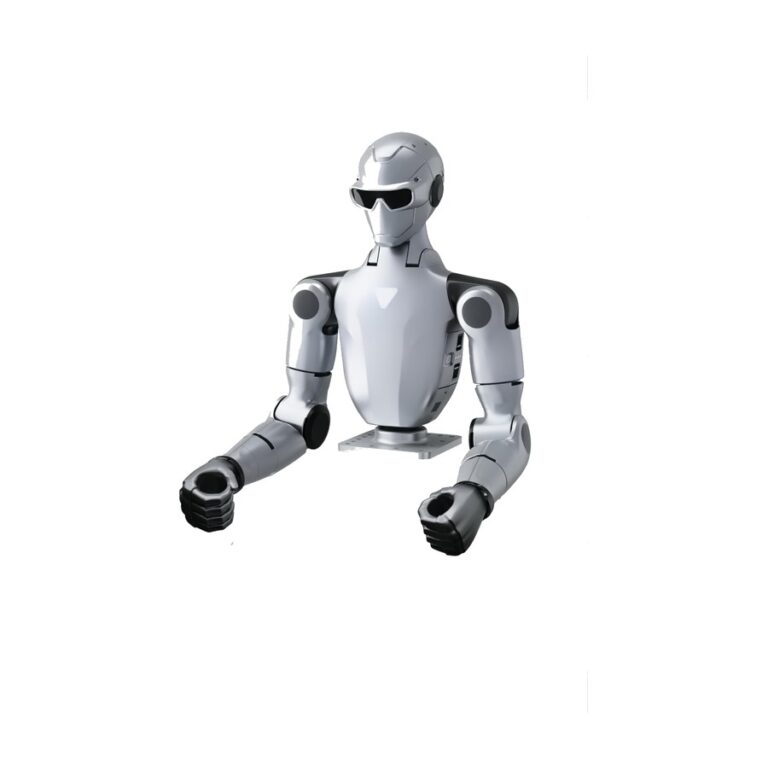
G1-D Standard A Humanoid Robot
G1-D Standard A
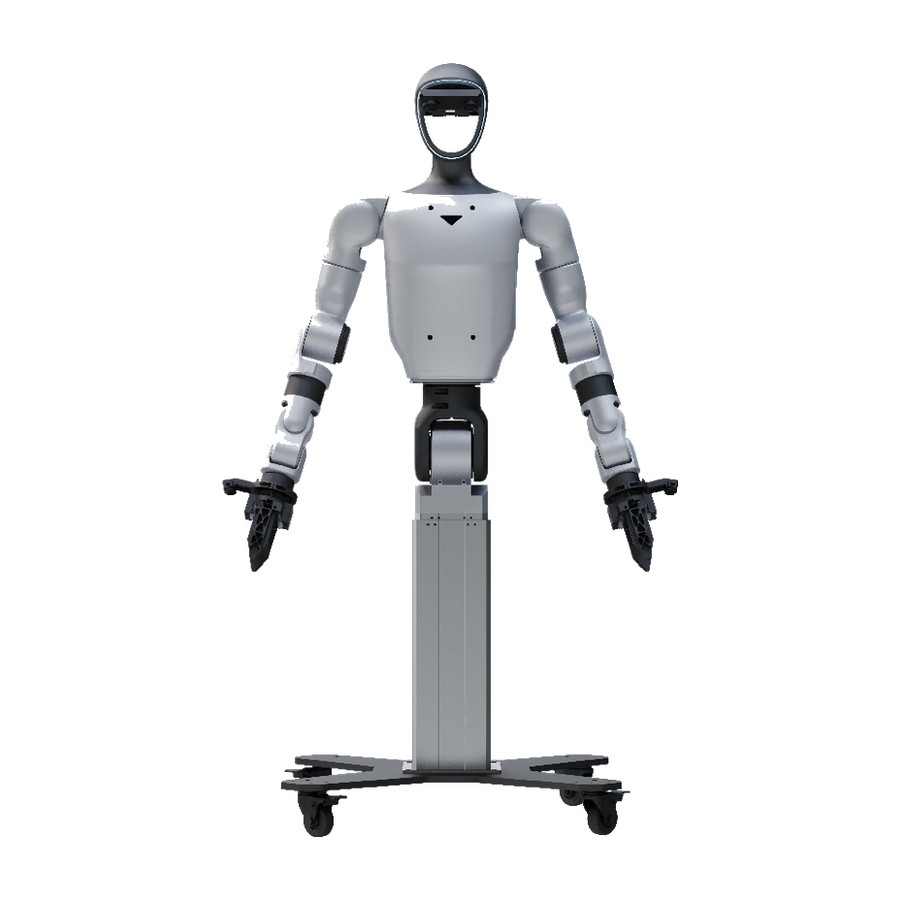
Programmable G1-D with a pair of Dex1-1 Advanced grippers, with wrist cameras.
End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras
The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.
Full hand specs and what they mean
- Type
- Two-finger gripper with wrist camera
- Motion
- 1 DoF per hand. One motor opens and closes both fingers.
- Force
- Adjustable 5 to 120 N
- Load
- 20 kg form-fit (horizontal), 5 kg by friction (vertical)
- Grip range
- 90 mm opening
- Speed
- Closes fully in 0.24 s
- Touch
- None
- Precision
- 0.1 mm position resolution at the fingertip
- Wrist camera
- RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
- Weight
- 550 g
- Size
- 143 × 78 × 67 mm
- Drive
- Motor-driven parallel gripper
- Control
- Angle, velocity, torque, stiffness and damping
- Interface
- High-speed RS-485, 1000 Hz (RS-485 to USB board included)
- Software
- Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
- Teleoperation
- Supported by Unitree's xr_teleoperate
- Best for
- Vision-guided pick and place and low-cost data collection.
- Keep in mind
- Cannot use tools made for human fingers.
Control and programming
- Programming
- Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
- Remote
- Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
- App
- Unitree Explore (iOS; Android by download from Unitree)
- Warranty
- 12 months
More on control
- Your code runs on
- Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
- Teleoperation
- Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
- Voice
- 4-microphone array and 5 W speaker
- App features
- Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
- Updates
- Over the air
- Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
- Standard: on a push-pull base with no electric drive. Runs on battery or a power cable.
- 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
- Head stereo camera and two wrist cameras.
$38,800
Get a quote