19 Years · America's Largest Robotics Integrator
Home/ Store/ Humanoid/ Unitree H2 Humanoid Robot

Unitree H2 Humanoid Robot

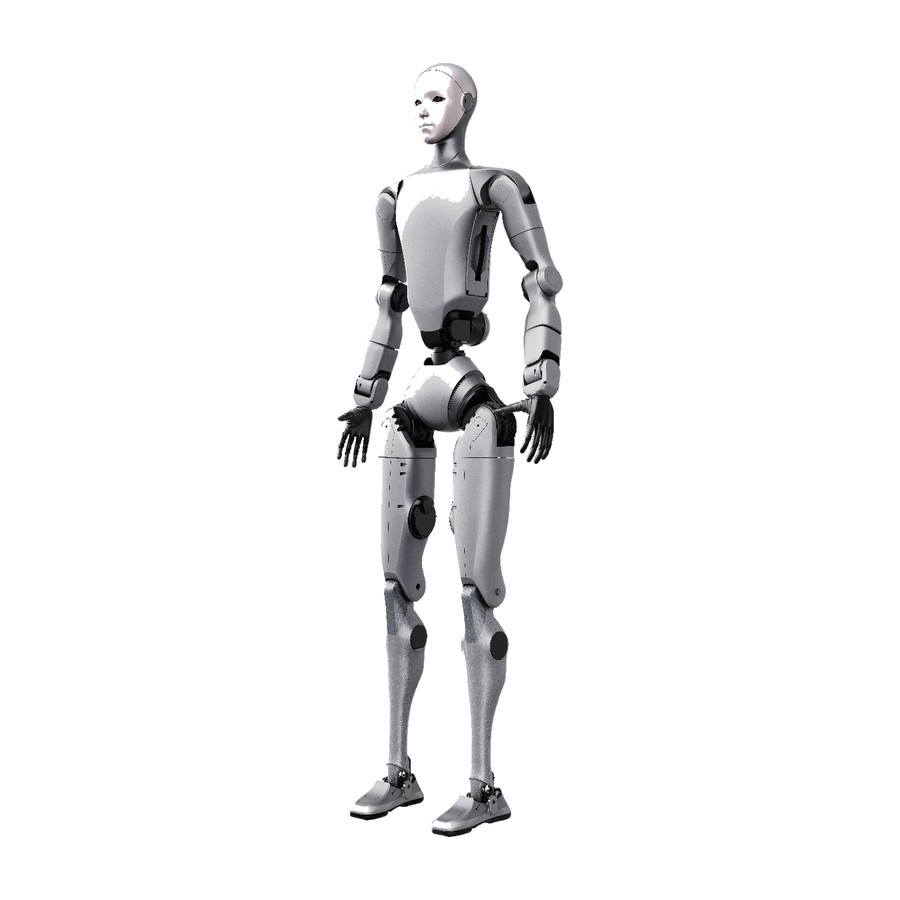
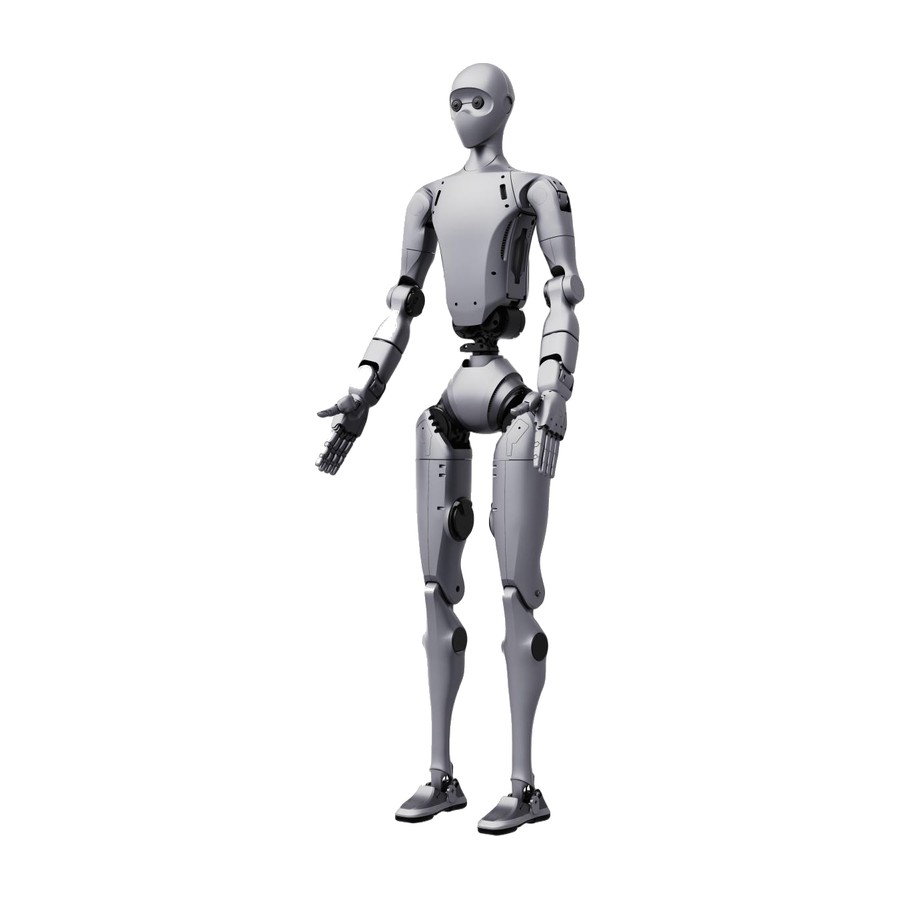
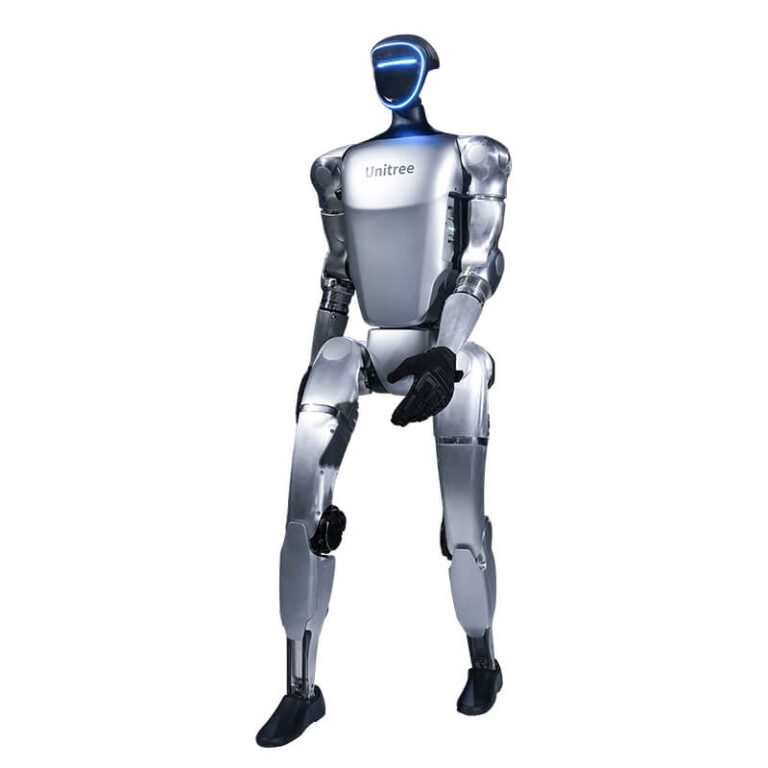
The Unitree H2 is a full-size humanoid: 1.82 m tall, about 70 kg with battery, and 31 degrees of freedom across 6 per leg, 7 per arm, 3 at the waist and 2 in the head. Peak arm payload is around 15 kg and battery life is

Configurations from
$39,900 – $240,000
31 configurations · compare them

Purchase · Lease

Unitree H2 Humanoid Robot — Unitree
Manufacturer
Unitree
Capability
Humanoid Robots
Support
US sales, setup & service
Overview

What is the Unitree H2 Humanoid Robot?

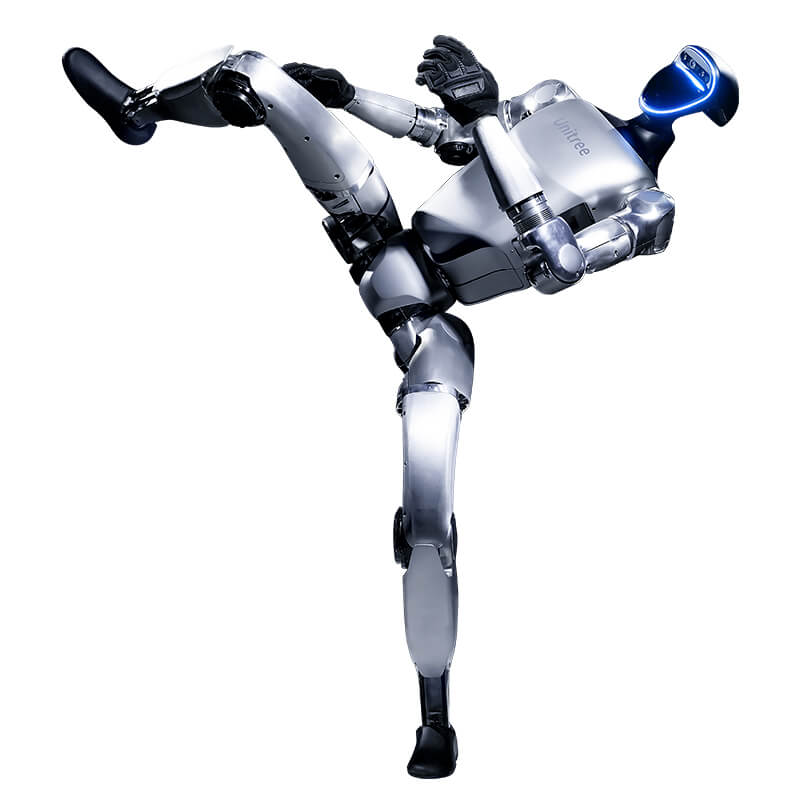
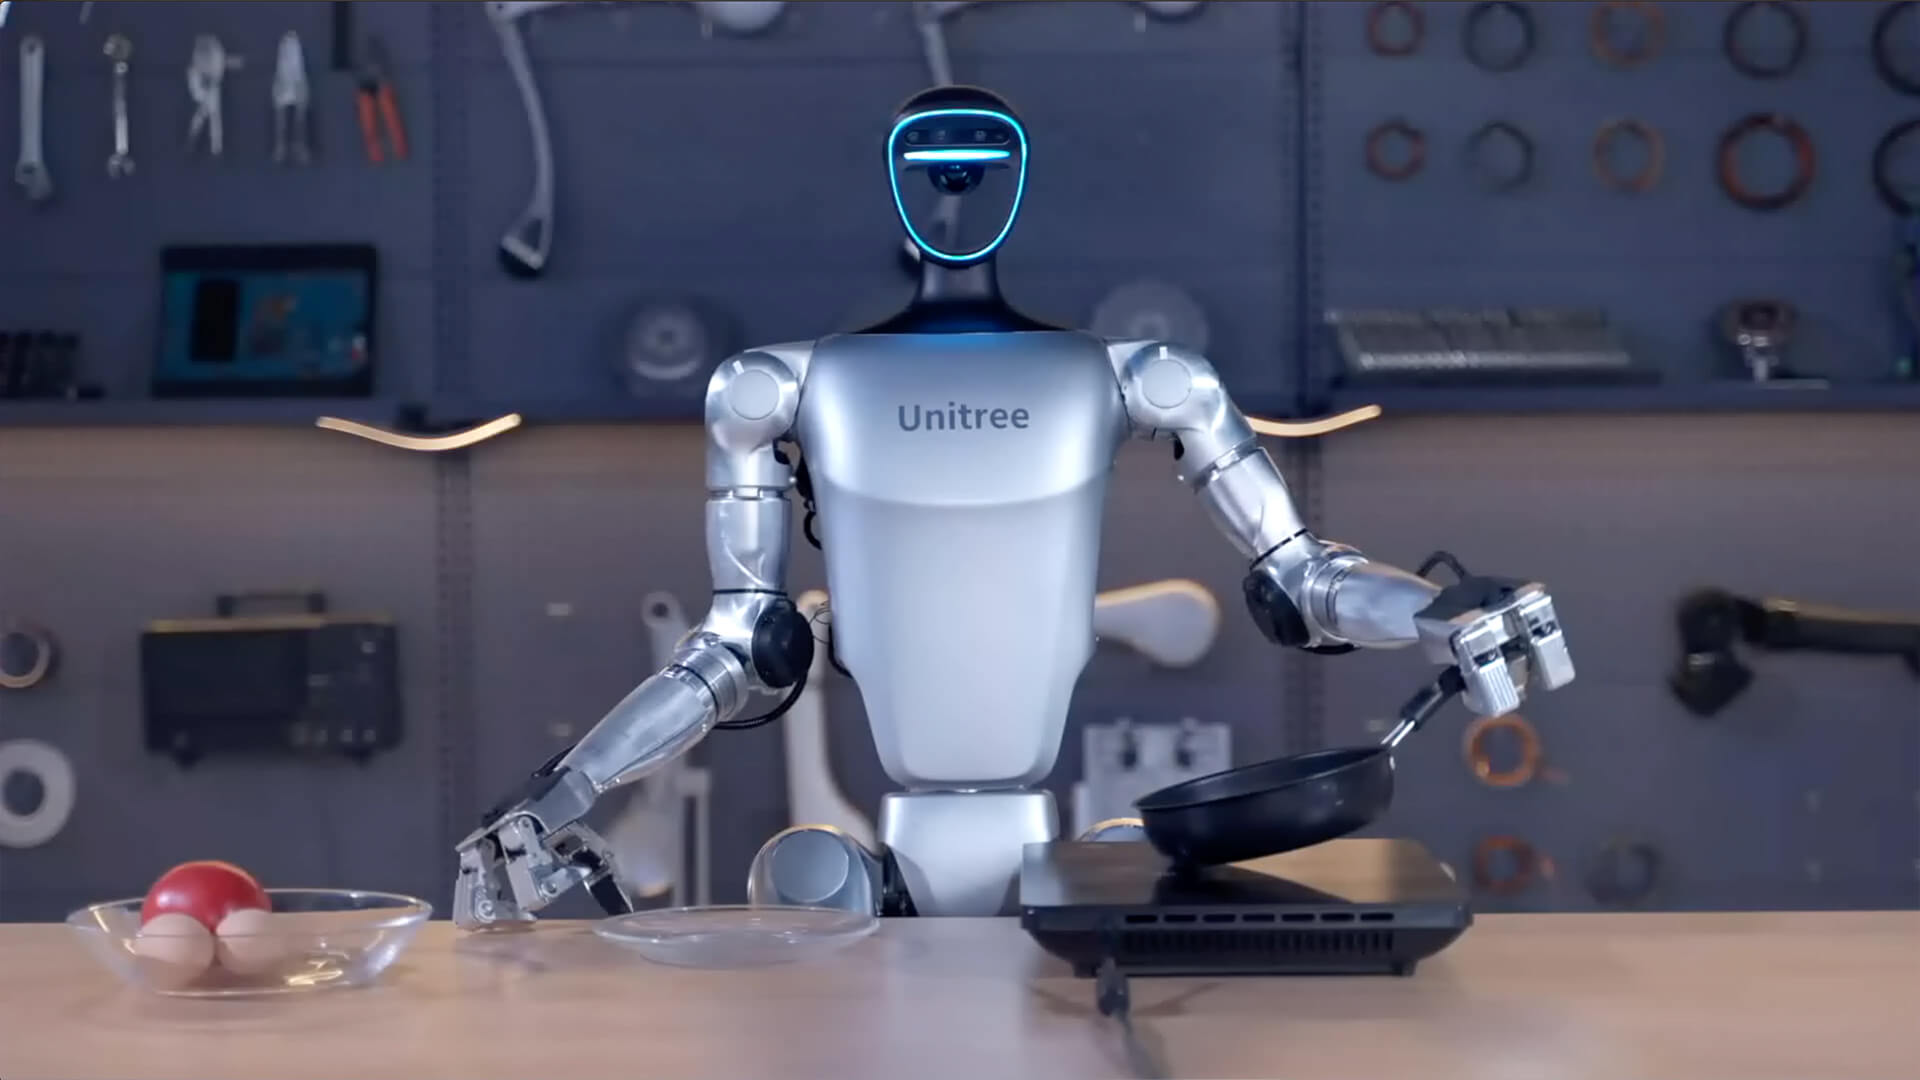
The Unitree H2 is a full-size humanoid: 1.82 m tall, about 70 kg with battery, and 31 degrees of freedom across 6 per leg, 7 per arm, 3 at the waist and 2 in the head. Peak arm payload is around 15 kg and battery life is roughly three hours.

The H2 range runs from the standalone H2 through EDU and PLUS development platforms, then splits by dexterous hand — from simple grippers up to vision-tactile five-finger hands.

RobotLAB supplies the full Unitree humanoid range in the United States, with 31 H2 configurations currently listed, from $39,900 to $240,000. Every configuration below is quoted, supported and serviced from the US.

Specifications

Key specs

Height, Width, Depth (Standing)1820 x 456 x 218 mm
Weight with BatteryApprox. 70 kg
Total Degrees of Freedom (Joint Motors)31
Degrees of Freedom per Leg6; Degrees of Freedom per Arm: 7; Degrees of Freedom at the Waist: 3; Degrees of Freedom at the Head: 2
Joint Output BearingsIndustrial-grade cross-roller bearings (high precision, high load capacity)
Joint MotorsLow-inertia, high-speed, inner-rotor permanent magnet synchronous motors (better response speed and heat dissipation)
Maximum Peak Torque at Arm Joints120 N·m
Maximum Peak Torque at Leg Joints360 N·m
Maximum Arm LoadPeak: approx. 15 kg; Rated: approx. 7 kg
Calf + Thigh Length1045 mm
Forearm + Upper Arm Length690 mm
MaterialsAerospace-grade aluminum + titanium alloy + high-strength engineering plastics
Cooling SystemAir-cooled
Power SupplyHigh-quality lithium-ion battery with low internal resistance
Battery Capacity15 Ah (0.972 kWh)
Battery VoltageMaximum voltage 75.6 V
PC1Intel Core i5 (Platform Functions)
PC2Intel Core i7 (User Development)
PC3The PC3 slot is empty in this version; an Nvidia Jetson Thor *1 can be added as a paid option
PC4The PC4 slot is empty in this version; an Intel Core i7 *1 or Nvidia Jetson Orin NX *1 can be added as a paid option
Perception SensorsWide-field-of-view humanoid stereo cameras
Voice InteractionArray microphones and high-power speakers for voice interaction
Sense of scale

H2 walking beside a person

At 1.82 m and about 70 kg the H2 is full adult size — worth seeing next to a human before you read the rest of the spec.

Footage courtesy of Unitree Robotics.

How it works

Unitree H2 Humanoid Robot in detail

Choosing a configuration

The table below is the honest version of the spec sheet: it shows only what actually differs between configurations, so you can see what the extra money buys. Shared platform specifications are listed separately — they apply to every unit in the range.

Typical buyers are advanced research groups, integrators and full-stack humanoid developers. If you are not sure which build fits your work, ask us: we configure these for US customers every week and will tell you when a cheaper configuration does the job.

See the rest of the range on our humanoid robots page, or browse everything we carry from Unitree.

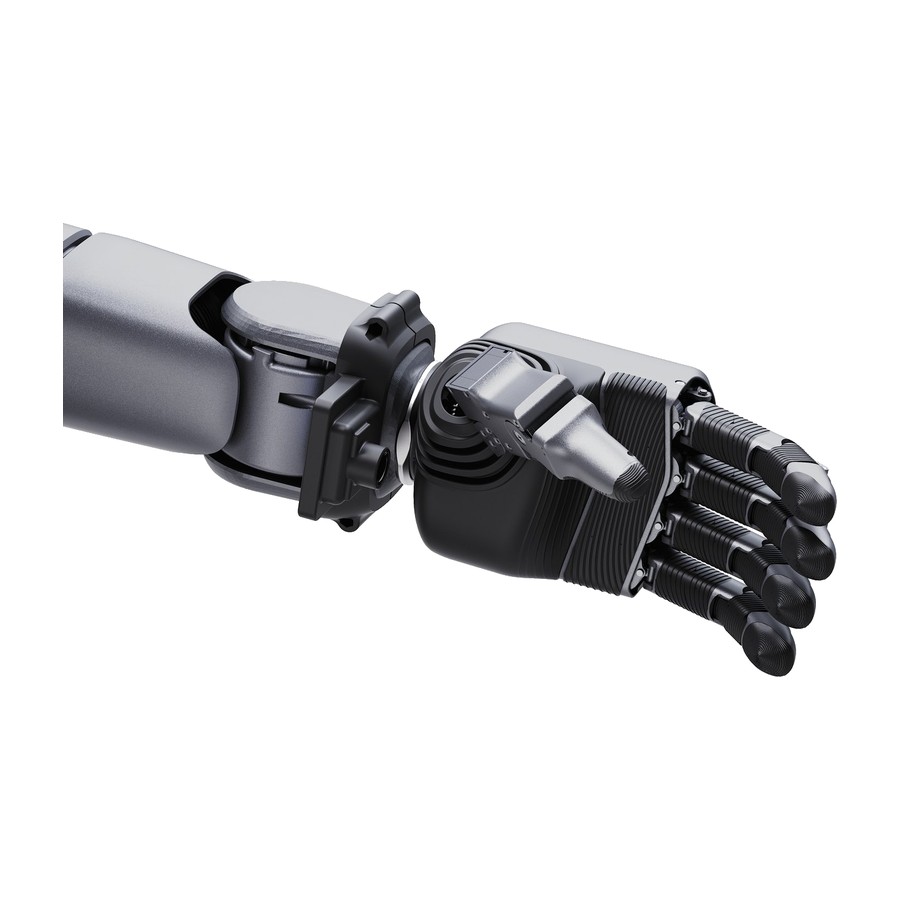
Most configurations differ only by the hand fitted. If you want to compare end effectors on their own, see Unitree humanoid hands and grippers.

Compare

How the Unitree H2 Humanoid Robot compares

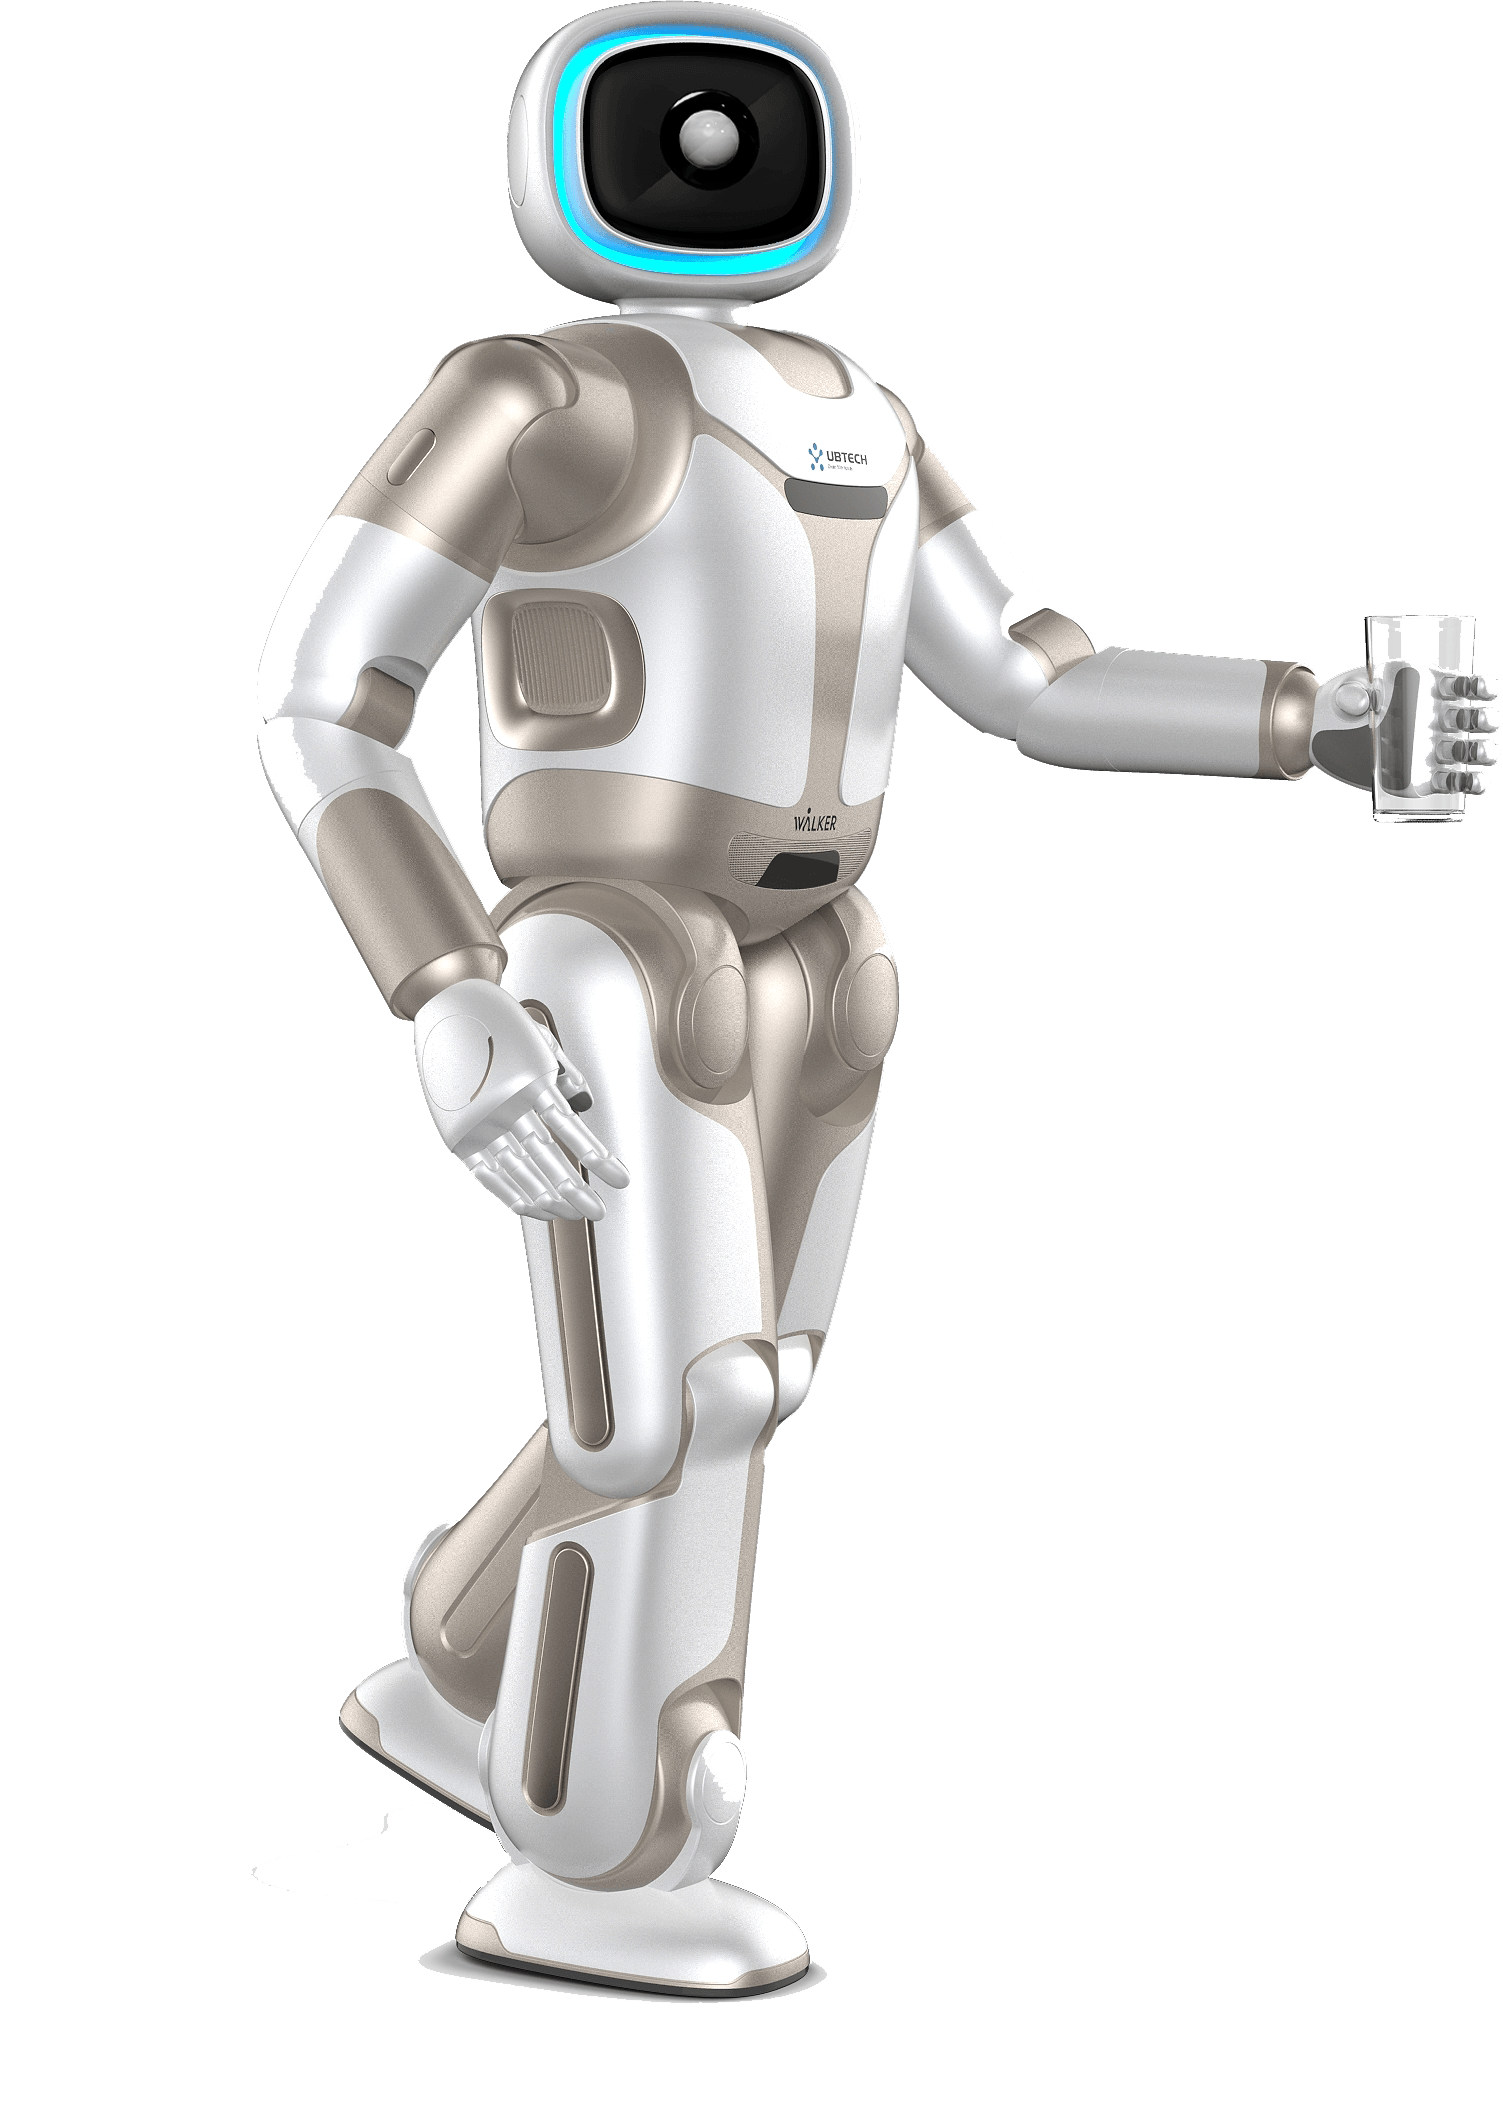
SpecificationUnitree H2 EDUUnitree G1Unitree G1Walker Humanoid Service Robot For ResearchWalker Humanoid Service Robot For Research
Best forFull-size humanoid R&D and advanced educationPortable, lower-cost humanoid developmentHigh-end research-grade full humanoid
Purchase price$68,900$23,700$250,000
Height~180 cm~1.27 m~130-145 cm (Walker X)
Weight~70 kg~35 kg~63-77 kg (Walker X)
Degrees of freedom3123 (base; up to 43 EDU)41 (Walker X)
Max joint torque360 N·m (legs)Contact for detailsContact for details
Payload~7 kg per arm continuousContact for details10 kg / 3 kg per hand (Walker X)
Walking speedUnder 2 m/sUp to 2 m/s3 km/h (10 km/h sprint, Walker X)
Open developmentYes (EDU)Yes (EDU)Yes (research)
BrandUnitreeUnitreeUBTECH
Humanoid configurator

Feeling overwhelmed by 64 humanoid configurations?

Let our AI recommend the right platform for you. Tell us what the robot is for — or the exact specs you need — and get a shortlist of three Unitree configurations, with every option explained in plain language. No commitment.

  • A guided path for business users, a technical path for engineers
  • Compute, hands, sensing and joints explained as you go
  • Live list prices and a one-click quote request
Open the humanoid configurator → About two minutes. No commitment.
Unitree G1 humanoid robot
Configurations

Which Unitree H2 Humanoid Robot is right for you?

Every configuration below is the same core platform. They differ in compute, degrees of freedom and end effectors — from $39,900 to $240,000.

H2

H2

H2

Remote-operated H2 with no hands fitted. Not programmable.

End effector
None fitted

Unitree lists hands as an option on its programmable editions, so ask us before planning to add them here.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Not offered. Unitree lists no secondary development on this edition, so it runs built-in behaviors.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
8 months
More on control
Your code runs on
No user computer. Intel i5 handles platform functions only.
Teleoperation
Not available: Unitree's teleoperation software runs on a development computer this edition does not have.
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions. No user computer on this edition.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$39,900 Get a quote
H2 EDU Standard

H2 EDU Standard

H2 EDU Standard

Programmable H2 with no hands fitted.

End effector
None fitted

Choose any compatible hand as an option, or pick an edition that has them fitted.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$66,800 Get a quote
H2 Plus Standard

H2 Plus Standard

H2 Plus Standard

Programmable H2 with no hands fitted.

End effector
None fitted

Choose any compatible hand as an option, or pick an edition that has them fitted.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$66,800 Get a quote
H2 EDU SMART A

H2 EDU SMART A

H2 EDU SMART A

Programmable H2 with a pair of Dex1-1 Advanced grippers, with wrist cameras.

End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full hand specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$67,960 Get a quote
H2 EDU SMART F

H2 EDU SMART F

H2 EDU SMART F

Programmable H2 with a pair of BrainCo Revo 2 five-finger hands.

End effector
Pair of BrainCo Revo 2 five-finger hands

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$80,160 Get a quote
H2 EDU SMART B

H2 EDU SMART B

H2 EDU SMART B

Programmable H2 with a pair of Dex3-1 three-finger hands.

End effector
Pair of Dex3-1 three-finger hands

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full hand specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$82,160 Get a quote
H2 Plus SMART

H2 Plus SMART

H2 Plus SMART

Programmable H2 with no hands fitted.

End effector
None fitted

Choose any compatible hand as an option, or pick an edition that has them fitted.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$83,600 Get a quote
H2 EDU SMART H

H2 EDU SMART H

H2 EDU SMART H

Programmable H2 with a pair of Inspire DFQ five-finger hands.

End effector
Pair of Inspire DFQ five-finger hands

A fast, light-duty five-finger hand. Quick fingers, but low fingertip force compared with the others here.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
6 N thumb, 4 N fingers
Speed
Fingers flex at 570°/s, thumb at 150°/s
Touch
None
Repeatability
±0.20 mm
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Best for
Fast, human-like motion for demonstrations and light objects.
Keep in mind
Low fingertip force, so not for heavy objects. No touch sensing. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$83,860 Get a quote
H2 EDU SMART C

H2 EDU SMART C

H2 EDU SMART C

Programmable H2 with a pair of Dex3-1 three-finger hands with touch sensing.

End effector
Pair of Dex3-1 three-finger hands with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full hand specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$84,160 Get a quote
H2 EDU SMART G

H2 EDU SMART G

H2 EDU SMART G

Programmable H2 with a pair of BrainCo Revo 2 hands with touch sensing.

End effector
Pair of BrainCo Revo 2 hands with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$84,160 Get a quote
H2 PLUS ULTIMATE-A

H2 PLUS ULTIMATE-A

H2 PLUS ULTIMATE-A

Programmable H2 with a pair of Dex1-1 Advanced grippers, with wrist cameras.

End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full hand specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$84,760 Get a quote
H2 EDU SMART I

H2 EDU SMART I

H2 EDU SMART I

Programmable H2 with a pair of Inspire E2 five-finger hands with touch sensing.

End effector
Pair of Inspire E2 five-finger hands with touch sensing

A sturdier five-finger hand with strong fingertips and 17 touch sensors.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
30 N whole hand; 30 N thumb, 28 N fingers at the fingertip
Load
15 kg
Speed
Closes the palm in 0.8 s
Touch
17 tactile sensors, 0 to 30 N
Repeatability
±0.20 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 790 g
Drive
Linear servos
Control
Force-threshold control
Interface
RS-485 or CAN, plus Modbus TCP
Software
Supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Five-finger work that needs both real fingertip force and touch.
Keep in mind
Heavier than the Revo 2 and Linker O6, which uses up more arm payload. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$87,860 Get a quote
H2 PLUS ULTIMATE-F

H2 PLUS ULTIMATE-F

H2 PLUS ULTIMATE-F

Programmable H2 with a pair of BrainCo Revo 2 five-finger hands.

End effector
Pair of BrainCo Revo 2 five-finger hands

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$96,960 Get a quote
H2 PLUS ULTIMATE-B

H2 PLUS ULTIMATE-B

H2 PLUS ULTIMATE-B

Programmable H2 with a pair of Dex3-1 three-finger hands.

End effector
Pair of Dex3-1 three-finger hands

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full hand specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$98,960 Get a quote
H2 EDU SMART D

H2 EDU SMART D

H2 EDU SMART D

Programmable H2 with a pair of Dex5-1 five-finger hands.

End effector
Pair of Dex5-1 five-finger hands

A full five-finger research hand where each finger can move and spread on its own. It grips objects as small as 10 mm.

Full hand specs and what they mean
Type
Research-grade five-finger hand
Motion
16 DoF per hand. 16 active motors: thumb 4, each finger 3. Four more knuckle joints are coupled to them, so Unitree counts 20 DoF in total.
Force
10 N at the fingertip
Load
3.5 kg palm down, 4.5 kg palm sideways, on a 5 cm sphere
Smallest grip
10 mm
Touch
No touch sensors. The joints sense their own torque.
Repeatability
±1 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
1.1 kg
Size
217 × 128 × 72 mm
Drive
12 micro force-control joints plus 4 geared joints
Control
Joint position, velocity, torque, stiffness and damping
Interface
USB 2.0, 1000 Hz feedback
Software
URDF model available
Best for
Dexterity and in-hand manipulation research on the H2.
Keep in mind
H2 only. No touch sensors on this version.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$99,700 Get a quote
H2 PLUS ULTIMATE-C

H2 PLUS ULTIMATE-C

H2 PLUS ULTIMATE-C

Programmable H2 with a pair of Dex3-1 three-finger hands with touch sensing.

End effector
Pair of Dex3-1 three-finger hands with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full hand specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$100,960 Get a quote
H2 PLUS ULTIMATE-G

H2 PLUS ULTIMATE-G

H2 PLUS ULTIMATE-G

Programmable H2 with a pair of BrainCo Revo 2 hands with touch sensing.

End effector
Pair of BrainCo Revo 2 hands with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$100,960 Get a quote
H2 PLUS ULTIMATE-H

H2 PLUS ULTIMATE-H

H2 PLUS ULTIMATE-H

Programmable H2 with a pair of Inspire DFQ five-finger hands.

End effector
Pair of Inspire DFQ five-finger hands

A fast, light-duty five-finger hand. Quick fingers, but low fingertip force compared with the others here.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
6 N thumb, 4 N fingers
Speed
Fingers flex at 570°/s, thumb at 150°/s
Touch
None
Repeatability
±0.20 mm
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Best for
Fast, human-like motion for demonstrations and light objects.
Keep in mind
Low fingertip force, so not for heavy objects. No touch sensing. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$100,960 Get a quote
H2 PLUS ULTIMATE-I

H2 PLUS ULTIMATE-I

H2 PLUS ULTIMATE-I

Programmable H2 with a pair of Inspire E2 five-finger hands with touch sensing.

End effector
Pair of Inspire E2 five-finger hands with touch sensing

A sturdier five-finger hand with strong fingertips and 17 touch sensors.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 12 joints.
Force
30 N whole hand; 30 N thumb, 28 N fingers at the fingertip
Load
15 kg
Speed
Closes the palm in 0.8 s
Touch
17 tactile sensors, 0 to 30 N
Repeatability
±0.20 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 790 g
Drive
Linear servos
Control
Force-threshold control
Interface
RS-485 or CAN, plus Modbus TCP
Software
Supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Five-finger work that needs both real fingertip force and touch.
Keep in mind
Heavier than the Revo 2 and Linker O6, which uses up more arm payload. On a G1, Unitree warns against squatting or lying down with Inspire hands fitted.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$104,660 Get a quote
H2 EDU SMART E

H2 EDU SMART E

H2 EDU SMART E

Programmable H2 with a pair of Dex5-1P five-finger hands with touch sensing.

End effector
Pair of Dex5-1P five-finger hands with touch sensing

The Dex5-1 with 94 pressure sensors across the palm, finger pads, fingertips and finger bases.

Full hand specs and what they mean
Type
Research-grade five-finger hand with touch sensing
Motion
16 DoF per hand. 16 active motors: thumb 4, each finger 3. Four more knuckle joints are coupled to them, so Unitree counts 20 DoF in total.
Force
10 N at the fingertip
Load
3.5 kg palm down, 4.5 kg palm sideways, on a 5 cm sphere
Smallest grip
10 mm
Touch
94 pressure sensors in 12 arrays, sensing 10 g to 2.5 kg
Repeatability
±1 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
1.1 kg
Size
217 × 128 × 72 mm
Drive
12 micro force-control joints plus 4 geared joints
Control
Joint position, velocity, torque, stiffness and damping
Interface
USB 2.0, 1000 Hz feedback
Software
URDF model available
Best for
Dexterity research that also needs detailed touch data.
Keep in mind
H2 only.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$104,700 Get a quote
H2 EDU SMART M

H2 EDU SMART M

H2 EDU SMART M

Programmable H2 with a pair of Wuji Hand 2 five-finger hands.

End effector
Pair of Wuji Hand 2 five-finger hands

Twenty motors with no gearbox slowing them down, so fingers are quick and can be pushed back by hand, close to how a person moves.

Full hand specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
20 DoF per hand. 20 active motors, one for each joint it can move.
Force
12 N or more at the fingertip
Smallest grip
0 mm
Speed
4 or more open and close cycles per second
Touch
None on this version
Precision
Joint backlash under 1°
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 800 g
Size
About 180 × 80 × 40 mm
Drive
Direct-drive rotary joints
Control
MIT hybrid force and position
Interface
Ethernet, 1000 Hz on all 20 axes
Software
Python and C SDK, ROS 2, MuJoCo and Isaac
Best for
Dexterous research and learning skilled finger motion on a G1 or H2.
Keep in mind
Overkill for simple grasping. Wuji labels its published figures as Beta, so confirm any figure you depend on with us.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$106,200 Get a quote
H2 EDU SMART J

H2 EDU SMART J

H2 EDU SMART J

Programmable H2 with a pair of BrainCo Revo 3 U21 five-finger hands.

End effector
Pair of BrainCo Revo 3 U21 five-finger hands

A large, strong, fully articulated hand. Twenty-one motors with no gearbox slowing them, and all fingers can touch the palm.

Full hand specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
High-dexterity work on the adult-size H2 that also needs real strength.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$111,400 Get a quote
H2 PLUS ULTIMATE-D

H2 PLUS ULTIMATE-D

H2 PLUS ULTIMATE-D

Programmable H2 with a pair of Dex5-1 five-finger hands.

End effector
Pair of Dex5-1 five-finger hands

A full five-finger research hand where each finger can move and spread on its own. It grips objects as small as 10 mm.

Full hand specs and what they mean
Type
Research-grade five-finger hand
Motion
16 DoF per hand. 16 active motors: thumb 4, each finger 3. Four more knuckle joints are coupled to them, so Unitree counts 20 DoF in total.
Force
10 N at the fingertip
Load
3.5 kg palm down, 4.5 kg palm sideways, on a 5 cm sphere
Smallest grip
10 mm
Touch
No touch sensors. The joints sense their own torque.
Repeatability
±1 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
1.1 kg
Size
217 × 128 × 72 mm
Drive
12 micro force-control joints plus 4 geared joints
Control
Joint position, velocity, torque, stiffness and damping
Interface
USB 2.0, 1000 Hz feedback
Software
URDF model available
Best for
Dexterity and in-hand manipulation research on the H2.
Keep in mind
H2 only. No touch sensors on this version.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$116,500 Get a quote
H2 PLUS ULTIMATE-E

H2 PLUS ULTIMATE-E

H2 PLUS ULTIMATE-E

Programmable H2 with a pair of Dex5-1P five-finger hands with touch sensing.

End effector
Pair of Dex5-1P five-finger hands with touch sensing

The Dex5-1 with 94 pressure sensors across the palm, finger pads, fingertips and finger bases.

Full hand specs and what they mean
Type
Research-grade five-finger hand with touch sensing
Motion
16 DoF per hand. 16 active motors: thumb 4, each finger 3. Four more knuckle joints are coupled to them, so Unitree counts 20 DoF in total.
Force
10 N at the fingertip
Load
3.5 kg palm down, 4.5 kg palm sideways, on a 5 cm sphere
Smallest grip
10 mm
Touch
94 pressure sensors in 12 arrays, sensing 10 g to 2.5 kg
Repeatability
±1 mm at the fingertip
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
1.1 kg
Size
217 × 128 × 72 mm
Drive
12 micro force-control joints plus 4 geared joints
Control
Joint position, velocity, torque, stiffness and damping
Interface
USB 2.0, 1000 Hz feedback
Software
URDF model available
Best for
Dexterity research that also needs detailed touch data.
Keep in mind
H2 only.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$121,500 Get a quote
H2 PLUS ULTIMATE-M

H2 PLUS ULTIMATE-M

H2 PLUS ULTIMATE-M

Programmable H2 with a pair of Wuji Hand 2 five-finger hands.

End effector
Pair of Wuji Hand 2 five-finger hands

Twenty motors with no gearbox slowing them down, so fingers are quick and can be pushed back by hand, close to how a person moves.

Full hand specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
20 DoF per hand. 20 active motors, one for each joint it can move.
Force
12 N or more at the fingertip
Smallest grip
0 mm
Speed
4 or more open and close cycles per second
Touch
None on this version
Precision
Joint backlash under 1°
Wrist camera
RGB wrist camera, 130° diagonal field of view, 1920 × 1080, with mount
Weight
About 800 g
Size
About 180 × 80 × 40 mm
Drive
Direct-drive rotary joints
Control
MIT hybrid force and position
Interface
Ethernet, 1000 Hz on all 20 axes
Software
Python and C SDK, ROS 2, MuJoCo and Isaac
Best for
Dexterous research and learning skilled finger motion on a G1 or H2.
Keep in mind
Overkill for simple grasping. Wuji labels its published figures as Beta, so confirm any figure you depend on with us.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$123,000 Get a quote
H2 EDU SMART K

H2 EDU SMART K

H2 EDU SMART K

Programmable H2 with a pair of BrainCo Revo 3 U21T hands with full-palm touch.

End effector
Pair of BrainCo Revo 3 U21T hands with full-palm touch

The Revo 3 with touch sensing across the whole palm and fingers, sensitive to a hundredth of a newton.

Full hand specs and what they mean
Type
Research-grade hand with full-palm touch sensing
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
Full-palm array of 451 points, 0.01 N resolution
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Training AI on rich touch data on the H2.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$124,400 Get a quote
H2 PLUS ULTIMATE-J

H2 PLUS ULTIMATE-J

H2 PLUS ULTIMATE-J

Programmable H2 with a pair of BrainCo Revo 3 U21 five-finger hands.

End effector
Pair of BrainCo Revo 3 U21 five-finger hands

A large, strong, fully articulated hand. Twenty-one motors with no gearbox slowing them, and all fingers can touch the palm.

Full hand specs and what they mean
Type
Research-grade direct-drive five-finger hand
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
None
Repeatability
0.1° at the joint
Wrist camera
Wide 196° Sensing SHF3L wrist camera. Works with the Jetson Thor board fitted to this edition.
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
High-dexterity work on the adult-size H2 that also needs real strength.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$128,200 Get a quote
H2 PLUS ULTIMATE-K

H2 PLUS ULTIMATE-K

H2 PLUS ULTIMATE-K

Programmable H2 with a pair of BrainCo Revo 3 U21T hands with full-palm touch.

End effector
Pair of BrainCo Revo 3 U21T hands with full-palm touch

The Revo 3 with touch sensing across the whole palm and fingers, sensitive to a hundredth of a newton.

Full hand specs and what they mean
Type
Research-grade hand with full-palm touch sensing
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Speed
3 Hz joint speed
Touch
Full-palm array of 451 points, 0.01 N resolution
Repeatability
0.1° at the joint
Wrist camera
Wide 196° Sensing SHF3L wrist camera. Works with the Jetson Thor board fitted to this edition.
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Training AI on rich touch data on the H2.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$141,200 Get a quote
H2 EDU SMART L

H2 EDU SMART L

H2 EDU SMART L

Programmable H2 with a pair of BrainCo Revo 3 U21V hands with vision-based touch.

End effector
Pair of BrainCo Revo 3 U21V hands with vision-based touch

Tiny cameras inside the fingertips watch a soft skin deform, so the hand can sense texture and very slight contact.

Full hand specs and what they mean
Type
Research-grade hand with vision-based fingertips
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Touch
Full-palm array plus vision-based fingertips, detecting down to 130 µm of deformation
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Leading-edge research into touch and fine manipulation.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2). PC3 can take a Jetson Thor and PC4 an Intel i7 or Orin NX as paid options. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code. Jetson Thor and Orin NX are paid options.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
$158,200 Get a quote
H2 PLUS ULTIMATE-L

H2 PLUS ULTIMATE-L

H2 PLUS ULTIMATE-L

Programmable H2 with a pair of BrainCo Revo 3 U21V hands with vision-based touch.

End effector
Pair of BrainCo Revo 3 U21V hands with vision-based touch

Tiny cameras inside the fingertips watch a soft skin deform, so the hand can sense texture and very slight contact.

Full hand specs and what they mean
Type
Research-grade hand with vision-based fingertips
Motion
21 DoF per hand. 21 direct-drive motors: 4 on each finger, 5 on the thumb.
Force
At least 70 N whole hand, 20 N pinch
Load
20 kg whole hand, 5 kg four fingers
Grip range
Grasps 10 to 150 mm
Smallest grip
10 mm
Touch
Full-palm array plus vision-based fingertips, detecting down to 130 µm of deformation
Repeatability
0.1° at the joint
Wrist camera
Wide 196° Sensing SHF3L wrist camera. Works with the Jetson Thor board fitted to this edition.
Size
About 215 × 105 × 50 mm
Drive
Direct drive
Interface
EtherCAT, CAN FD or RS-485
Software
C/C++ and Python SDK, ROS 2 Humble and Isaac Lab
Best for
Leading-edge research into touch and fine manipulation.
Keep in mind
H2 only. H2 Plus versions also need the Jetson Thor board.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$175,000 Get a quote
H2 PLUS ULTIMATE-N

H2 PLUS ULTIMATE-N

H2 PLUS ULTIMATE-N

Programmable H2 with a pair of SharpaWave five-finger hands.

End effector
Pair of SharpaWave five-finger hands

The strongest hand in the range, with the most motors and camera-based touch in every fingertip.

Full hand specs and what they mean
Type
Research-grade hand with vision-based fingertips
Motion
22 DoF per hand. 22 active motors per hand.
Force
150 N whole hand, 20 N at the fingertip
Load
At least 30 kg
Speed
Above 4 Hz
Touch
Vision-based fingertips at 240 × 240 resolution, 0 to 30 N
Repeatability
±1 mm at the fingertip
Wrist camera
Wide 196° Sensing SHF3L wrist camera
Weight
1.3 kg
Size
208 × 90 × 50 mm
Interface
Gigabit Ethernet
Software
C++ and Python SDK, ROS 2, MuJoCo and Isaac Sim
Best for
The most demanding dexterity and tactile research on the H2.
Keep in mind
H2 Plus only, and needs the Jetson Thor board. By far the most expensive hand here.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included, over 100 m range in the open. Covers movement and presets such as wave and handshake. Debug mode for development.
App
Unitree Explore. Unitree issues an enterprise account for H2 login.
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
Intel i7 (PC2) and NVIDIA Jetson Thor (PC3) built in. PC4 can take an Intel i7 or Orin NX as a paid option. PC1 stays reserved for Unitree.
Simulation
MuJoCo model
Teleoperation
Unitree's xr_teleoperate, with Apple Vision Pro, PICO 4 Ultra Enterprise or Quest 3 (7-DoF arm supported)
Voice
Microphone array and high-power speakers
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Intel i5 for platform functions, Intel i7 for your code, NVIDIA Jetson Thor built in.
  • Platform: 1.82 m, about 70 kg, bionic head and face, about 3 hours of runtime, arms rated 7 kg (15 kg peak).
  • H2 Plus adds a custom face, a global-shutter head camera and external ports: USB, GMSL, Gigabit Ethernet, RS-485 and CAN.
$240,000 Get a quote
Humanoid hands configurator

Not sure which hand your robot needs?

Answer a few questions and we narrow 19 hands and grippers down to the three that fit your job, and show which Unitree robots each one works with. Every term, from degrees of freedom to repeatability, is explained in plain language as you go. No commitment.

  • A plain-language path for first-time buyers, a specs path for engineers
  • Tap any term like DoF or 0.1° repeatability for a simple explanation
  • Live list prices, what fits which robot, and a one-click quote request
Open the hands configurator → About two minutes. No commitment.
Unitree Dex5-1 five-finger dexterous hand
ConfigurationEnd effectorDoFComputeProgrammingWarrantyPrice
H2 None 31 Intel i5 (platform only) Not offered 8 months $39,900
H2 EDU Standard None 31 Intel i5 + i7, Thor optional Yes, high and low level 12 months $66,800
H2 Plus Standard None 31 Intel i5 + i7, Thor optional Yes, high and low level 12 months $66,800
H2 EDU SMART A Dex1-1 Advanced gripper 33 Intel i5 + i7, Thor optional Yes, high and low level 12 months $67,960
H2 EDU SMART F BrainCo Revo 2 43 Intel i5 + i7, Thor optional Yes, high and low level 12 months $80,160
H2 EDU SMART B Dex3-1 3-finger 45 Intel i5 + i7, Thor optional Yes, high and low level 12 months $82,160
H2 Plus SMART None 31 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $83,600
H2 EDU SMART H Inspire DFQ 43 Intel i5 + i7, Thor optional Yes, high and low level 12 months $83,860
H2 EDU SMART C Dex3-1 3-finger, tactile 45 Intel i5 + i7, Thor optional Yes, high and low level 12 months $84,160
H2 EDU SMART G BrainCo Revo 2, tactile 43 Intel i5 + i7, Thor optional Yes, high and low level 12 months $84,160
H2 PLUS ULTIMATE-A Dex1-1 Advanced gripper 33 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $84,760
H2 EDU SMART I Inspire E2, tactile 43 Intel i5 + i7, Thor optional Yes, high and low level 12 months $87,860
H2 PLUS ULTIMATE-F BrainCo Revo 2 43 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $96,960
H2 PLUS ULTIMATE-B Dex3-1 3-finger 45 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $98,960
H2 EDU SMART D Dex5-1 5-finger 63 Intel i5 + i7, Thor optional Yes, high and low level 12 months $99,700
H2 PLUS ULTIMATE-C Dex3-1 3-finger, tactile 45 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $100,960
H2 PLUS ULTIMATE-G BrainCo Revo 2, tactile 43 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $100,960
H2 PLUS ULTIMATE-H Inspire DFQ 43 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $100,960
H2 PLUS ULTIMATE-I Inspire E2, tactile 43 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $104,660
H2 EDU SMART E Dex5-1P 5-finger, tactile 63 Intel i5 + i7, Thor optional Yes, high and low level 12 months $104,700
H2 EDU SMART M Wuji Hand 2 71 Intel i5 + i7, Thor optional Yes, high and low level 12 months $106,200
H2 EDU SMART J BrainCo Revo 3 U21 73 Intel i5 + i7, Thor optional Yes, high and low level 12 months $111,400
H2 PLUS ULTIMATE-D Dex5-1 5-finger 63 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $116,500
H2 PLUS ULTIMATE-E Dex5-1P 5-finger, tactile 63 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $121,500
H2 PLUS ULTIMATE-M Wuji Hand 2 71 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $123,000
H2 EDU SMART K BrainCo Revo 3 U21T, tactile 73 Intel i5 + i7, Thor optional Yes, high and low level 12 months $124,400
H2 PLUS ULTIMATE-J BrainCo Revo 3 U21 73 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $128,200
H2 PLUS ULTIMATE-K BrainCo Revo 3 U21T, tactile 73 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $141,200
H2 EDU SMART L BrainCo Revo 3 U21V, visuo-tactile 73 Intel i5 + i7, Thor optional Yes, high and low level 12 months $158,200
H2 PLUS ULTIMATE-L BrainCo Revo 3 U21V, visuo-tactile 73 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $175,000
H2 PLUS ULTIMATE-N SharpaWave 75 Intel i5 + i7 + NVIDIA Jetson Thor Yes, high and low level 12 months $240,000

Prices are US MSRP and exclude tax, duty and freight. Configurations, lead times and specifications are subject to change by the manufacturer.

Gallery

See the Unitree H2 Humanoid Robot

See it in action

Full-body coordination on stage

Flowing arm movement, turns and balanced poses across all 31 degrees of freedom.

Footage courtesy of Unitree Robotics.

Talk to a specialist

Get pricing & a free demo of the Unitree H2 Humanoid Robot.

Same-day response. We handle delivery, on-site setup, staff training, and ongoing service nationwide.

Questions & answers

About the Unitree H2 Humanoid Robot.

  1. What makes the H2 EDU different from the standard Unitree H2?

    The EDU version is the configuration that unlocks full secondary development — open APIs, deep access to the robot's systems, and the ability to build custom software on top of the platform. The standard H2 is geared toward demonstration and stock behaviors, while the EDU is what research and development teams actually program against. RobotLAB sells the EDU configuration with delivery, training, and support. Call 1-87-RobotLAB to confirm exactly which features and warranty terms come with your build.

  2. Is the Unitree H2 EDU a good fit for a university research lab?

    Yes — it is one of its primary markets. A full-size, 31-DOF walking humanoid with open development access supports bipedal locomotion research, reinforcement learning, embodied-AI work, and human-robot interaction studies. RobotLAB handles procurement, on-site installation, and faculty/student training so your group can start research quickly. Call 1-87-RobotLAB to discuss grant timelines and configurations.

  3. Can I lease the H2 EDU or get it as a subscription instead of buying?

    Yes. RobotLAB sells, leases, and offers Robotics-as-a-Service (RaaS) subscriptions in addition to outright purchase, which lets institutions access a high-end humanoid without the full capital outlay up front. The listed RobotLAB purchase price is $39,900. Call 1-87-RobotLAB to compare purchase, lease, and RaaS pricing for your situation.

  4. What compute and AI hardware does the H2 EDU run?

    The H2 line uses onboard Intel processors, and the EDU configuration adds a secondary processing unit; high-end AI compute modules are available for heavier perception and learning workloads. Because the exact compute and any AI-accelerator option vary by build, we recommend confirming the specification at quote time rather than assuming a fixed configuration. Call 1-87-RobotLAB and we'll spec the right setup for your software stack.

  5. Does it come with dexterous hands for manipulation tasks?

    Dexterous hands are an optional upgrade rather than standard on the base unit. If your research or application involves grasping and fine manipulation, RobotLAB can include the hand option in your configuration. Call 1-87-RobotLAB to add manipulation hardware to your quote.

  6. What support does RobotLAB provide after purchase?

    As America's largest commercial robotics integrator, RobotLAB is your single point of contact for delivery, on-site setup, operator and developer training, warranty, and ongoing service — you are not left coordinating directly with an overseas manufacturer. We support single units and multi-robot fleets nationwide. Call 1-87-RobotLAB to review support and warranty terms.

  7. How does the H2 EDU compare to the smaller Unitree G1?

    The H2 is a larger, adult-scale humanoid (~180 cm, ~70 kg, 31 DOF) with higher joint torque, while the G1 is a smaller, lighter platform (~1.27 m, ~35 kg) that is more affordable and easier to handle. Teams choose the H2 when they need full adult scale and higher payload, and the G1 when budget, portability, or bench-scale work matter more. Call 1-87-RobotLAB and we'll help you pick the right platform for your goals.

Have another question? Same-day response.Request a quote →Book a demo
Related robots

More humanoid robots robots

Unitree R1-A5 Dual-Arm Humanoid Robot
Unitree Humanoid

Unitree R1-A5 Dual-Arm Humanoid Robot

The Unitree R1-A5 is a fixed-base dual-arm humanoid: 13 degrees of freedom (5 per arm, 1 waist, 2 head), roughly 11 kg, with a 420 mm arm reach and about 2 kg payload per arm. The R1-A5-D variant adds a wheeled chassis a

From $7,200 purchase
Unitree G1-D Humanoid Robot
Unitree Humanoid

Unitree G1-D Humanoid Robot

The Unitree G1-D pairs the G1 upper body with a wheeled chassis and an end-to-end data-collection stack, aimed at teams gathering manipulation demonstrations at scale rather than working on locomotion.

From $38,800 purchase
Unitree G1 Humanoid Robot
Unitree Humanoid

Unitree G1 Humanoid Robot

The Unitree G1 is a compact bipedal humanoid built for research, education and content work. It stands about 1.27 m, weighs roughly 35 kg with its quick-release battery, and ships with 23 degrees of freedom — rising to 4

From $17,990 purchase
Request a walkthrough