19 Years · America's Largest Robotics Integrator
Home/ Store/ Humanoid/ Unitree G1-D Humanoid Robot

Unitree G1-D Humanoid Robot

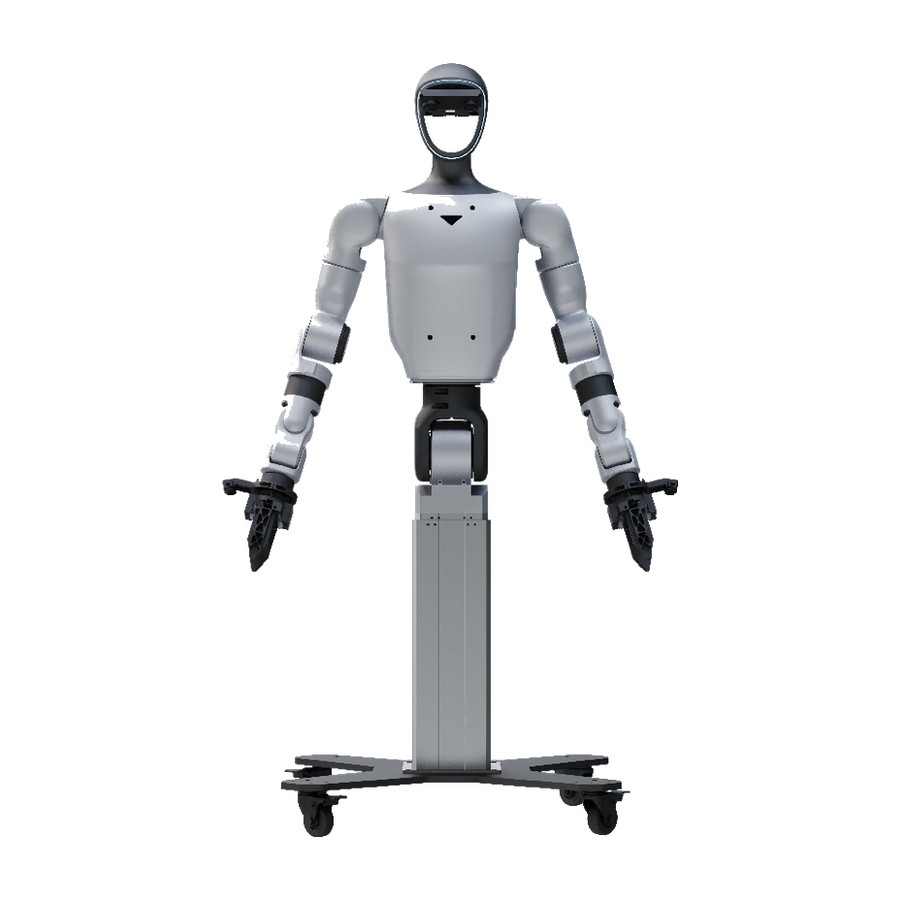
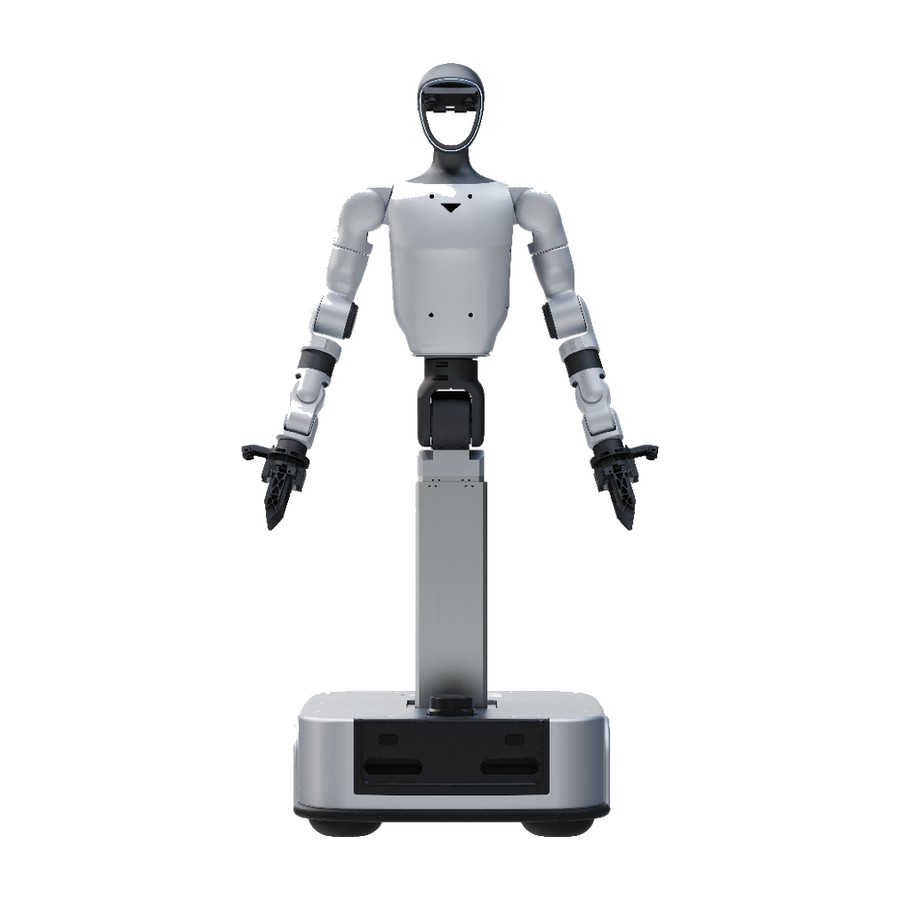
The Unitree G1-D pairs the G1 upper body with a wheeled chassis and an end-to-end data-collection stack, aimed at teams gathering manipulation demonstrations at scale rather than working on locomotion.

Configurations from
$38,800 – $66,300
10 configurations · compare them

Purchase · Lease

Unitree G1-D Humanoid Robot — Unitree
Manufacturer
Unitree
Capability
Humanoid Robots
Support
US sales, setup & service
Overview

What is the Unitree G1-D Humanoid Robot?

The Unitree G1-D pairs the G1 upper body with a wheeled chassis and an end-to-end data-collection stack, aimed at teams gathering manipulation demonstrations at scale rather than working on locomotion.

Configurations differ mainly by the hands fitted and by whether the VR teleoperation kit and data-acquisition platform are included.

RobotLAB supplies the full Unitree humanoid range in the United States, with 10 G1-D configurations currently listed, from $38,800 to $66,300. Every configuration below is quoted, supported and serviced from the US.

Specifications

Key specs

Height x Width x Depth (Minimum Height)Approx. 1260 x 525 x 570 mm
Height x Width x Depth (Maximum Height)Approx. 1680 x 525 x 570 mm
Weight with BatteryApprox. 80 kg
Maximum Arm PayloadApprox. 3kg
Arm Reach (excluding end effector)Approx. 0.45m
Waist Degrees of Freedom2
Waist Joint Motion RangeZ±155°, Y -2.5°~+135°
Lifting stroke450mm; Lifting accuracy: 1mm; Lifting speed: max 60mm/s
Maximum working heightapprox. 2m
Cooling systemLocalized air cooling
Upper body power supplyBattery-powered or direct power cable connection
Chassis power supplyBattery-powered / Charging station-powered Upper body battery runtime: 2 hours
Chassis battery runtime6 hours
Upper body battery (quick-release)9000mAh
Chassis battery (built-in)30Ah
Includes main unit charger54V 5A
Includes chassis charging station51V 10A
Base Computing Power8-core high-performance CPU
High-Performance Computing ModuleNVIDIA Jetson Orin 16G (100 TOPS computing power)
4-Microphone ArraySupported
5W SpeakerSupported
Wi-Fi 6, Bluetooth 5.2Supported
How it works

Unitree G1-D Humanoid Robot in detail

Choosing a configuration

The table below is the honest version of the spec sheet: it shows only what actually differs between configurations, so you can see what the extra money buys. Shared platform specifications are listed separately — they apply to every unit in the range.

Typical buyers are embodied-AI teams building manipulation datasets. If you are not sure which build fits your work, ask us: we configure these for US customers every week and will tell you when a cheaper configuration does the job.

See the rest of the range on our humanoid robots page, or browse everything we carry from Unitree.

Most configurations differ only by the hand fitted. If you want to compare end effectors on their own, see Unitree humanoid hands and grippers.

Configurations

Which Unitree G1-D Humanoid Robot is right for you?

Every configuration below is the same core platform. They differ in compute, degrees of freedom and end effectors — from $38,800 to $66,300.

G1-D Standard A Humanoid Robot

G1-D Standard A Humanoid Robot

G1-D Standard A

Programmable G1-D with a pair of Dex1-1 Advanced grippers, with wrist cameras.

End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full hand specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Standard: on a push-pull base with no electric drive. Runs on battery or a power cable.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$38,800 Get a quote
G1-D Standard D Humanoid Robot

G1-D Standard D Humanoid Robot

G1-D Standard D

Programmable G1-D with a pair of BrainCo Revo 2 five-finger hands.

End effector
Pair of BrainCo Revo 2 five-finger hands

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Standard: on a push-pull base with no electric drive. Runs on battery or a power cable.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$49,800 Get a quote
G1-D Standard B Humanoid Robot

G1-D Standard B Humanoid Robot

G1-D Standard B

Programmable G1-D with a pair of Dex3-1 three-finger hands.

End effector
Pair of Dex3-1 three-finger hands

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full hand specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Standard: on a push-pull base with no electric drive. Runs on battery or a power cable.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$51,800 Get a quote
G1-D Ultimate A Humanoid Robot

G1-D Ultimate A Humanoid Robot

G1-D Ultimate A

Programmable G1-D with a pair of Dex1-1 Advanced grippers, with wrist cameras.

End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full hand specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Ultimate: on a driven dual-wheel chassis that turns on the spot.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$51,900 Get a quote
G1-D Standard C Humanoid Robot

G1-D Standard C Humanoid Robot

G1-D Standard C

Programmable G1-D with a pair of Dex3-1 three-finger hands with touch sensing.

End effector
Pair of Dex3-1 three-finger hands with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full hand specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Standard: on a push-pull base with no electric drive. Runs on battery or a power cable.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$53,800 Get a quote
G1-D Standard E Humanoid Robot

G1-D Standard E Humanoid Robot

G1-D Standard E

Programmable G1-D with a pair of BrainCo Revo 2 hands with touch sensing.

End effector
Pair of BrainCo Revo 2 hands with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Standard: on a push-pull base with no electric drive. Runs on battery or a power cable.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$53,800 Get a quote
G1-D Ultimate D Humanoid Robot

G1-D Ultimate D Humanoid Robot

G1-D Ultimate D

Programmable G1-D with a pair of BrainCo Revo 2 five-finger hands.

End effector
Pair of BrainCo Revo 2 five-finger hands

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Ultimate: on a driven dual-wheel chassis that turns on the spot.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$62,300 Get a quote
G1-D Ultimate B Humanoid Robot

G1-D Ultimate B Humanoid Robot

G1-D Ultimate B

Programmable G1-D with a pair of Dex3-1 three-finger hands.

End effector
Pair of Dex3-1 three-finger hands

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full hand specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Ultimate: on a driven dual-wheel chassis that turns on the spot.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$64,300 Get a quote
G1-D Ultimate C Humanoid Robot

G1-D Ultimate C Humanoid Robot

G1-D Ultimate C

Programmable G1-D with a pair of Dex3-1 three-finger hands with touch sensing.

End effector
Pair of Dex3-1 three-finger hands with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full hand specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Ultimate: on a driven dual-wheel chassis that turns on the spot.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$66,300 Get a quote
G1-D Ultimate E Humanoid Robot

G1-D Ultimate E Humanoid Robot

G1-D Ultimate E

Programmable G1-D with a pair of BrainCo Revo 2 hands with touch sensing.

End effector
Pair of BrainCo Revo 2 hands with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, at joint level. C++ or Python SDK, over DDS or ROS 2. Unitree notes the G1 high-level motion interface does not apply.
Remote
Handheld remote included: lift column and data-collection mode. The G1-D does not walk.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
Your code runs on
Jetson Orin 16 GB, 100 TOPS (PC2), plus a visualization computer. AGX Orin or Thor docks are optional.
Teleoperation
Built for it: VR teleoperation data mode with Unitree xr_teleoperate. PICO VR kit and data-collection software are available as accessories.
Voice
4-microphone array and 5 W speaker
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: Jetson Orin 16 GB, 100 TOPS, plus a visualization computer.
  • Ultimate: on a driven dual-wheel chassis that turns on the spot.
  • 7-DoF arms carrying about 3 kg, 2-DoF waist, lift column with 500 mm of travel. Works up to about 2 m high.
  • Head stereo camera and two wrist cameras.
$66,300 Get a quote
ConfigurationEnd effectorDoFComputeProgrammingWarrantyPrice
G1-D Standard A Humanoid Robot Dex1-1 Advanced gripper 19 Jetson Orin, 100 TOPS Yes, joint level 12 months $38,800
G1-D Standard D Humanoid Robot BrainCo Revo 2 29 Jetson Orin, 100 TOPS Yes, joint level 12 months $49,800
G1-D Standard B Humanoid Robot Dex3-1 3-finger 31 Jetson Orin, 100 TOPS Yes, joint level 12 months $51,800
G1-D Ultimate A Humanoid Robot Dex1-1 Advanced gripper 21 Jetson Orin, 100 TOPS Yes, joint level 12 months $51,900
G1-D Standard C Humanoid Robot Dex3-1 3-finger, tactile 31 Jetson Orin, 100 TOPS Yes, joint level 12 months $53,800
G1-D Standard E Humanoid Robot BrainCo Revo 2, tactile 29 Jetson Orin, 100 TOPS Yes, joint level 12 months $53,800
G1-D Ultimate D Humanoid Robot BrainCo Revo 2 31 Jetson Orin, 100 TOPS Yes, joint level 12 months $62,300
G1-D Ultimate B Humanoid Robot Dex3-1 3-finger 33 Jetson Orin, 100 TOPS Yes, joint level 12 months $64,300
G1-D Ultimate C Humanoid Robot Dex3-1 3-finger, tactile 33 Jetson Orin, 100 TOPS Yes, joint level 12 months $66,300
G1-D Ultimate E Humanoid Robot BrainCo Revo 2, tactile 31 Jetson Orin, 100 TOPS Yes, joint level 12 months $66,300

Prices are US MSRP and exclude tax, duty and freight. Configurations, lead times and specifications are subject to change by the manufacturer.

See it in action

Teleoperation and data collection, end to end

A full tabletop manipulation session with close-up views of the hands and workspace — this is the workflow the G1-D exists for.

Footage courtesy of Unitree Robotics.

Talk to a specialist

Get pricing & a free demo of the Unitree G1-D Humanoid Robot.

Same-day response. We handle delivery, on-site setup, staff training, and ongoing service nationwide.

Related robots

More humanoid robots robots

Unitree H2 Humanoid Robot
Unitree Humanoid

Unitree H2 Humanoid Robot

The Unitree H2 is a full-size humanoid: 1.82 m tall, about 70 kg with battery, and 31 degrees of freedom across 6 per leg, 7 per arm, 3 at the waist and 2 in the head. Peak arm payload is around 15 kg and battery life is

From $39,900 purchase
Unitree R1 Humanoid Robot
Unitree Humanoid

Unitree R1 Humanoid Robot

The Unitree R1 is the lightweight end of the humanoid line — 1.23 m tall and about 29 kg — with 26 degrees of freedom and an 8-core onboard computer. It is the most affordable way into a walking humanoid platform.

From $6,870 purchase
NAO V6 Humanoid Robot
RobotLAB Robot

NAO V6 Humanoid Robot

The NAO V6 is the world's most widely deployed teaching humanoid — a 25-joint, fully programmable robot for K-12, special education, higher-ed, and research labs. Sold, deployed, and serviced nationwide by RobotLAB.

From $16,990 purchase
Request a walkthrough