19 Years · America's Largest Robotics Integrator
Home/ Store/ Humanoid/ Unitree R1 Humanoid Robot

Unitree R1 Humanoid Robot

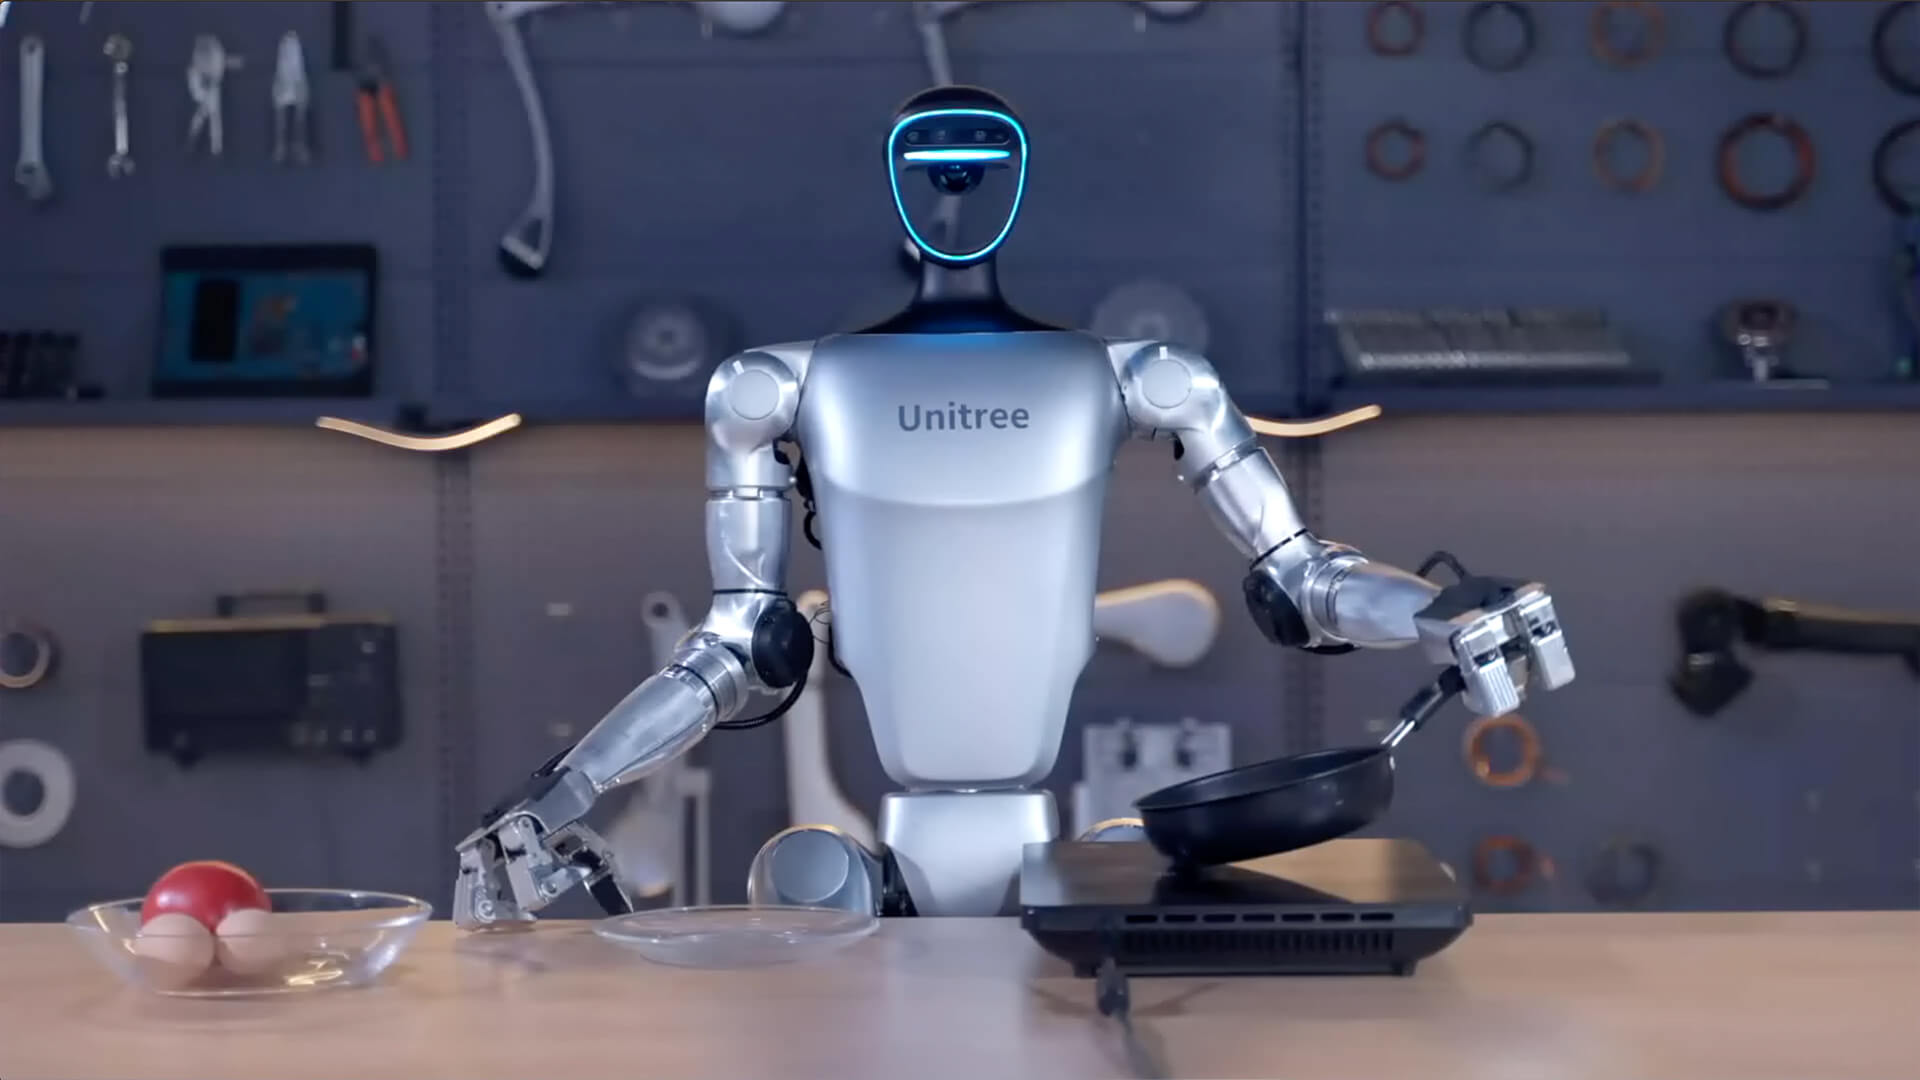
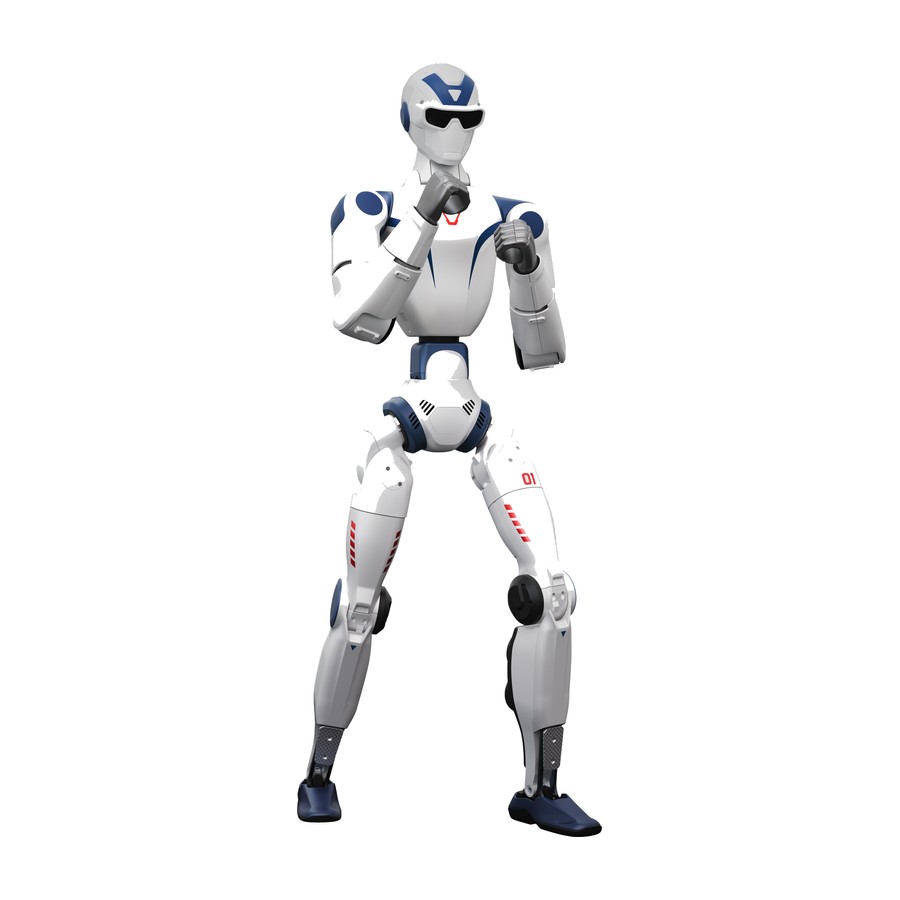
The Unitree R1 is the lightweight end of the humanoid line — 1.23 m tall and about 29 kg — with 26 degrees of freedom and an 8-core onboard computer. It is the most affordable way into a walking humanoid platform.

Configurations from
$6,870 – $32,900
12 configurations · compare them

Purchase · Lease

Unitree R1 Humanoid Robot — Unitree
Manufacturer
Unitree
Capability
Humanoid Robots
Support
US sales, setup & service
Overview

What is the Unitree R1 Humanoid Robot?

The Unitree R1 is the lightweight end of the humanoid line — 1.23 m tall and about 29 kg — with 26 degrees of freedom and an 8-core onboard computer. It is the most affordable way into a walking humanoid platform.

R1 configurations differ by compute module and by end effector, from the bare Air unit up to EDU Pro builds with force-controlled hands.

RobotLAB supplies the full Unitree humanoid range in the United States, with 12 R1 configurations currently listed, from $6,870 to $32,900. Every configuration below is quoted, supported and serviced from the US.

Specifications

Key specs

Height, Width, Depth (Standing)1210 x 357 x 190 mm
Weight with batteryapprox. 29 kg
Total degrees of freedom (joint motors)26
Degrees of freedom per leg6
Degrees of freedom at the waist2
Degrees of freedom per arm5
Degrees of freedom at the head2
Maximum arm load2 kg
Calf + thigh length0.6 m
Arm reachapprox. 0.42 m
Waist jointY ±150°, R ±30°
Knee joint-10° to +139°
Hip jointY: ±157°, P: -168° to +146°, R: -60° to +100°
Hollow internal wiring throughout all jointsYes
Joint encodersDual + single encoders
Cooling systemLocalized air cooling
Power supplyLithium-ion battery
Base computing power8-core high-performance CPU
Wi-Fi 6, Bluetooth 5.2Yes
Perception sensorsStandard humanoid stereo camera. Optional R1 LiDAR kit available
Battery lifeApproximately 1 hour
Smart OTA updatesSupported
How it is built

Inside the R1: modular body and joints

The limbs and joint assemblies laid out individually — useful if your team will be servicing or extending the platform.

Footage courtesy of Unitree Robotics.

How it works

Unitree R1 Humanoid Robot in detail

Choosing a configuration

The table below is the honest version of the spec sheet: it shows only what actually differs between configurations, so you can see what the extra money buys. Shared platform specifications are listed separately — they apply to every unit in the range.

Typical buyers are teaching labs, STEM programmes and first-time humanoid buyers. If you are not sure which build fits your work, ask us: we configure these for US customers every week and will tell you when a cheaper configuration does the job.

See the rest of the range on our humanoid robots page, or browse everything we carry from Unitree.

Most configurations differ only by the hand fitted. If you want to compare end effectors on their own, see Unitree humanoid hands and grippers.

Humanoid configurator

Feeling overwhelmed by 64 humanoid configurations?

Let our AI recommend the right platform for you. Tell us what the robot is for — or the exact specs you need — and get a shortlist of three Unitree configurations, with every option explained in plain language. No commitment.

  • A guided path for business users, a technical path for engineers
  • Compute, hands, sensing and joints explained as you go
  • Live list prices and a one-click quote request
Open the humanoid configurator → About two minutes. No commitment.
Unitree G1 humanoid robot
Configurations

Which Unitree R1 Humanoid Robot is right for you?

Every configuration below is the same core platform. They differ in compute, degrees of freedom and end effectors — from $6,870 to $32,900.

R1 Air

R1 Air

R1 Air

Remote-operated R1 with no hands fitted. Not programmable.

End effector
None fitted

Unitree lists hands as an option on its programmable editions, so ask us before planning to add them here.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Not offered. Unitree lists no secondary development on this edition, so it runs built-in behaviors.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
6 months
More on control
Your code runs on
No user computer
Teleoperation
Not available: Unitree's teleoperation software runs on a development computer this edition does not have.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 8-core CPU. No user computer on this edition.
  • 1.21 m, about 27 kg, about 1 hour of runtime.
  • 4-DoF arms carrying up to 2 kg, no waist or head motors.
  • Single camera. Protective mount not included.
$6,870 Get a quote
R1 Basic

R1 Basic

R1 Basic

Remote-operated R1 with no hands fitted. Not programmable.

End effector
None fitted

Unitree lists hands as an option on its programmable editions, so ask us before planning to add them here.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Not offered. Unitree lists no secondary development on this edition, so it runs built-in behaviors.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
8 months
More on control
Your code runs on
No user computer
Teleoperation
Not available: Unitree's teleoperation software runs on a development computer this edition does not have.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 8-core CPU. No user computer on this edition.
  • 1.21 m, about 25 kg, about 1 hour of runtime.
  • 5-DoF arms carrying up to 2 kg, 2-DoF waist.
  • Humanoid stereo camera.
$8,990 Get a quote
R1 Edu standard

R1 Edu standard

R1 Edu standard

Programmable R1 with no hands fitted.

End effector
None fitted

Choose any compatible hand as an option, or pick an edition that has them fitted.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
40 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 40 TOPS docking station for your code.
  • 1.21 m, about 29 kg, about 1 hour of runtime.
  • 5-DoF arms carrying up to 2 kg, 2-DoF waist, 2-DoF head.
  • Stereo camera. LiDAR kit is optional.
$15,950 Get a quote
R1 Edu Smart

R1 Edu Smart

R1 Edu Smart

Programmable R1 with no hands fitted.

End effector
None fitted

Choose any compatible hand as an option, or pick an edition that has them fitted.

What this means
Why it matters
The arms end at the wrist. That suits walking, balance and presence, but the robot cannot pick things up.
See which hands fit →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • 5-DoF arms carrying up to 2 kg, 2-DoF waist, 2-DoF head.
  • Stereo camera. LiDAR kit is optional.
$18,900 Get a quote
R1 Edu Pro G

R1 Edu Pro G

R1 Edu Pro G

Programmable R1 with a pair of Dex1-1 Advanced grippers, with wrist cameras.

End effector
Pair of Dex1-1 Advanced grippers, with wrist cameras

The same strong gripper plus a wrist camera, so the robot can see what it is about to grab.

Full hand specs and what they mean
Type
Two-finger gripper with wrist camera
Motion
1 DoF per hand. One motor opens and closes both fingers.
Force
Adjustable 5 to 120 N
Load
20 kg form-fit (horizontal), 5 kg by friction (vertical)
Grip range
90 mm opening
Speed
Closes fully in 0.24 s
Touch
None
Precision
0.1 mm position resolution at the fingertip
Wrist camera
RGB wrist camera with mount. A D405 bracket is included, the D405 camera is not.
Weight
550 g
Size
143 × 78 × 67 mm
Drive
Motor-driven parallel gripper
Control
Angle, velocity, torque, stiffness and damping
Interface
High-speed RS-485, 1000 Hz (RS-485 to USB board included)
Software
Unitree DDS service; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Vision-guided pick and place and low-cost data collection.
Keep in mind
Cannot use tools made for human fingers.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$19,800 Get a quote
R1 Edu Pro E

R1 Edu Pro E

R1 Edu Pro E

Programmable R1 with a pair of LinkerBot O6 five-finger hands.

End effector
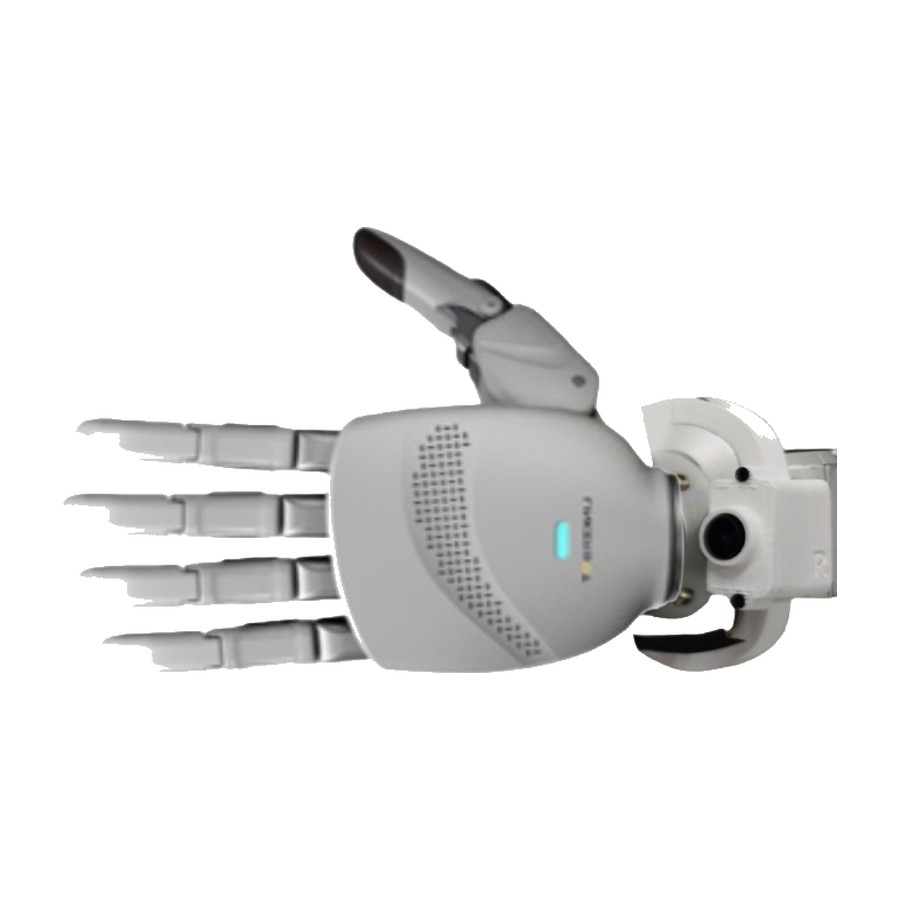
Pair of LinkerBot O6 five-finger hands

An affordable five-finger hand. Each finger closes on its own, and the thumb has two motors so it can move across the palm.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints: 6 active and 5 passive that follow.
Force
70 N whole hand; 20 N thumb, 25 N fingers at the fingertip
Touch
None
Repeatability
Under ±0.20 mm
Wrist camera
RGB wrist camera, 160° field of view, with mount
Weight
About 370 g
Drive
Rigid linkage with worm gear
Control
Force-position hybrid
Interface
CAN or RS-485
Software
ROS, ROS 2 and Python SDKs from LinkerBot
Best for
Natural five-finger grasps on an R1 on a limited budget.
Keep in mind
R1 family only. No touch sensing on this version.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$22,900 Get a quote
R1 Edu Pro H

R1 Edu Pro H

R1 Edu Pro H

Programmable R1 with a pair of five-finger tendon-driven hands.

End effector
Pair of five-finger tendon-driven hands

Looks like a human hand and closes around objects, but moves as a unit. It cannot move each finger on its own.

Full hand specs and what they mean
Type
Five-finger tendon-driven hand
Motion
2 DoF per hand. 2 motors drive 10 joints: the four fingers share one motor, the thumb has the other.
Force
10 to 15 N at the fingertip
Load
1.5 kg
Smallest grip
8 mm
Touch
None
Wrist camera
Not included
Weight
365 g
Size
151 × 70 × 63 mm
Drive
Gear and tendon
Control
Joint position, velocity, torque, stiffness and damping
Interface
RS-485, 1000 Hz, no external wiring between hand and robot
Software
URDF model available
Best for
A human look for shows and presence, and simple light grasps, at low cost.
Keep in mind
No finger-by-finger control, no touch sensing, no camera. Not for manipulation research.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$23,000 Get a quote
R1 Edu Pro F

R1 Edu Pro F

R1 Edu Pro F

Programmable R1 with a pair of LinkerBot O6 hands with touch sensing.

End effector
Pair of LinkerBot O6 hands with touch sensing

The Linker O6 with touch sensing added, so software can tell when and how firmly it is touching something.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints: 6 active and 5 passive that follow.
Force
70 N whole hand; 20 N thumb, 25 N fingers at the fingertip
Touch
Touch sensing included
Repeatability
Under ±0.20 mm
Wrist camera
RGB wrist camera, 160° field of view, with mount
Weight
About 370 g
Drive
Rigid linkage with worm gear
Control
Force-position hybrid
Interface
CAN or RS-485
Software
ROS, ROS 2 and Python SDKs from LinkerBot
Best for
An affordable way to get a five-finger hand with touch.
Keep in mind
R1 family only.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$23,200 Get a quote
R1 Edu Pro C

R1 Edu Pro C

R1 Edu Pro C

Programmable R1 with a pair of BrainCo Revo 2 five-finger hands.

End effector
Pair of BrainCo Revo 2 five-finger hands

A light, natural-looking five-finger hand. Each finger closes on its own and the thumb has two motors.

Full hand specs and what they mean
Type
Five-finger hand
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
None
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Everyday objects like cups and handles on any Unitree humanoid.
Keep in mind
No touch sensing on this version. The fingers open during power-on calibration, so never power up while holding an object.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$28,900 Get a quote
R1 Edu Pro A

R1 Edu Pro A

R1 Edu Pro A

Programmable R1 with a pair of Dex3-1 three-finger hands.

End effector
Pair of Dex3-1 three-finger hands

Three fingers with a motor at every joint, and force control. It has more independent motion than the five-finger six-motor hands, but fewer fingers.

Full hand specs and what they mean
Type
Three-finger force-controlled hand
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
None
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Manipulation research and teleoperation on the G1, G1-D, H2 and R1.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$30,900 Get a quote
R1 Edu Pro B

R1 Edu Pro B

R1 Edu Pro B

Programmable R1 with a pair of Dex3-1 three-finger hands with touch sensing.

End effector
Pair of Dex3-1 three-finger hands with touch sensing

The Dex3-1 with 33 touch sensors, so the robot can feel contact and how hard it is pressing.

Full hand specs and what they mean
Type
Three-finger force-controlled hand with touch sensing
Motion
7 DoF per hand. 7 motors: thumb 3, index 2, middle 2. Every joint is driven.
Load
500 g
Touch
33 tactile sensors, sensing 10 g to 2.5 kg
Repeatability
±2 mm at the fingertip
Wrist camera
RGB wrist camera with mount
Weight
650 to 710 g (Unitree publishes both)
Size
175 × 88 × 77 mm
Drive
6 direct-drive joints and 1 geared joint
Control
Force-position hybrid
Interface
USB 2.0, 1000 Hz
Software
Unitree SDK; supported by Unitree's xr_teleoperate and Isaac simulation
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Learning from touch, and handling delicate objects, in manipulation research.
Keep in mind
Three fingers look less human and cannot use every tool made for a five-finger hand.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$32,900 Get a quote
R1 Edu Pro D

R1 Edu Pro D

R1 Edu Pro D

Programmable R1 with a pair of BrainCo Revo 2 hands with touch sensing.

End effector
Pair of BrainCo Revo 2 hands with touch sensing

The Revo 2 with touch sensing that reports pressure, friction, direction and when an object is close.

Full hand specs and what they mean
Type
Five-finger hand with touch sensing
Motion
6 DoF per hand. 6 motors drive 11 joints.
Force
50 N whole hand, 15 N pinch
Load
20 kg or more
Grip range
100 mm opening
Touch
Pressure, friction, direction and proximity at the fingertips
Repeatability
0.1° at the joint
Wrist camera
RGB wrist camera, with mount
Weight
383 g
Size
160 mm tall, fingertip to palm base
Control
Position, speed and current
Interface
RS-485 or CAN FD
Software
BrainCo Python and C SDK, ROS 2 and MoveIt; supported by Unitree's xr_teleoperate
Teleoperation
Supported by Unitree's xr_teleoperate
Best for
Handling fragile objects, and recording touch data to train AI.
Keep in mind
Each finger closes as one unit, so it is not built for rolling objects within the fingers. The fingers open during power-on calibration.
Compare every hand, with terms explained →
Control and programming
Programming
Yes, high and low level. C++ or Python SDK, over DDS or ROS 2.
Remote
Handheld remote included: walk, dance, handshake, wave. Over 100 m range in the open. Debug mode for development.
App
Unitree Explore (iOS; Android by download from Unitree)
Warranty
12 months
More on control
In plain terms
High level means telling the robot what to do, such as stand or walk, while its built-in software does the work. Low level means commanding each joint motor, and your software then has to keep the robot balanced.
Your code runs on
100 TOPS docking station
Simulation
MuJoCo
Teleoperation
Unitree lists the 5-DoF R1 arm in xr_teleoperate. Coverage on the walking R1 is unclear, so ask us.
Voice
4-microphone array and speaker, with voice assistant
App features
Status, network setup, calibration, remote pairing and first-person driving. Unitree publishes no feature list by edition, so ask us if a specific feature matters.
Updates
Over the air
  • Compute: 100 TOPS docking station for your code.
  • Platform: 1.21 m, about 29 kg, 5-DoF arms carrying up to 2 kg, about 1 hour of runtime.
$32,900 Get a quote
Humanoid hands configurator

Not sure which hand your robot needs?

Answer a few questions and we narrow 19 hands and grippers down to the three that fit your job, and show which Unitree robots each one works with. Every term, from degrees of freedom to repeatability, is explained in plain language as you go. No commitment.

  • A plain-language path for first-time buyers, a specs path for engineers
  • Tap any term like DoF or 0.1° repeatability for a simple explanation
  • Live list prices, what fits which robot, and a one-click quote request
Open the hands configurator → About two minutes. No commitment.
LinkerBot Linker Hand O6, available for the Unitree R1
ConfigurationEnd effectorDoFComputeProgrammingWarrantyPrice
R1 Air None 20 8-core CPU Not offered 6 months $6,870
R1 Basic None 24 8-core CPU Not offered 8 months $8,990
R1 Edu standard None 26 40 TOPS Yes, high and low level 12 months $15,950
R1 Edu Smart None 26 100 TOPS Yes, high and low level 12 months $18,900
R1 Edu Pro G Dex1-1 Advanced gripper 28 100 TOPS Yes, high and low level 12 months $19,800
R1 Edu Pro E LinkerBot O6 38 100 TOPS Yes, high and low level 12 months $22,900
R1 Edu Pro H Tendon-driven hand 30 100 TOPS Yes, high and low level 12 months $23,000
R1 Edu Pro F LinkerBot O6, tactile 38 100 TOPS Yes, high and low level 12 months $23,200
R1 Edu Pro C BrainCo Revo 2 38 100 TOPS Yes, high and low level 12 months $28,900
R1 Edu Pro A Dex3-1 3-finger 40 100 TOPS Yes, high and low level 12 months $30,900
R1 Edu Pro B Dex3-1 3-finger, tactile 40 100 TOPS Yes, high and low level 12 months $32,900
R1 Edu Pro D BrainCo Revo 2, tactile 38 100 TOPS Yes, high and low level 12 months $32,900

Prices are US MSRP and exclude tax, duty and freight. Configurations, lead times and specifications are subject to change by the manufacturer.

See it in action

Getting up, and staying up

Ground recovery and athletic movement from the lightest humanoid in the Unitree range.

Footage courtesy of Unitree Robotics.

Talk to a specialist

Get pricing & a free demo of the Unitree R1 Humanoid Robot.

Same-day response. We handle delivery, on-site setup, staff training, and ongoing service nationwide.

Agility, briefly

Cartwheel, and a run downhill

Two short clips from Unitree showing what the R1 does with its 26 degrees of freedom outside a lab.

Cartwheel Demonstration
Running Down a Grassy Slope

Footage courtesy of Unitree Robotics.

Related robots

More humanoid robots robots

NAO V6 Humanoid Robot
RobotLAB Robot

NAO V6 Humanoid Robot

The NAO V6 is the world's most widely deployed teaching humanoid — a 25-joint, fully programmable robot for K-12, special education, higher-ed, and research labs. Sold, deployed, and serviced nationwide by RobotLAB.

From $16,990 purchase
Unitree G1-D Humanoid Robot
Unitree Humanoid

Unitree G1-D Humanoid Robot

The Unitree G1-D pairs the G1 upper body with a wheeled chassis and an end-to-end data-collection stack, aimed at teams gathering manipulation demonstrations at scale rather than working on locomotion.

From $38,800 purchase
Unitree Humanoid Hands & Grippers
Unitree Component

Unitree Humanoid Hands & Grippers

Every Unitree humanoid ships with a choice of end effector, and the hand is usually the single biggest factor in what a robot costs and what it can do. This page lists every hand and gripper in the 2026 range, what fits

From $380 purchase
Request a walkthrough